Motion profiles
A move has a start, an end and a time; the profile is how the speed changes in between. The profile decides how smooth the move is, how much it shakes the arm, and whether the steppers can follow it.
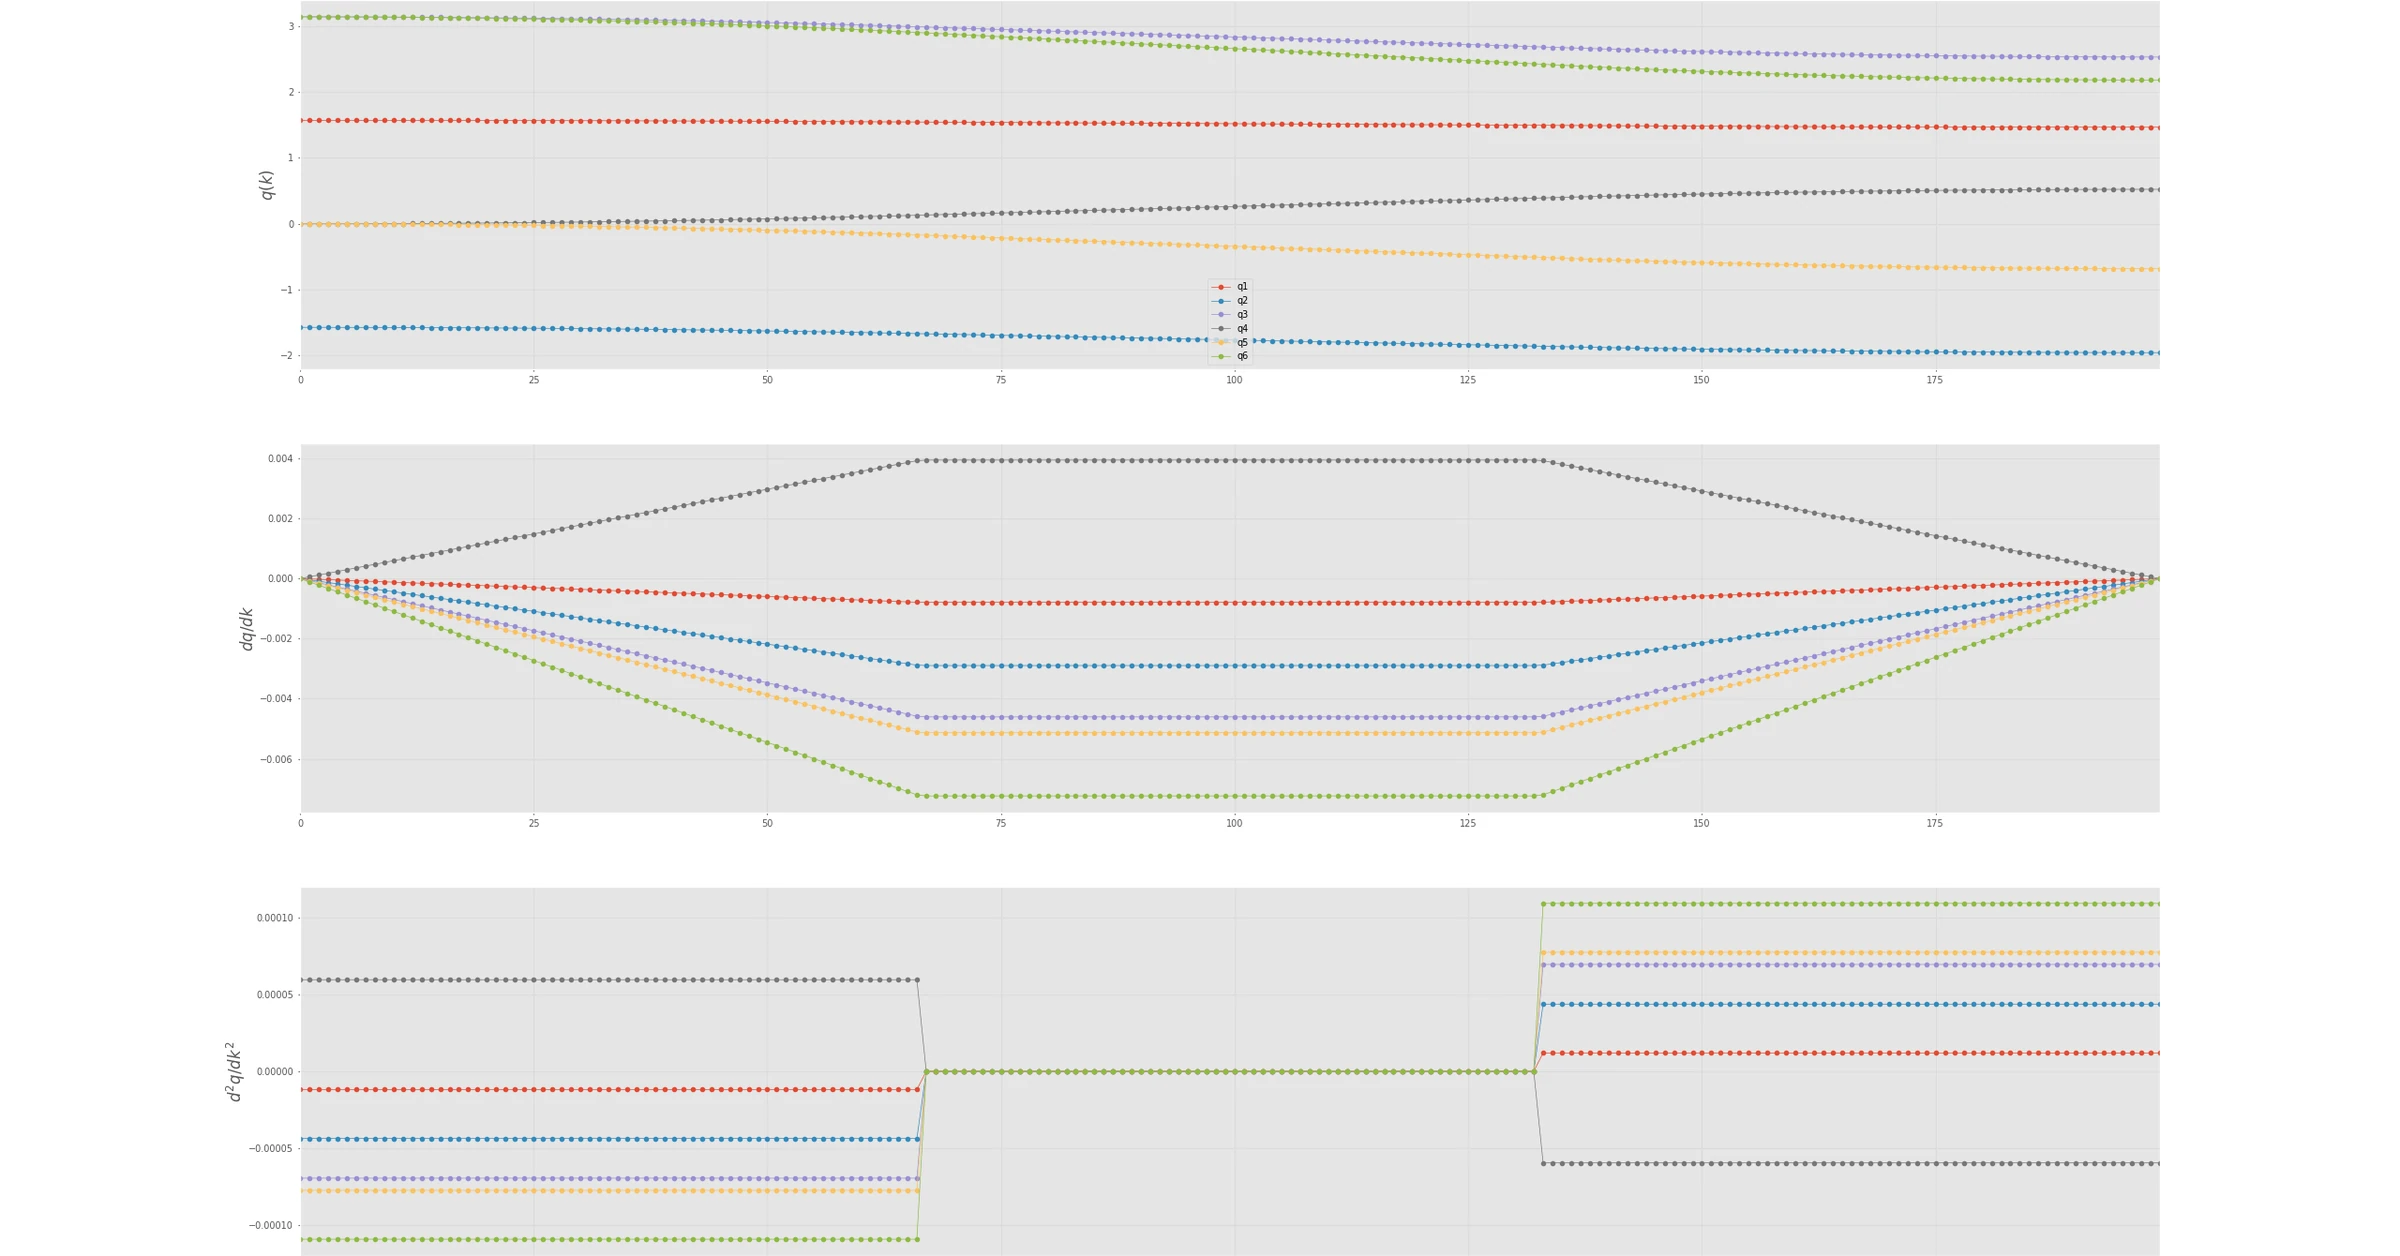
Trapezoidal
Accelerate at a constant rate, cruise at the maximum speed, decelerate at the same rate. The speed curve is a
trapezoid; the acceleration jumps between +a, 0 and −a, which is felt as a jerk at the three corners. With the
commander's t= argument, each third of the move is one phase.
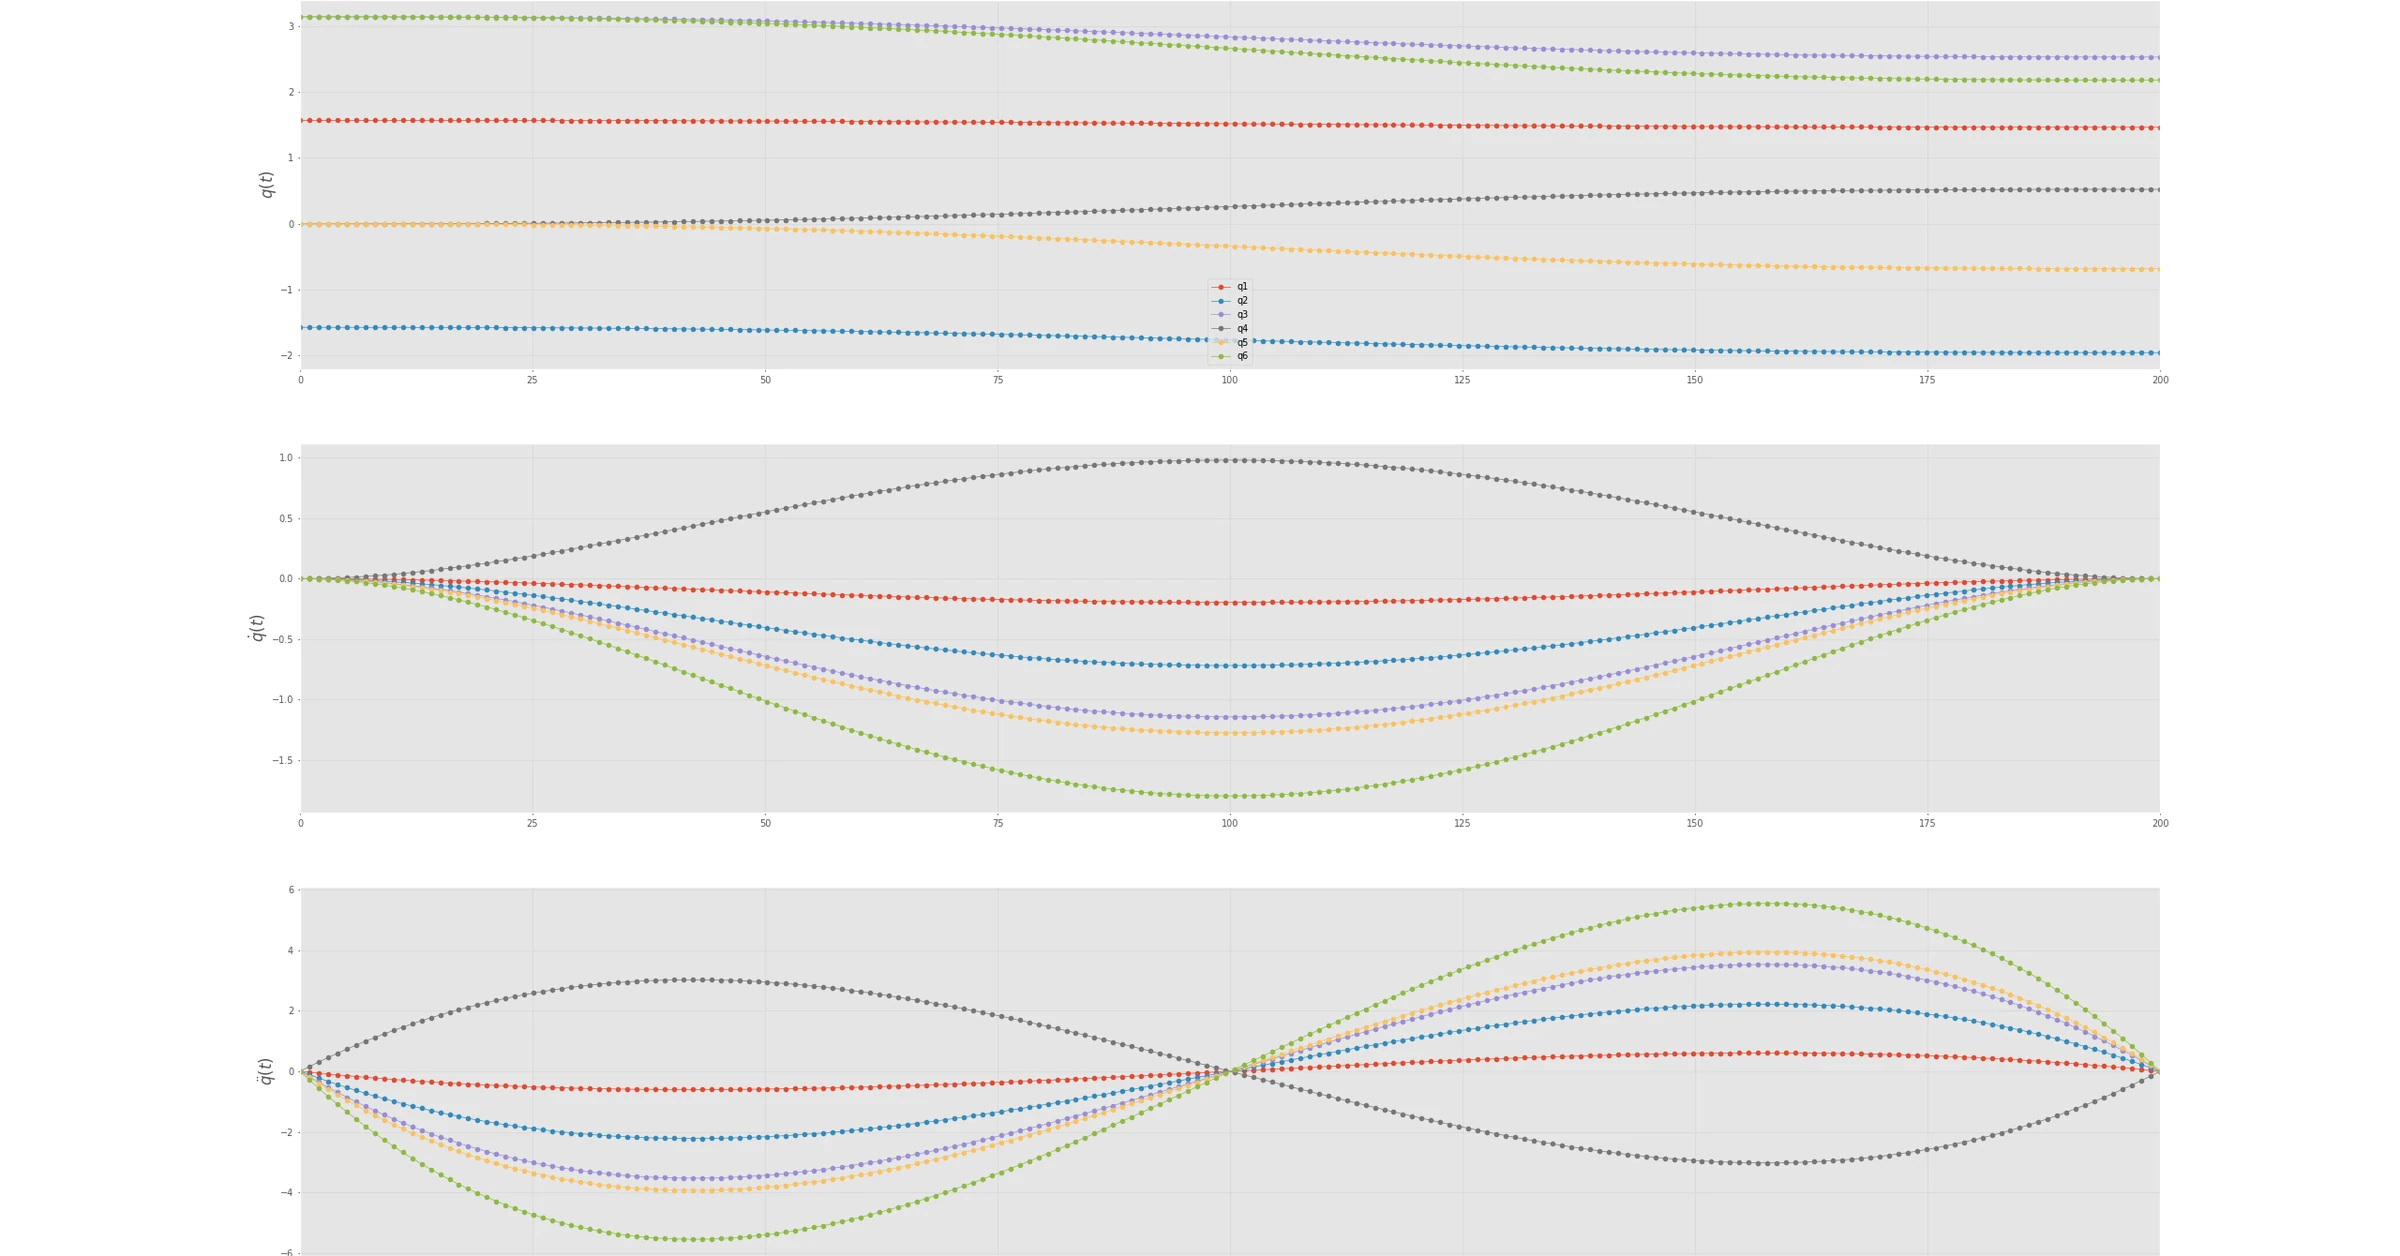
Polynomial
A quintic (fifth-order) polynomial through the start and end positions with zero speed and zero acceleration at both ends: the speed rises and falls as a smooth bell, the acceleration is continuous, and the move starts and ends from rest without a jolt. Slower in the middle for the same total time, and the arm likes it better.
In the commander software
MoveJoint, MovePose, MoveCart and MoveCartRelTRF take the bare word trap or poly after the other
arguments (func="trap" is ignored). A MoveJoint or MovePose with t= defaults to polynomial, with v= and
a= it is trapezoidal, and with neither it runs a conservative trapezoid. A MoveCart or MoveCartRelTRF with
t= defaults to trapezoidal, and without t= it always takes 3.6 s
(RBTscript).
In the Python API
select_profile() sets the profile for all planned moves. The profiles of the version this site describes:
TOPPRA, RUCKIG, QUINTIC, TRAPEZOID, LINEAR.
| Profile | What it is |
|---|---|
TOPPRA |
Time-optimal path following: the fastest run along the given path within the joint speed and acceleration limits. The default |
RUCKIG |
Jerk-limited point-to-point motion: acceleration ramps instead of jumping. Joint moves only; a Cartesian move under it runs TOPPRA |
QUINTIC |
The quintic polynomial above, C² smooth |
TRAPEZOID |
Trapezoidal, with parabolic blends at the corners |
LINEAR |
Straight interpolation, no smoothing: for tests |
The move's speed and accel fractions scale the limits the profile works within; a duration fixes the time
instead. Streamed jogs and servo targets use their own jerk-limited profile in the controller, not the selected
one.
Why the profile matters for a stepper arm
A stepper follows a speed command exactly until the torque runs out; a sudden acceleration demand at a corner is where it runs out first. Smooth profiles, lower accelerations and lower currents go together: if a joint loses steps at the start of moves, a quintic or jerk-limited profile at the same speed often fixes it.
Comments
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF