6. Peripherals
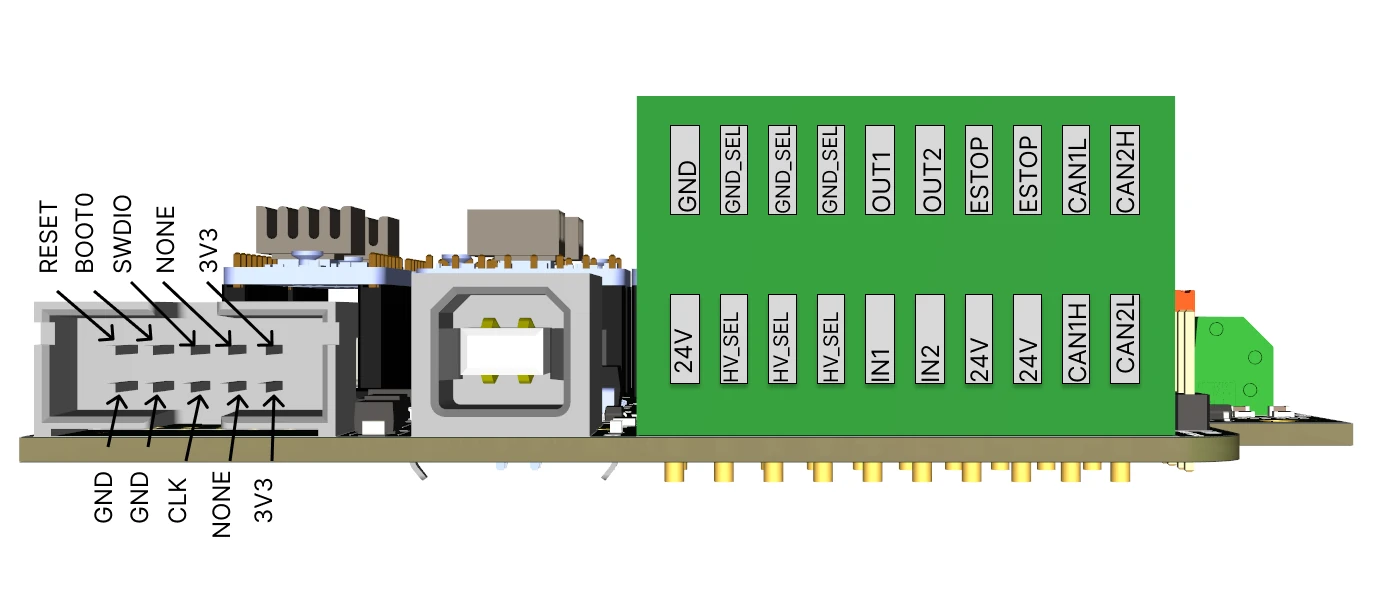
Everything the robot talks to besides the PC and the tool: switches and sensors on its inputs, valves and lamps on its outputs, the air for the pneumatic gripper, and the CAN bus for the electric grippers.
In this chapter
The electrical details of the connectors are in the Control Board Manual.
Comments
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF