9. Transport and storage
Moving the robot
- Home it, then bring it to the parked pose: joints 2 and 3 toward their limit switches so the arm folds over the base. The commander's Park button writes a program that moves there (Switching off). Or move it by hand once it is switched off (Moving the robot by hand).
- Switch off with the forearm held; unplug the supply, the USB and the E-stop.
- Carry it by the base, not by the arm.
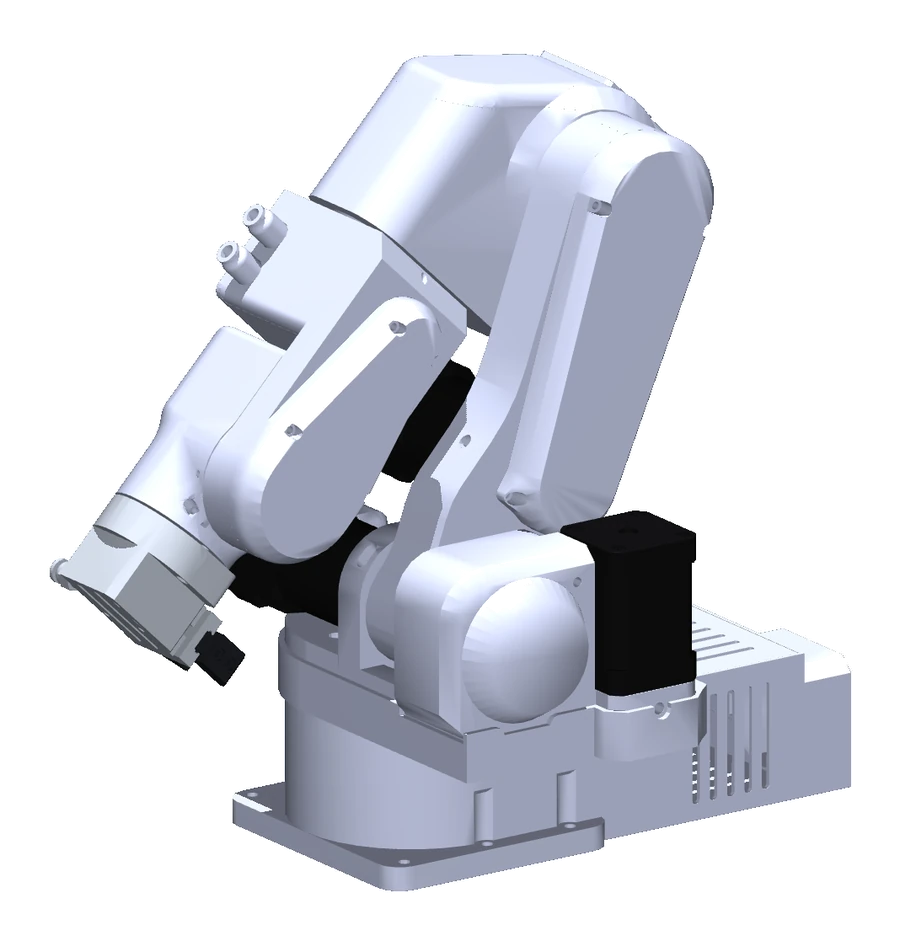
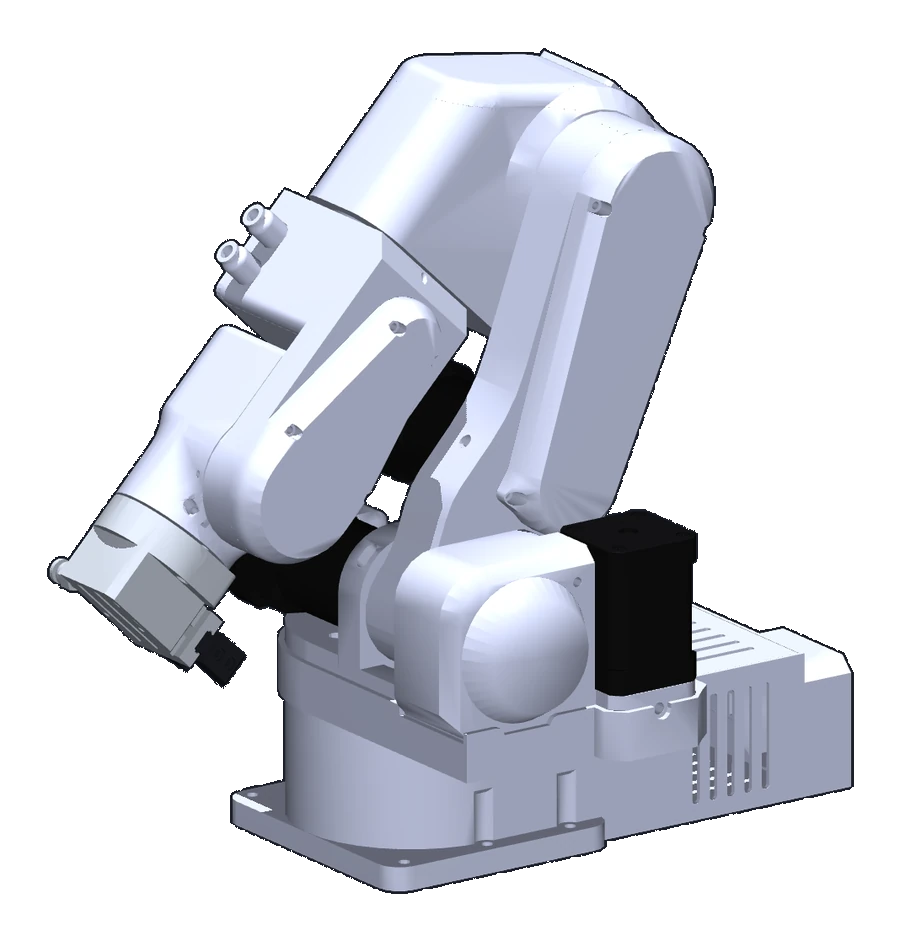
Packing
Fold the arm as above, put foam under the joint 3 limit switch so that the forearm rests on it and not on the switch, and tape the forearm to the upper arm so that the joints cannot swing. Pack the robot upright in a box with foam around the base; the gripper and the E-stop separately.
Storage
Dry, at room temperature, folded. The stepper motors and the drivers have no shelf-life issues; the PETG parts should not be stored where it gets hot, in a car or near a radiator. Before the first use after storage, run the Inspection.
Comments
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF