PAROL6 Robot Manual
Source Robotics d.o.o. publishes this document as part of the open-source PAROL6 project. It is revised as the
product changes; the document number, release, revision and date above identify the version you are reading, and
the document history on the About page says what changed. Take care that the release named under Applies to
matches the robot in front of you, and that the Python API version matches what pip installed: the version
selector in the header switches between releases. The text and the images are licensed CC BY-SA 4.0, the code
examples MIT.
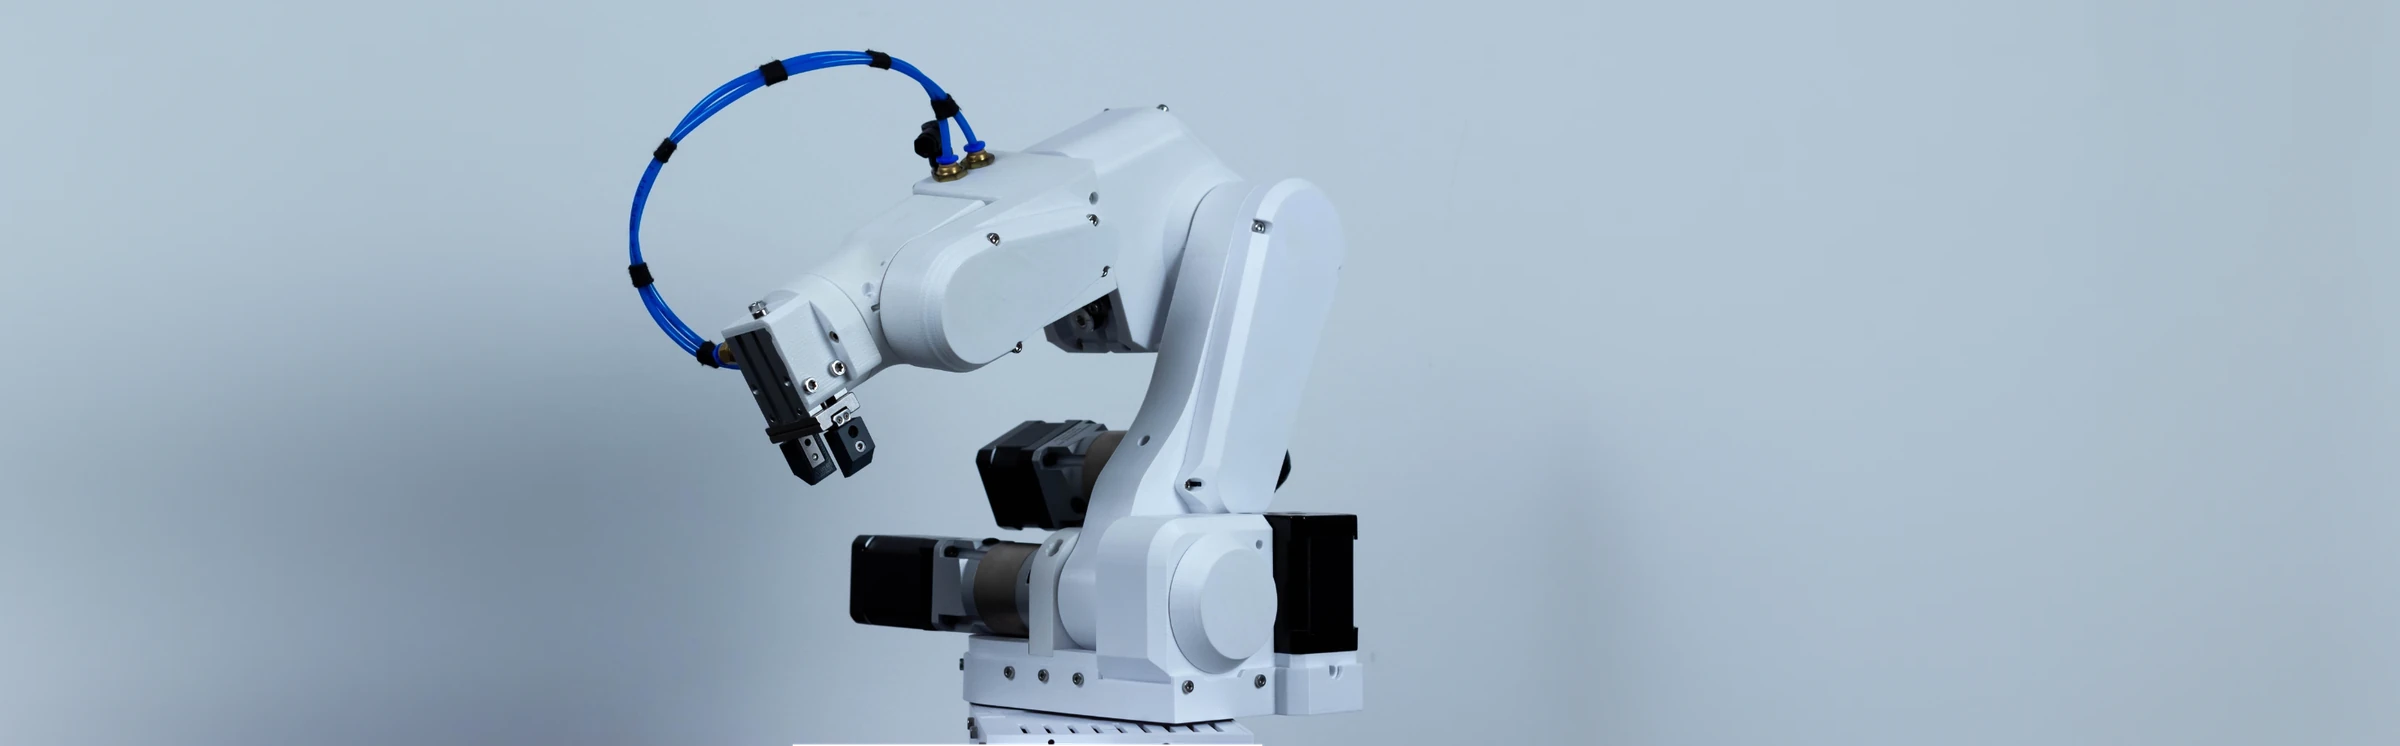
Drag to turn the robot, scroll to zoom, move each joint with its slider, choose the gripper on the flange, try a colour for the printed parts (the motors stay black). The model is the robot's URDF; the sliders run over its joint limits.
-
Quick start
One page from an assembled robot to a homed one that moves: power, the commander software, the first jog, homing, with a link into the manual at every step.
-
The robot manual
Safety, Technical data, Installation, Operation, Peripherals, Maintenance, Troubleshooting.
-
Build guide
From the BOM to the first run: what to print and how, the parts to buy, the assembly manual and videos, the wiring, the firmware upload, the first power-on.
-
Control board
The board that drives the robot: specifications, connectors and pinout, the stepper drivers, the I/O and E-stop wiring, CAN, firmware upload, the test firmware, the serial protocol.
-
End effectors
What goes on the flange: the pneumatic and vacuum grippers, the SSG-48 and MSG electric grippers, your own tool; mounting, connections, the homing offset, driving them.
-
GUI interfaces
The graphical programs: the commander software, Waldo Commander in the browser, Motor GUI for the grippers.
-
Programming
The programming guide: the interfaces, the concepts behind them, the Python API, RBTscript, ROS 2; and the reference, read from the API's source.
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF