1. Overview
The control board sits in the base of PAROL6 and does the low-level work: it generates the step pulses for six stepper motors, runs the homing sequence, reads the limit switches, the inputs and the E-stop, switches the outputs, drives an electric gripper over CAN, and exchanges a data packet with the PC over USB 100 times a second. It plans nothing: the PC computes every trajectory and sends the board the joint speeds and positions to execute, cycle by cycle.
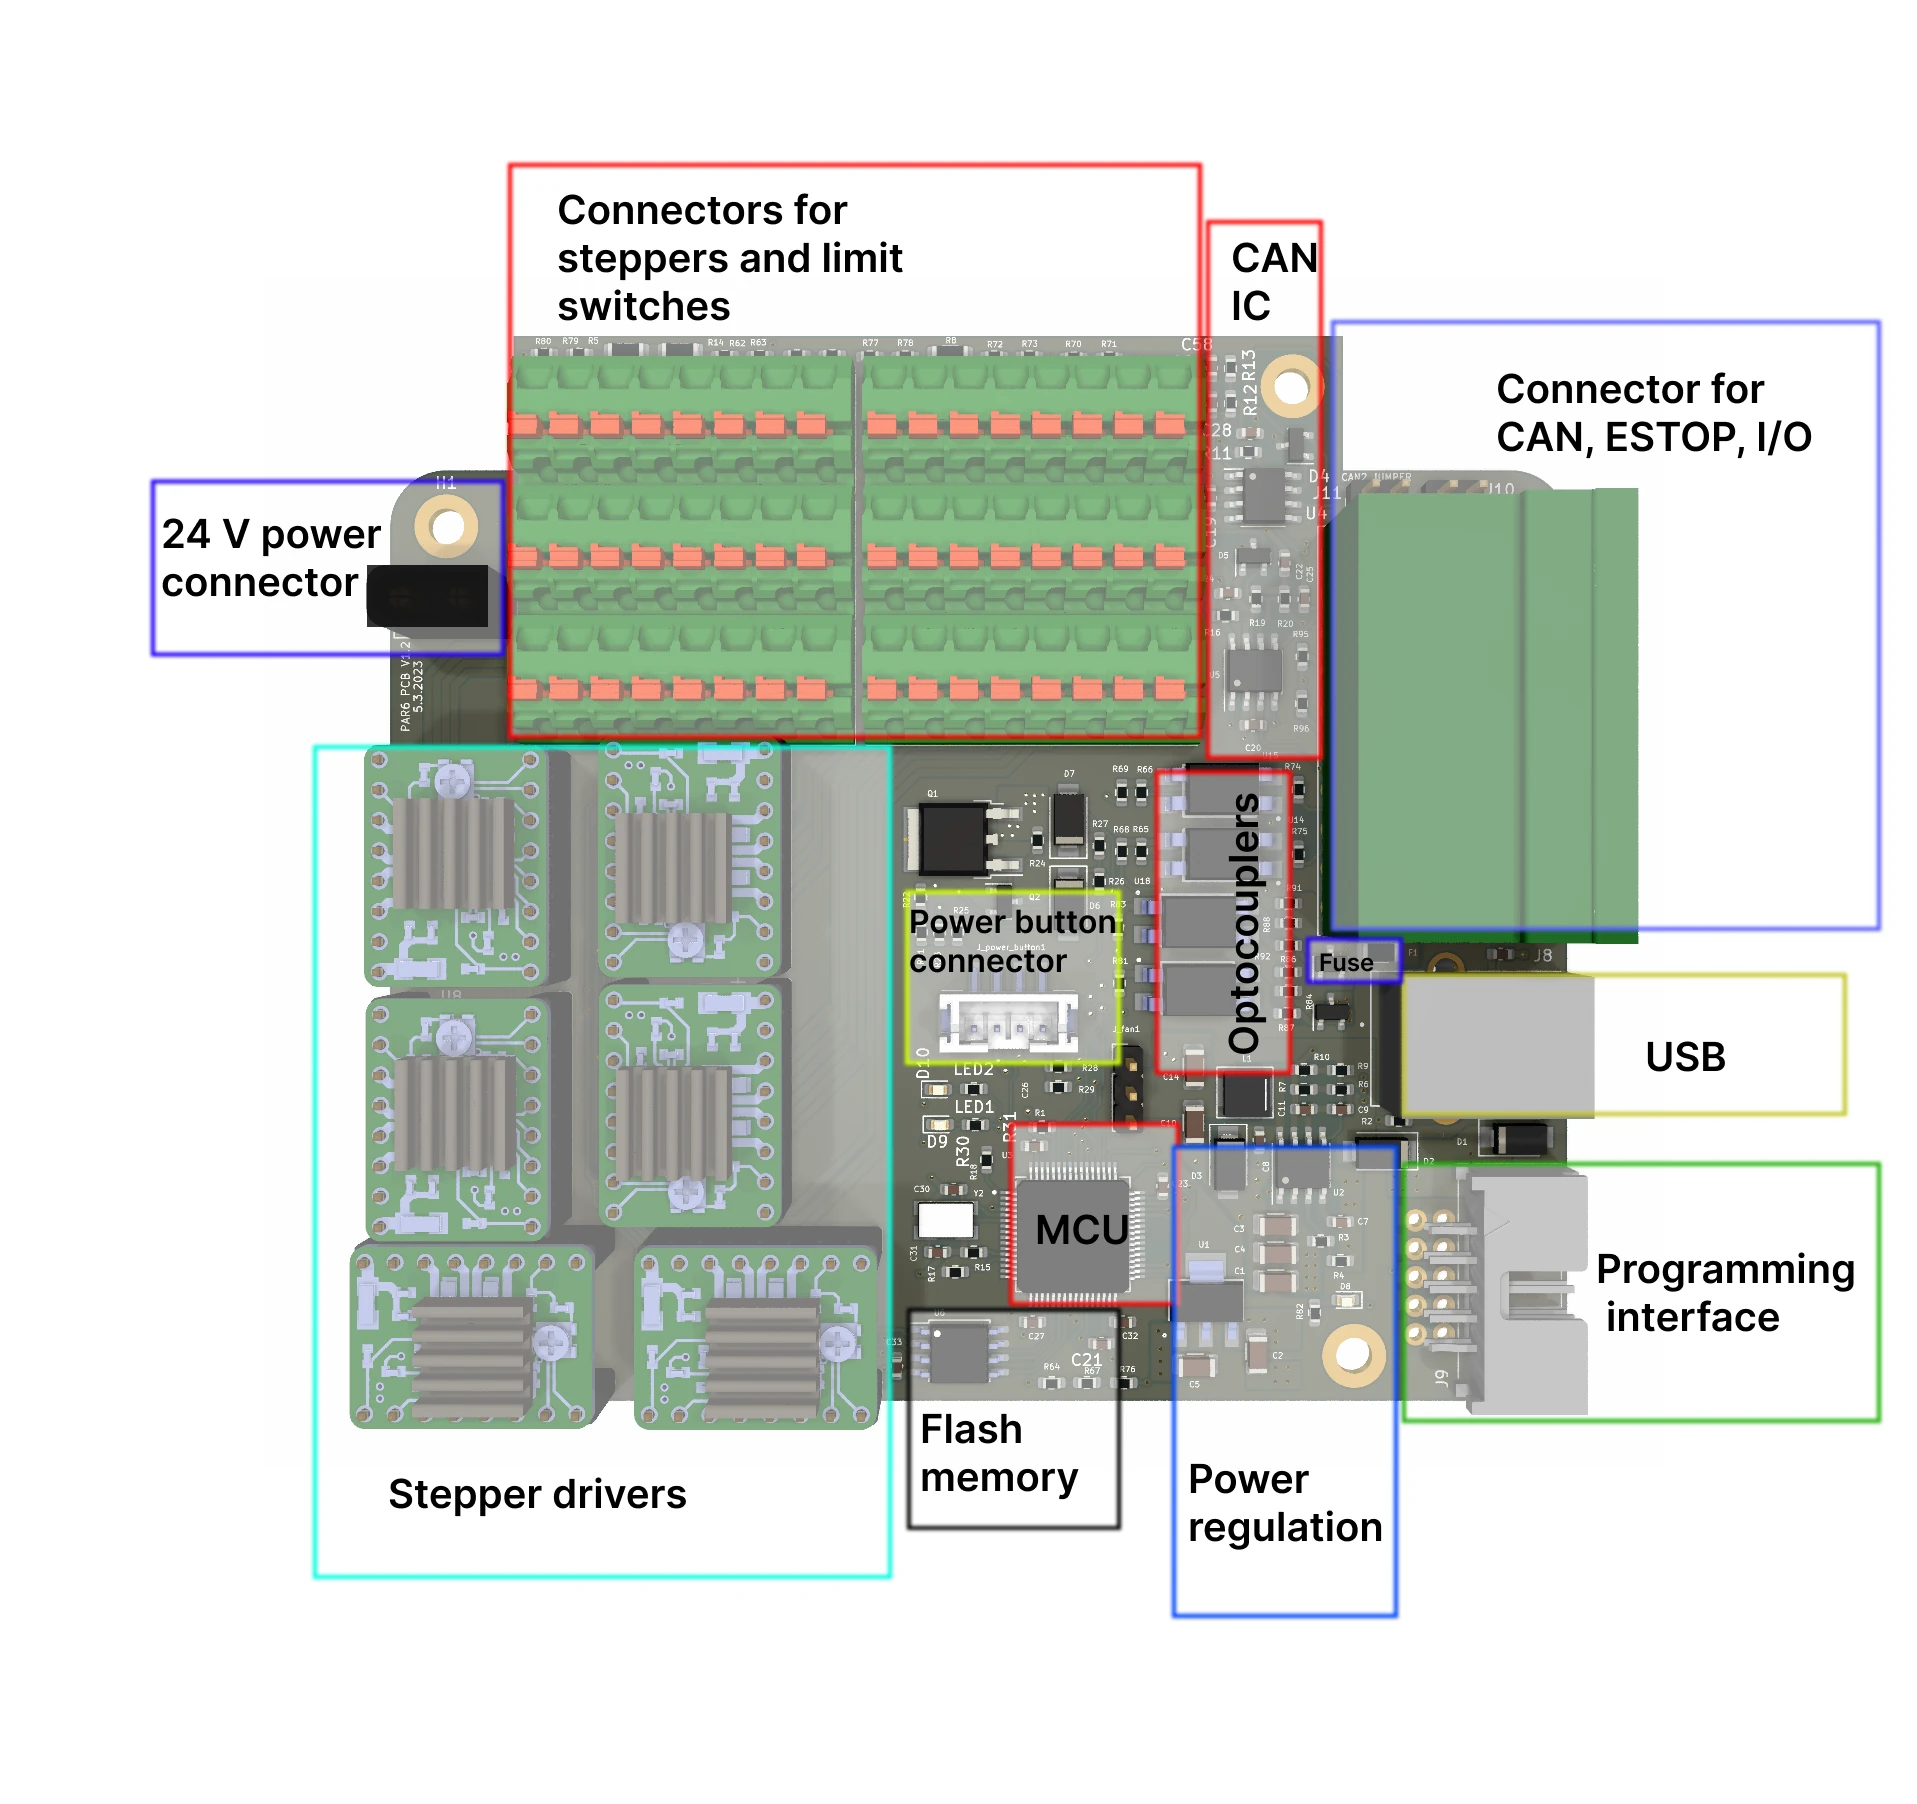
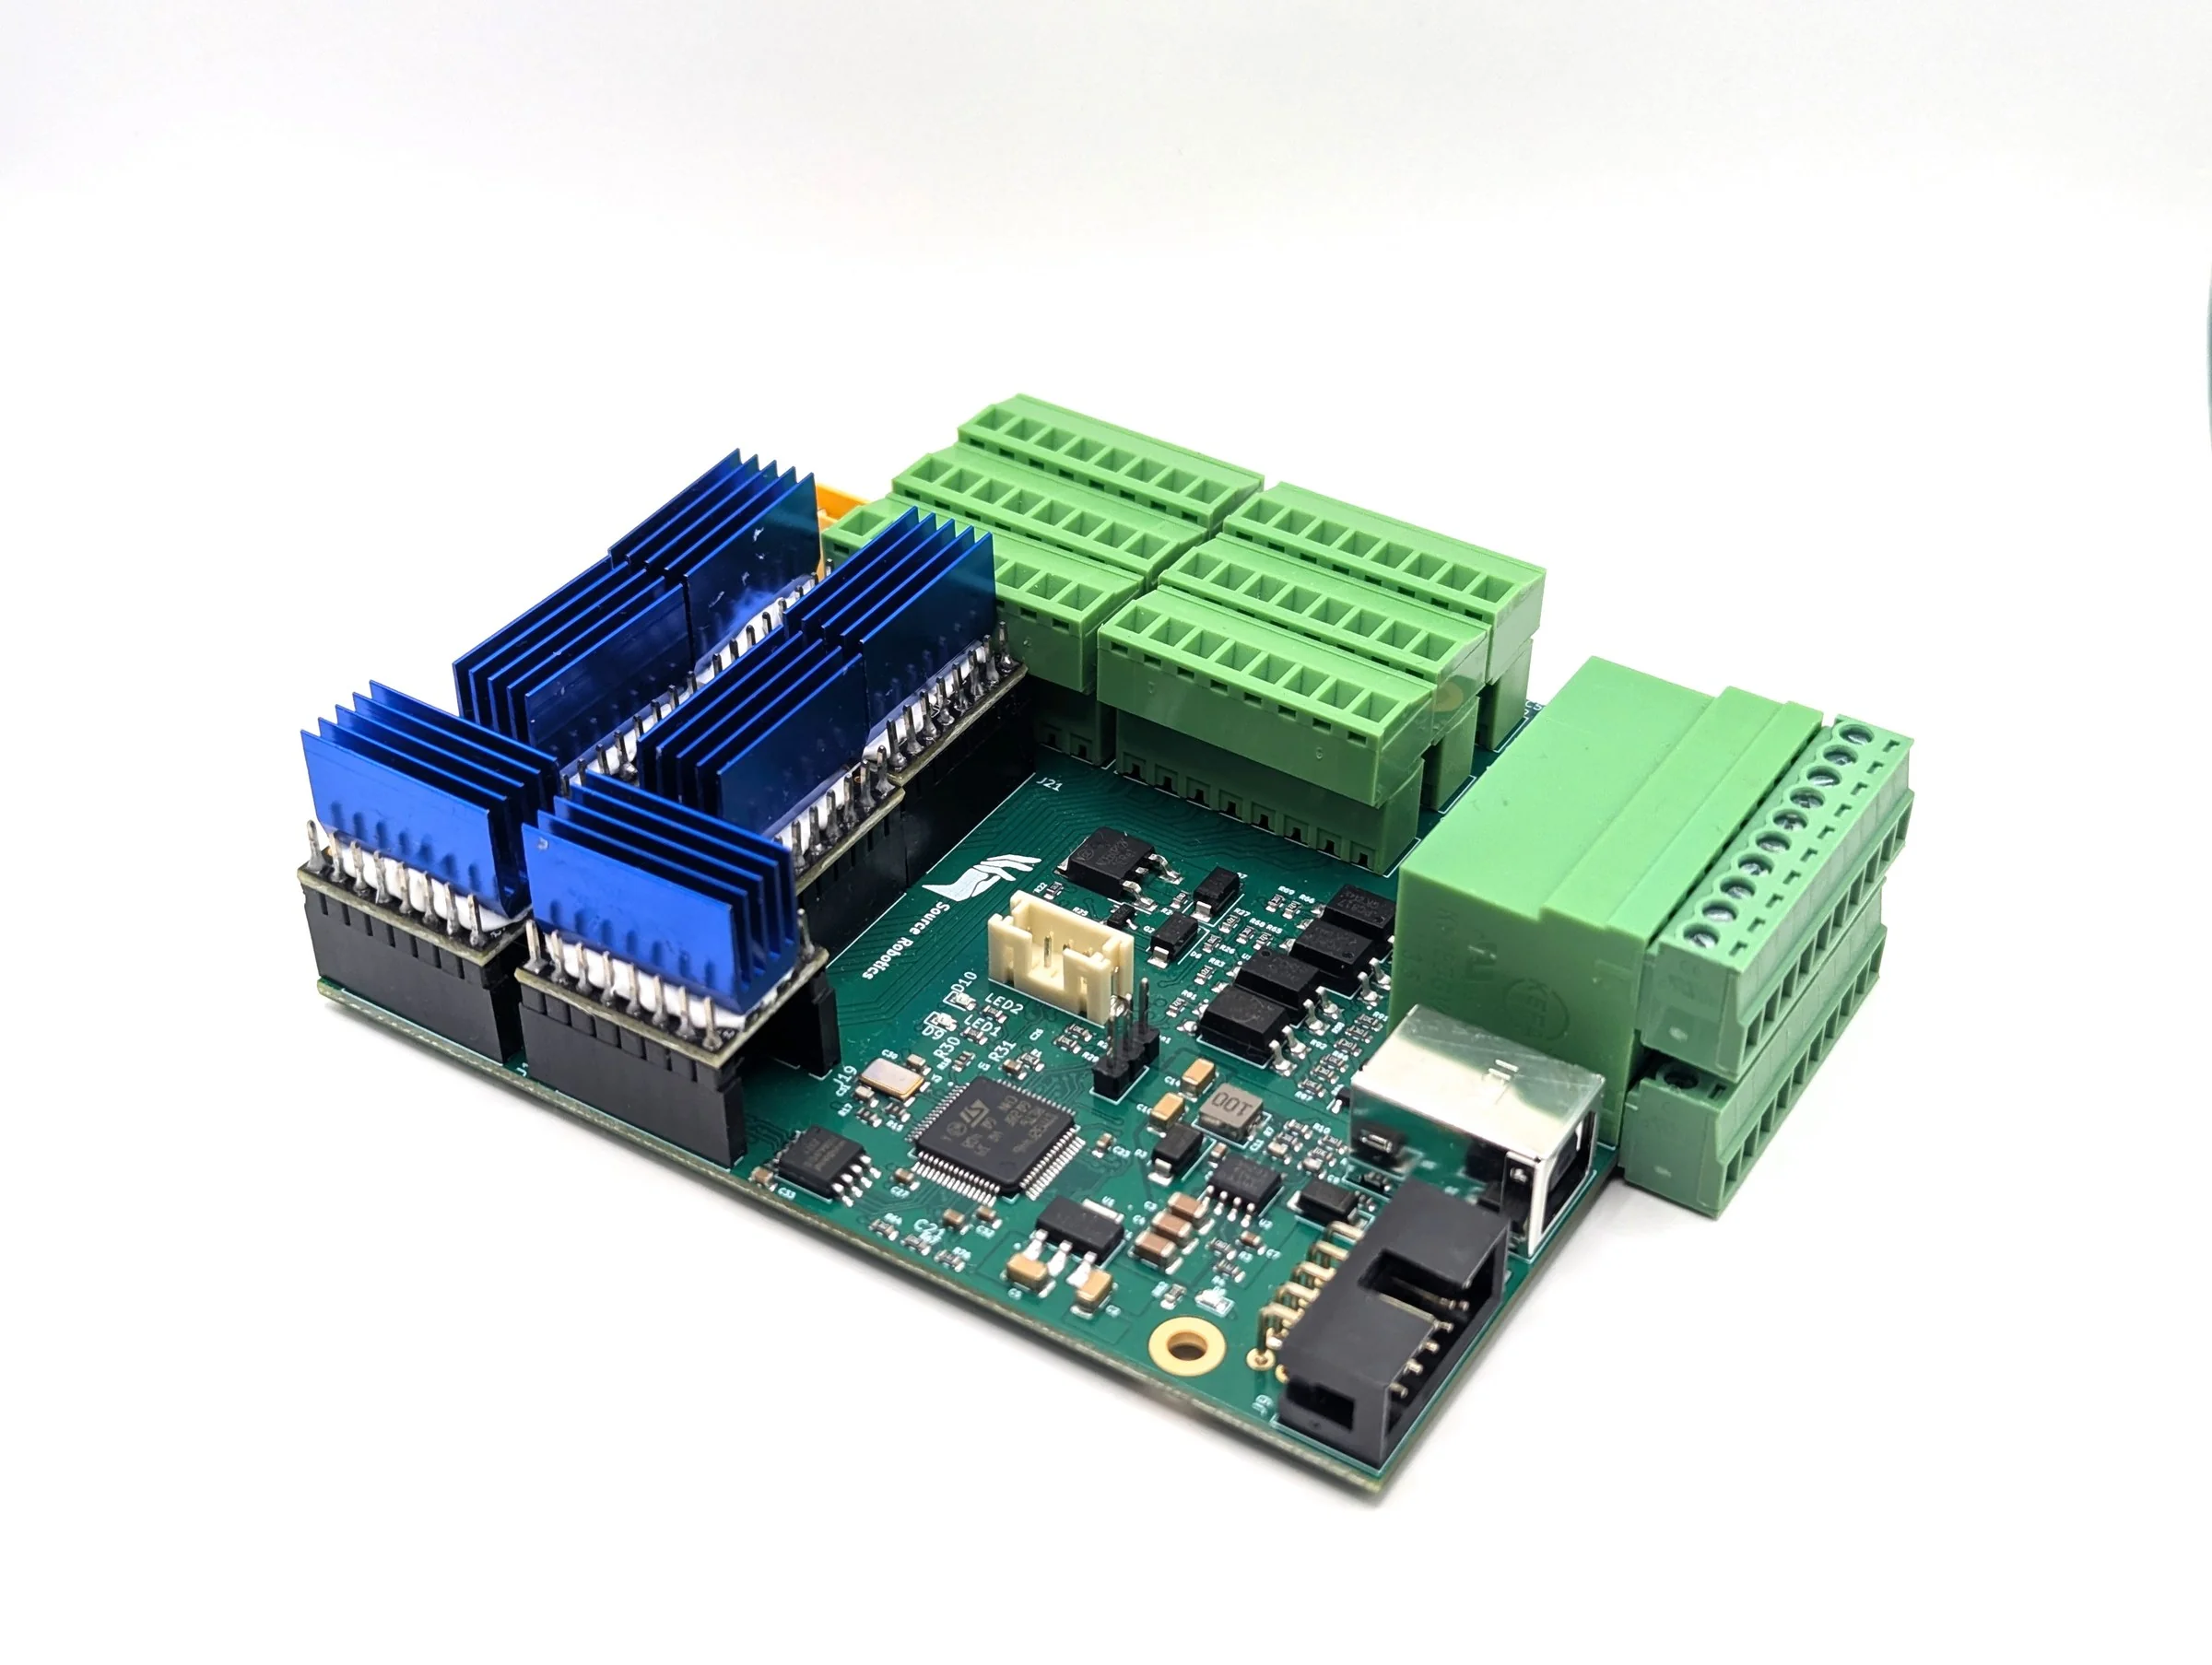
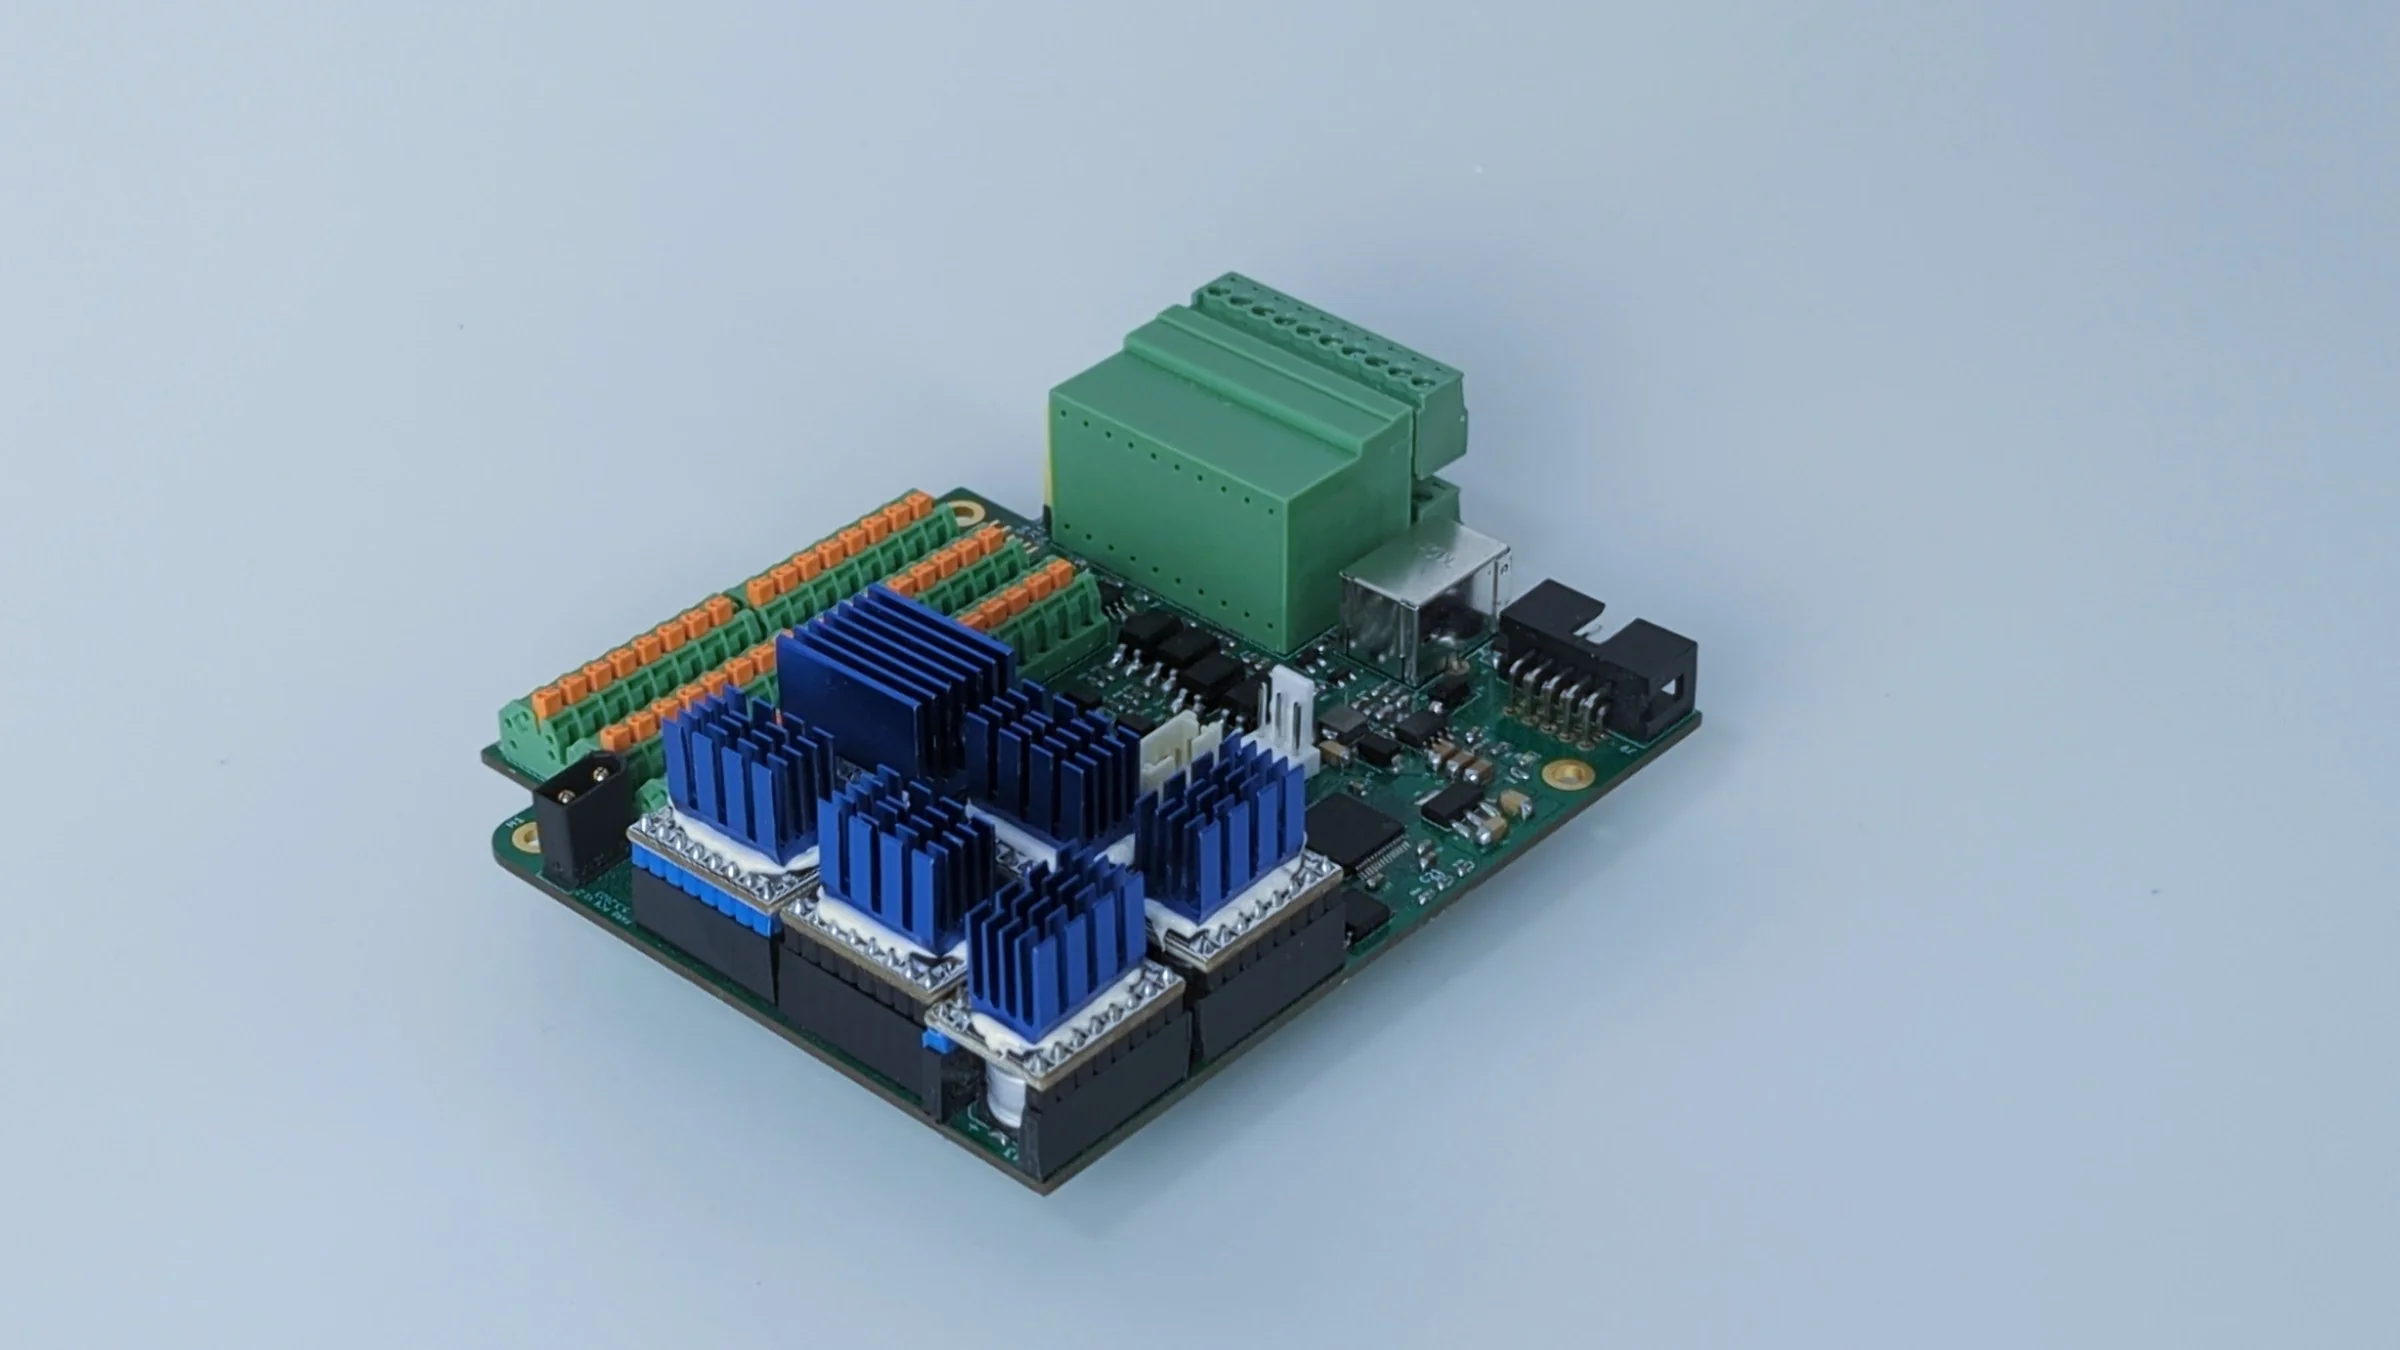
It works out of the box with PAROL6 and the commander software or the Python API, and it drives any six-axis stepper arm that is wired like PAROL6.
Versions
| Version | Status | Difference |
|---|---|---|
| v2.0 | Current, in the shop | Pluggable terminal block connectors |
| v1.2 | Discontinued | Spring-loaded Phoenix contacts |
The two are functionally identical and run the same firmware.
Testing
Every board is tested end to end before it ships, and comes with the test firmware preloaded, so that you can check the wiring of your robot before the main firmware goes on (The test firmware).
Where it is published
The firmware, main and test, is in the robot repository: PAROL6 control board main software and PAROL6 control board test code. The board is sold in the shop.
The board schematics and PCB design are not available as open source materials due to licensing agreements and confidentiality terms established with our development partners. These proprietary design elements are subject to contractual obligations that restrict their public distribution.
Comments
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF