CAN termination
A CAN bus needs a 120 Ω resistor at each of its two ends. The gripper's driver has one, on a switch that is reachable through an opening in the stepper cover: slide it to the ON mark to connect the resistor, away from it to disconnect it.
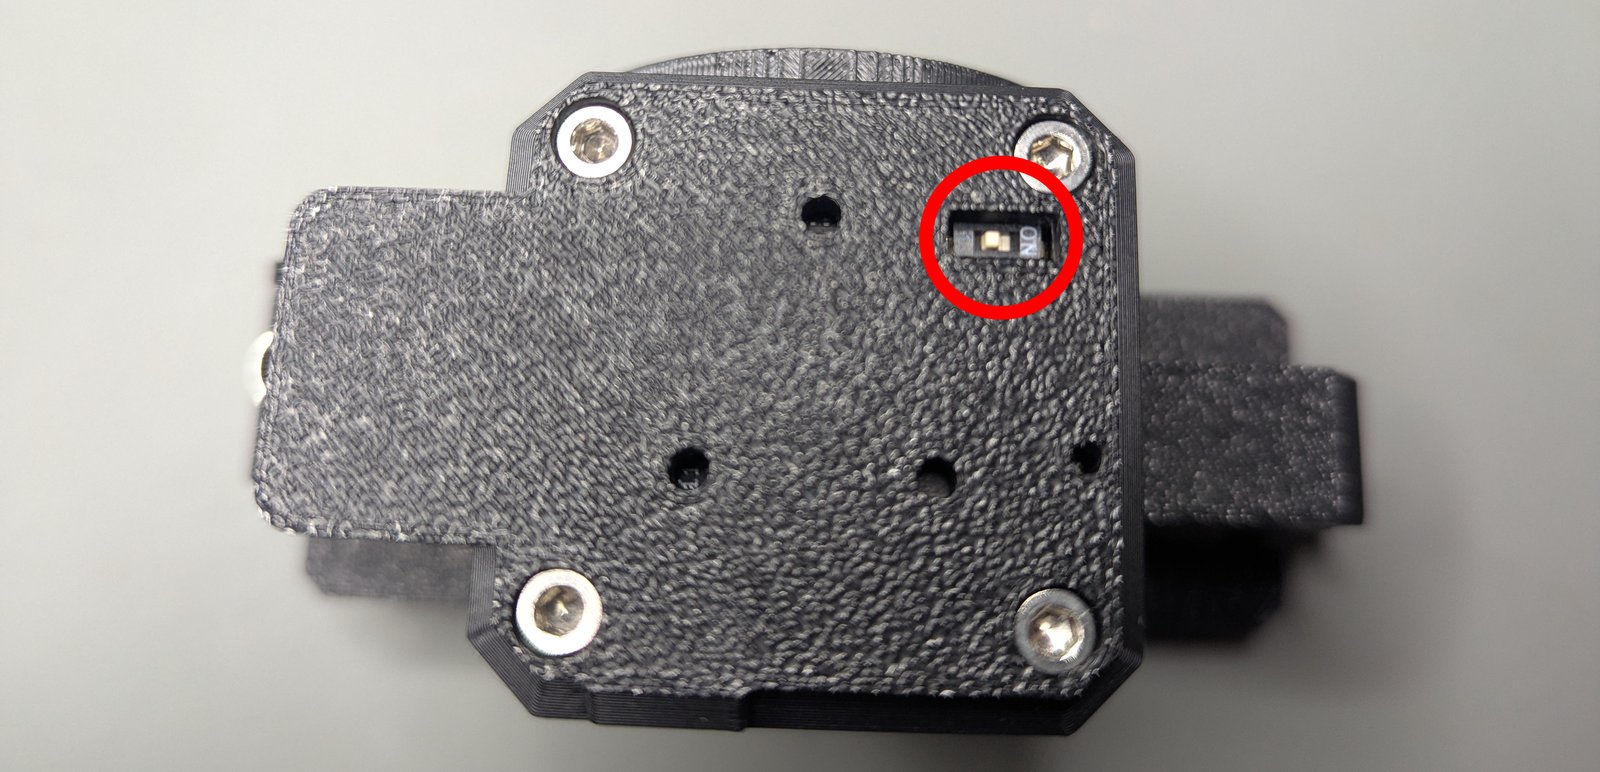
| The gripper is | Switch |
|---|---|
| the last node on a robot's bus, at the end of the arm | ON |
| alone on a bench bus with the CANvas adapter (which has its own termination) | ON |
| in the middle of a bus, with other nodes after it | off |
A bus with the right termination measures about 60 Ω between CANH and CANL with everything unpowered. A missing or doubled termination shows up as lost frames and a gripper that answers only sometimes.
Comments
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF