MSG Gripper Manual
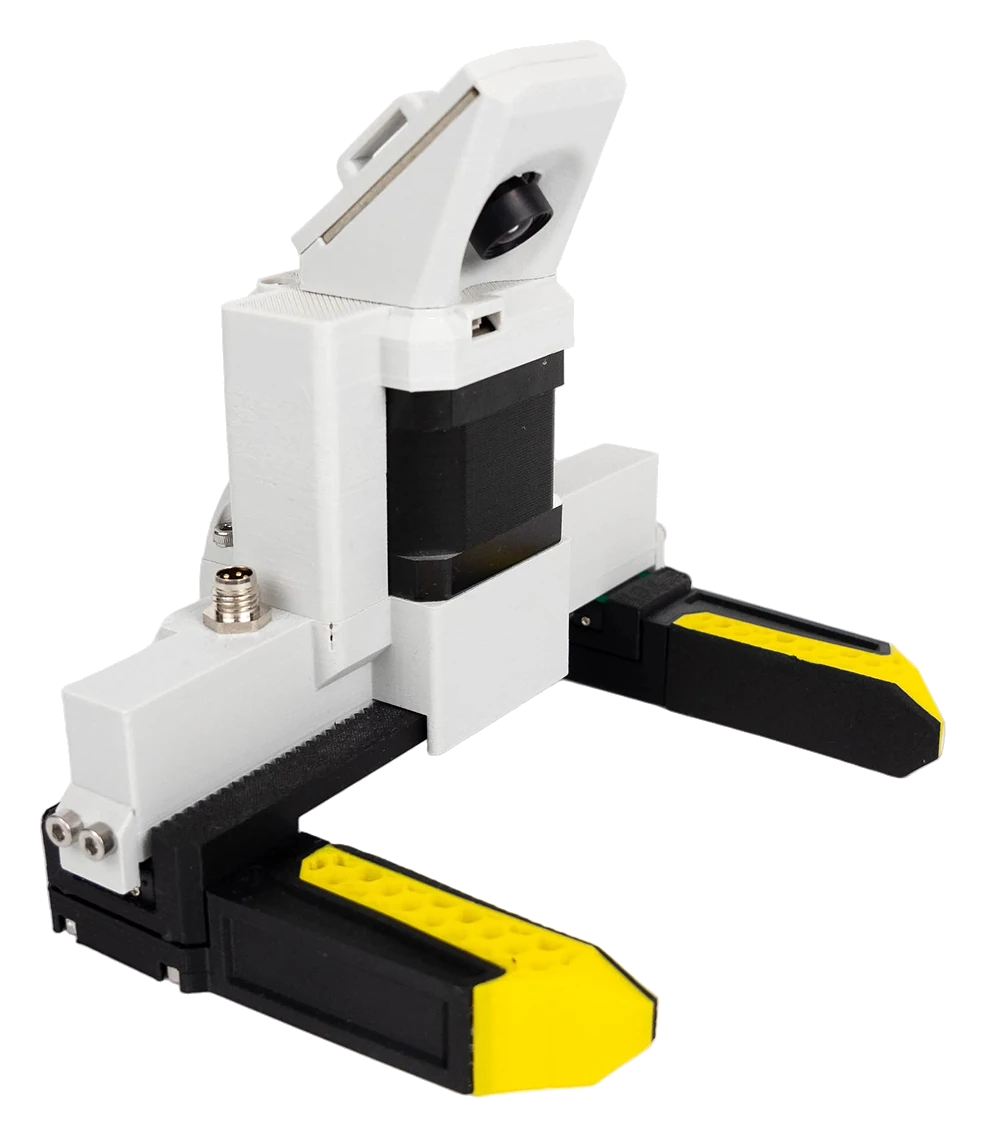
Source Robotics d.o.o. publishes this document for the MSG compliant AI stepper gripper. It is revised as the gripper and its firmware change; the document number, the gripper release, the firmware, the revision and the date above identify the version you are reading, and the document history on the About page says what changed. The version selector in the header switches between gripper releases. The gripper runs the STEPFOC driver's firmware: take care that the firmware named under Applies to matches what the gripper reports. The text and the images are licensed CC BY-SA 4.0, the code examples MIT.
The MSG is open source, and that is important to us. Everything the gripper is made of is published: the CAD and print files, the bill of materials, the assembly instructions, the driver's firmware and the software that drives it. Buy the gripper assembled, or build one yourself; change the jaws or the body for your application and fit it to any robot. The build guide is the order to do it in.
Made for teleoperation and robot learning. We designed the MSG specifically for teleoperation, VLA (vision-language-action) training and physical intelligence. The camera on top of the body is placed with care: it looks down between the jaws at an angle that keeps both jaws, and the object between them, in view, the picture a teleoperator and a learning model need.
Drag to turn the gripper, scroll to zoom, open and close the jaws, try the colours. The model is the gripper's URDF, the 150 mm rail variant; the current URDF and MuJoCo models are linked from the repository's msg_description guide. The shop sells the body in black and grey.
-
Quick start
One-page quick start: choose the cable, check the bus, connect Motor GUI, calibrate, and make the first gentle open and close. Each step says what to check before continuing.
-
The manual
Safety, Technical data, Installation, First setup, Operation, Maintenance, Firmware, Troubleshooting.
-
On a robot
PAROL6 and PAR6, ROS 2, Python: the gripper from the robot's own software, from a ROS 2 node, or from your program over CAN.
-
API reference
The gripper's CAN messages and UART commands, the status bits and the Python library, read from the firmware.
-
Open source: build your own
The build guide: the repository's bill of materials, printing, the assembly, the driver's setup and the first run. The same manual applies.
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF