Pneumatic gripper
The standard tool: an SMC MHZ2-16D parallel gripper in a printed holder, driven by a 5/2 solenoid valve from one of the control board's outputs.
Parts
| Gripper | MHZ2-16D, two PC4-M5 push-in fittings |
| Holder | GRIPPER_ATTACHMENTS/Pneumatic_gripper_holder.STL (vertical) or Pneumatic_gripper_holder_horizontal.stl; Gripper_ARMS.STL for the fingers |
| Valve | 5/2 solenoid valve, 24 V, 4 mm tube ports |
| Tube | 4 × 2.5 mm pneumatic tube, 5 m |
| Air | 5 to 7 bar; stay below the lowest rating of the gripper, the valve and the fittings (Pneumatics) |
Connections
The two tubes from the gripper leave the forearm and are joined to the two tubes that run through the arm to the base; the valve's two outputs go to the two fittings at the base. Swapping the two tubes swaps normally open and normally closed: choose the state the gripper should take without power.
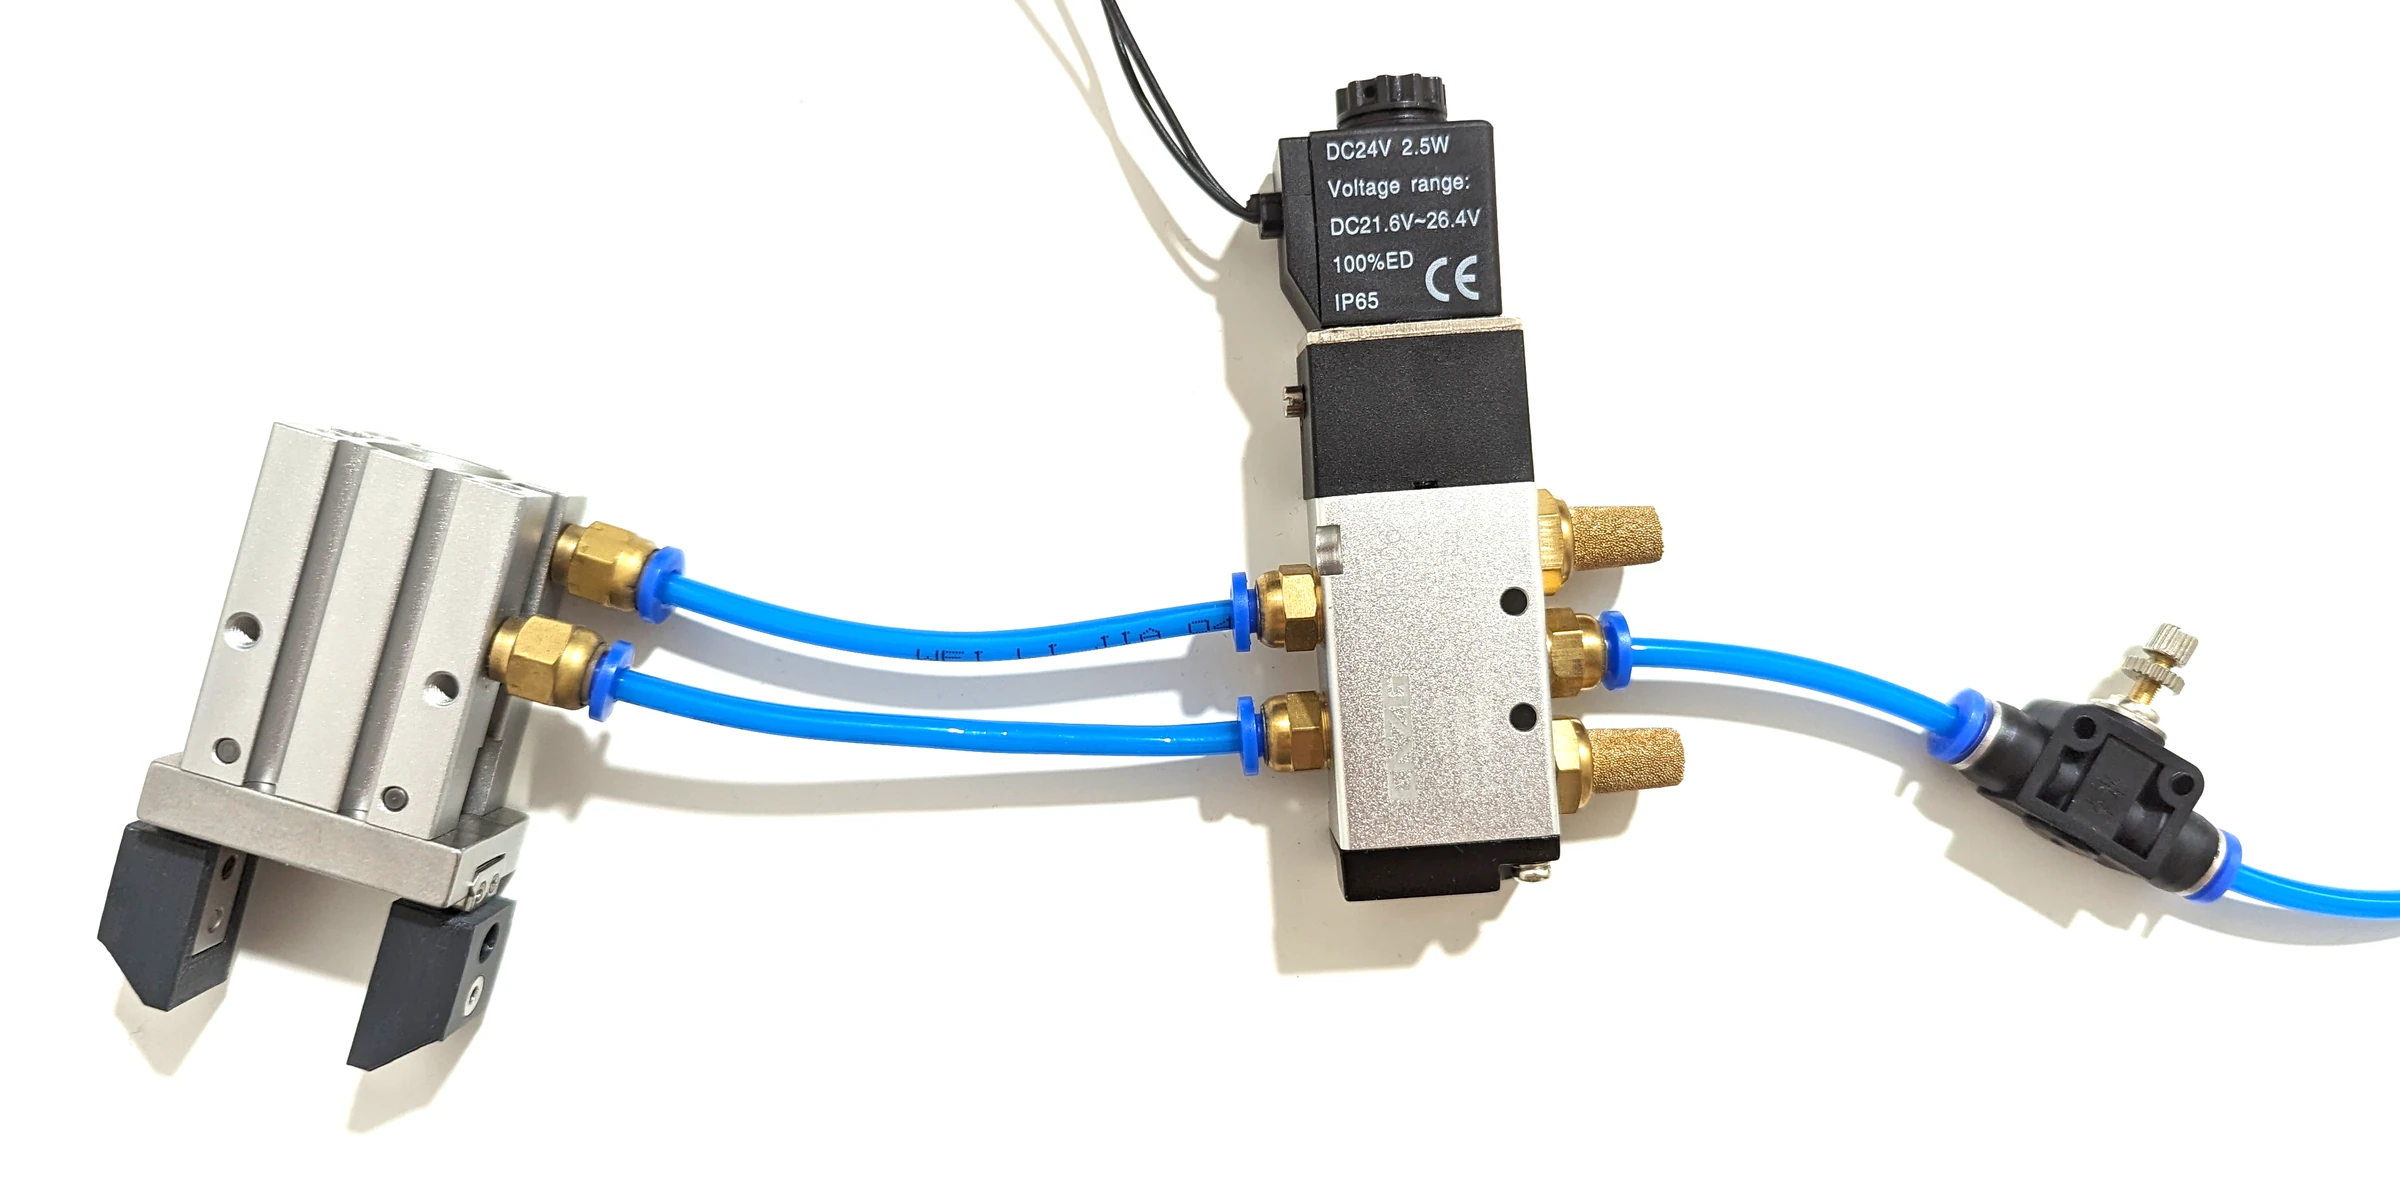
The valve's coil goes between GND_SEL and OUTPUT1 on the control board, with the output supply set to the robot's 24 V or an isolated one (Inputs and outputs).
Tool centre point
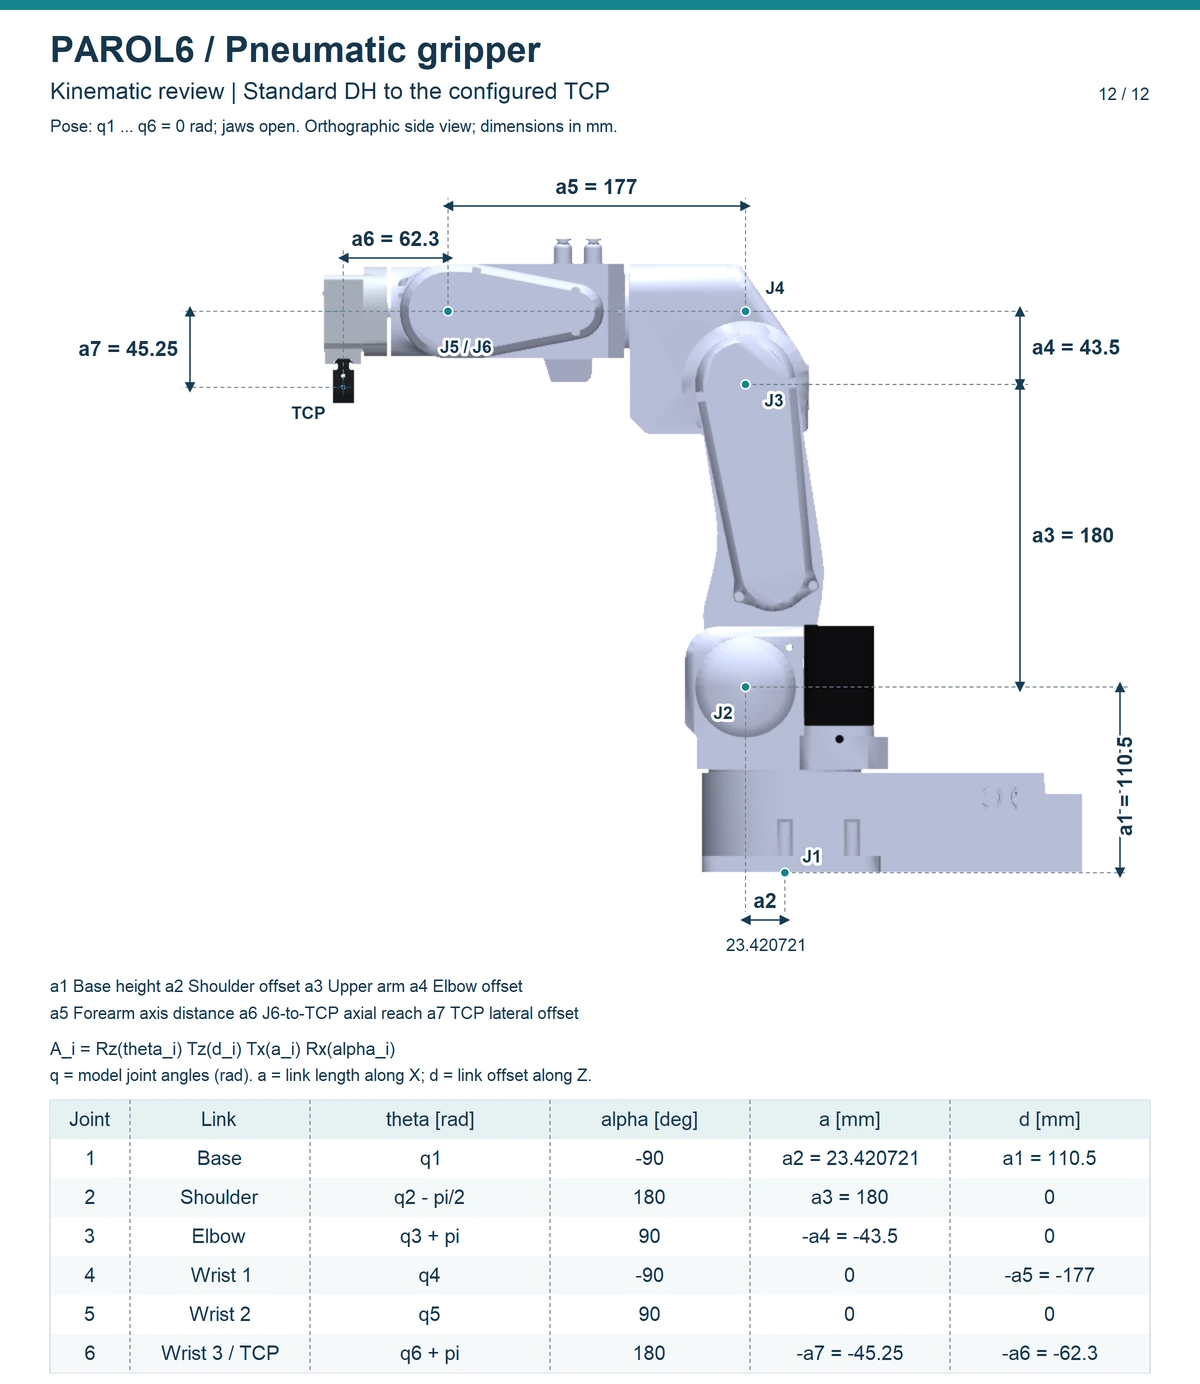
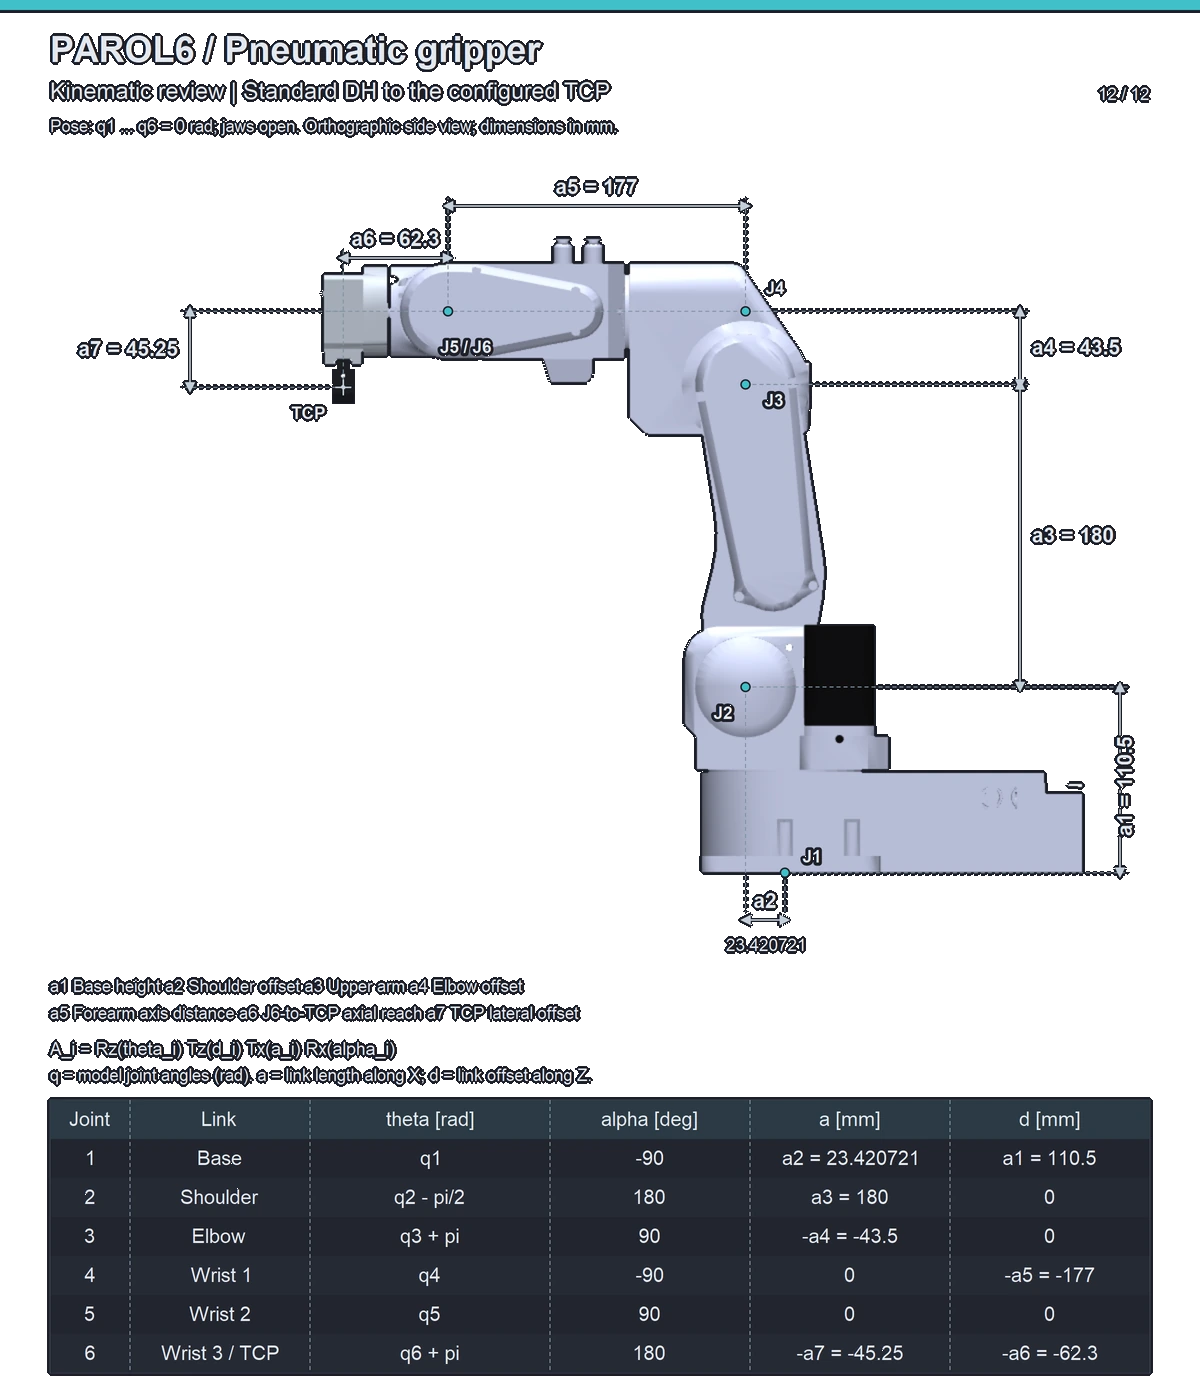
The tool centre point (TCP) is a6 = 62.3 mm from the joint 6 centre along the tool axis and a7 = 45.25 mm to the side. The TCP is the reference point of the original MHZ2-10D gripper, not a newly measured grasp centre. The sheet is the robot's model from robot_descriptions (version 2.15.1) with every joint at 0. Tell the software about the tool (Tools and the TCP); every tool is compared on Dimensions and kinematics.
Driving it
rbt.select_tool("PNEUMATIC")
rbt.tool.close()              # output 1 low
rbt.tool.open()               # output 1 high
rbt.write_io(0, 1)            # the same as open(), as a plain output
close() waits for the gripper.
The API's open() switches output 1 high and close() switches it low: lay the tubes so that the gripper
is open with the valve switched, or open() and close() come out the other way round.
Orientation
The vertical holder puts the gripper along the axis of joint 6; the horizontal holder turns it 90°, which
reaches a table from the side. The Python API has a variant for each (vertical, horizontal); with the
commander, remember that the DH dimensions a6 and a7 assume the vertical holder.
Comments
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF