Force and speed
A move command carries a current limit in mA and a speed from 0 to 255. This page estimates the resulting force and speed. Force and payload values are ideal model estimates, not measured ratings.
Grip force
The driver limits the motor's current to the value you command, so the torque the motor produces is limited to
\(T = K_t \, I_q\), with \(K_t\) the motor's torque constant in Nm/A (#Kt prints what the driver uses) and \(I_q\)
the current limit in amperes (the command is in mA). The pinion shares that torque between two racks.
Here \(F\) is the combined normal force of both jaws,
not the force at one jaw:
\(r\) is the pitch radius of the pinion (32 DP, 21 teeth). The force is proportional to the current, with a slope set by the stepper:
| Stepper | Motor | Assumed \(K_t\) | Ideal combined force per ampere | Maximum current | Ideal combined force at the maximum current |
|---|---|---|---|---|---|
| 21.5 mm | 17HS08-1004S | 0.17 Nm/A | 20 N/A | 1.5 A | about 31 N |
| 40 mm | 17HS16-2004S1 | 0.21 Nm/A | 25 N/A | 2.0 A | about 50 N |
| 60 mm | 17HS24-2104S | 0.30 Nm/A | 36 N/A | 2.1 A | about 76 N |
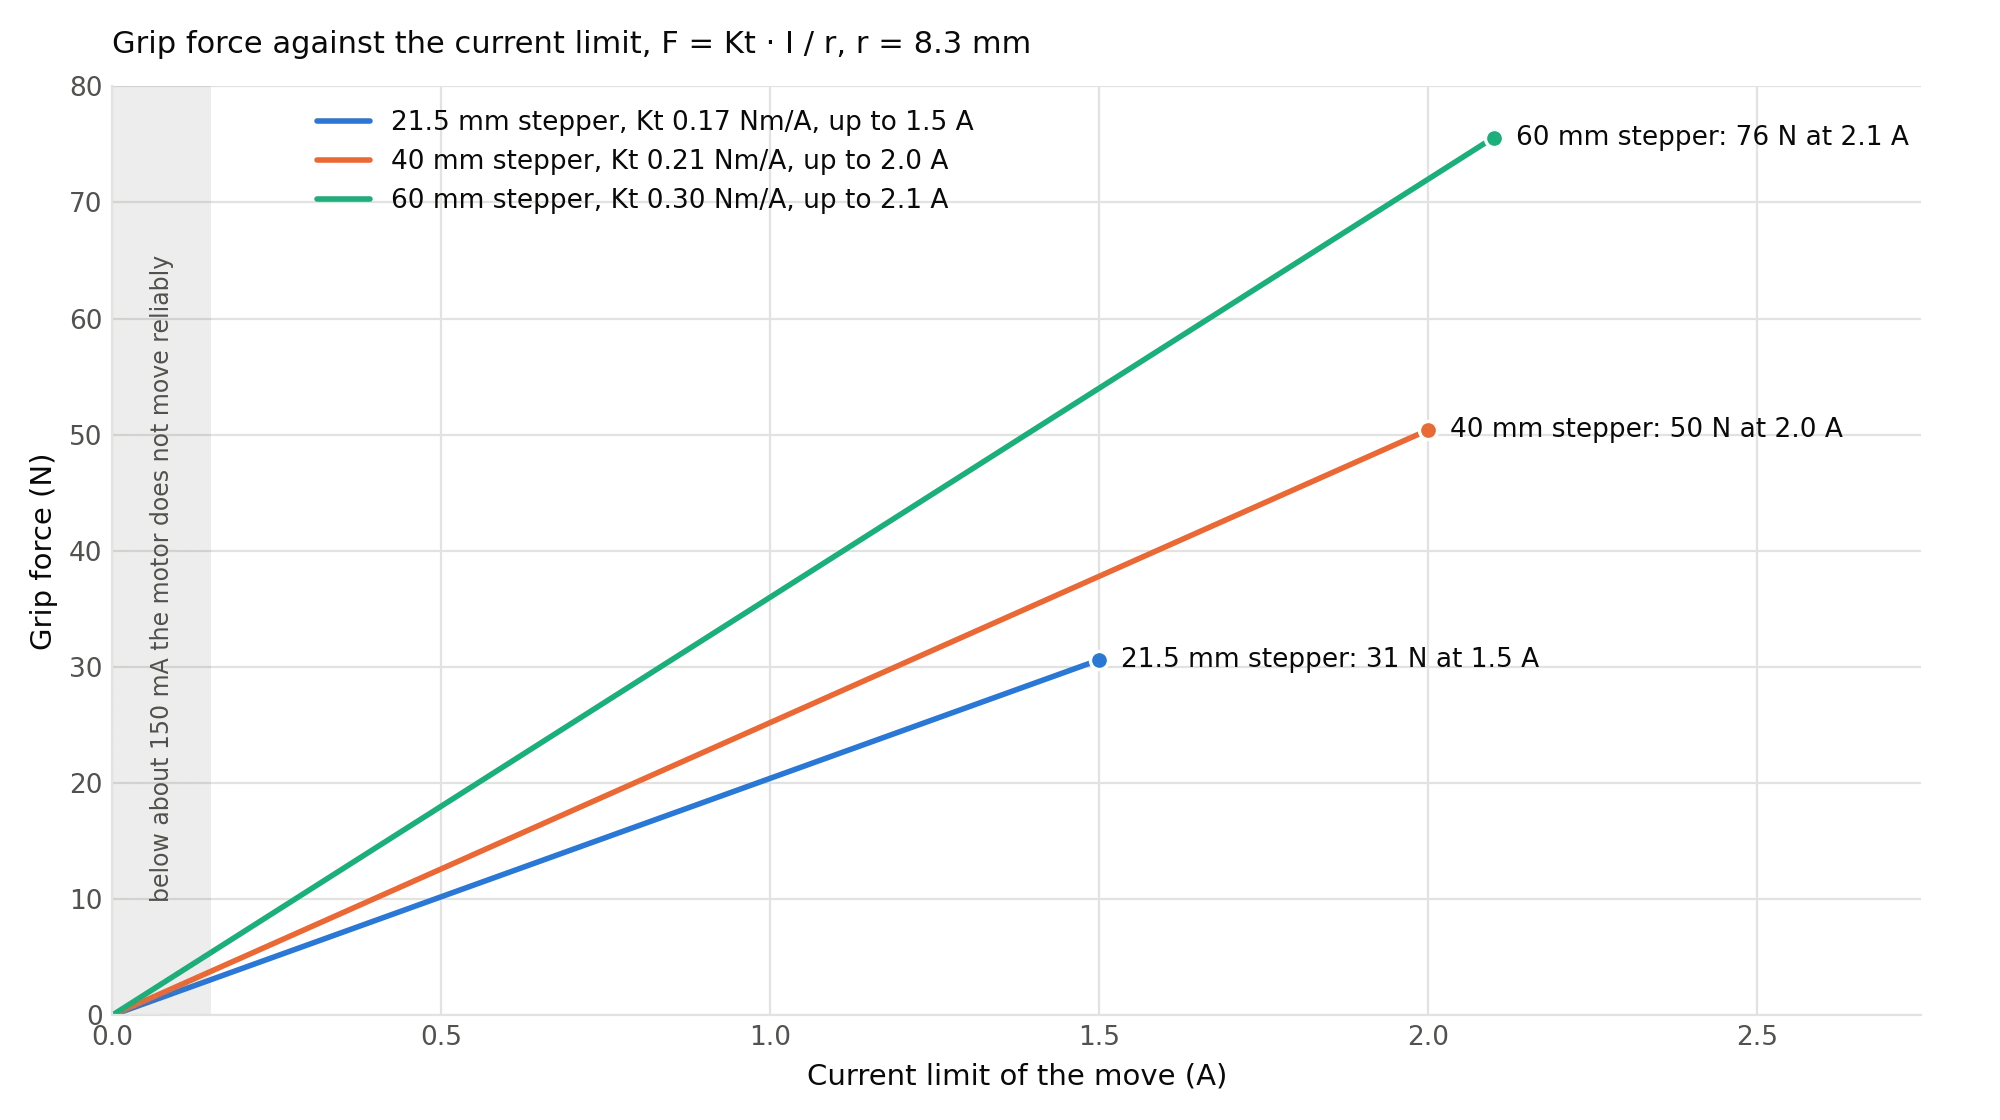
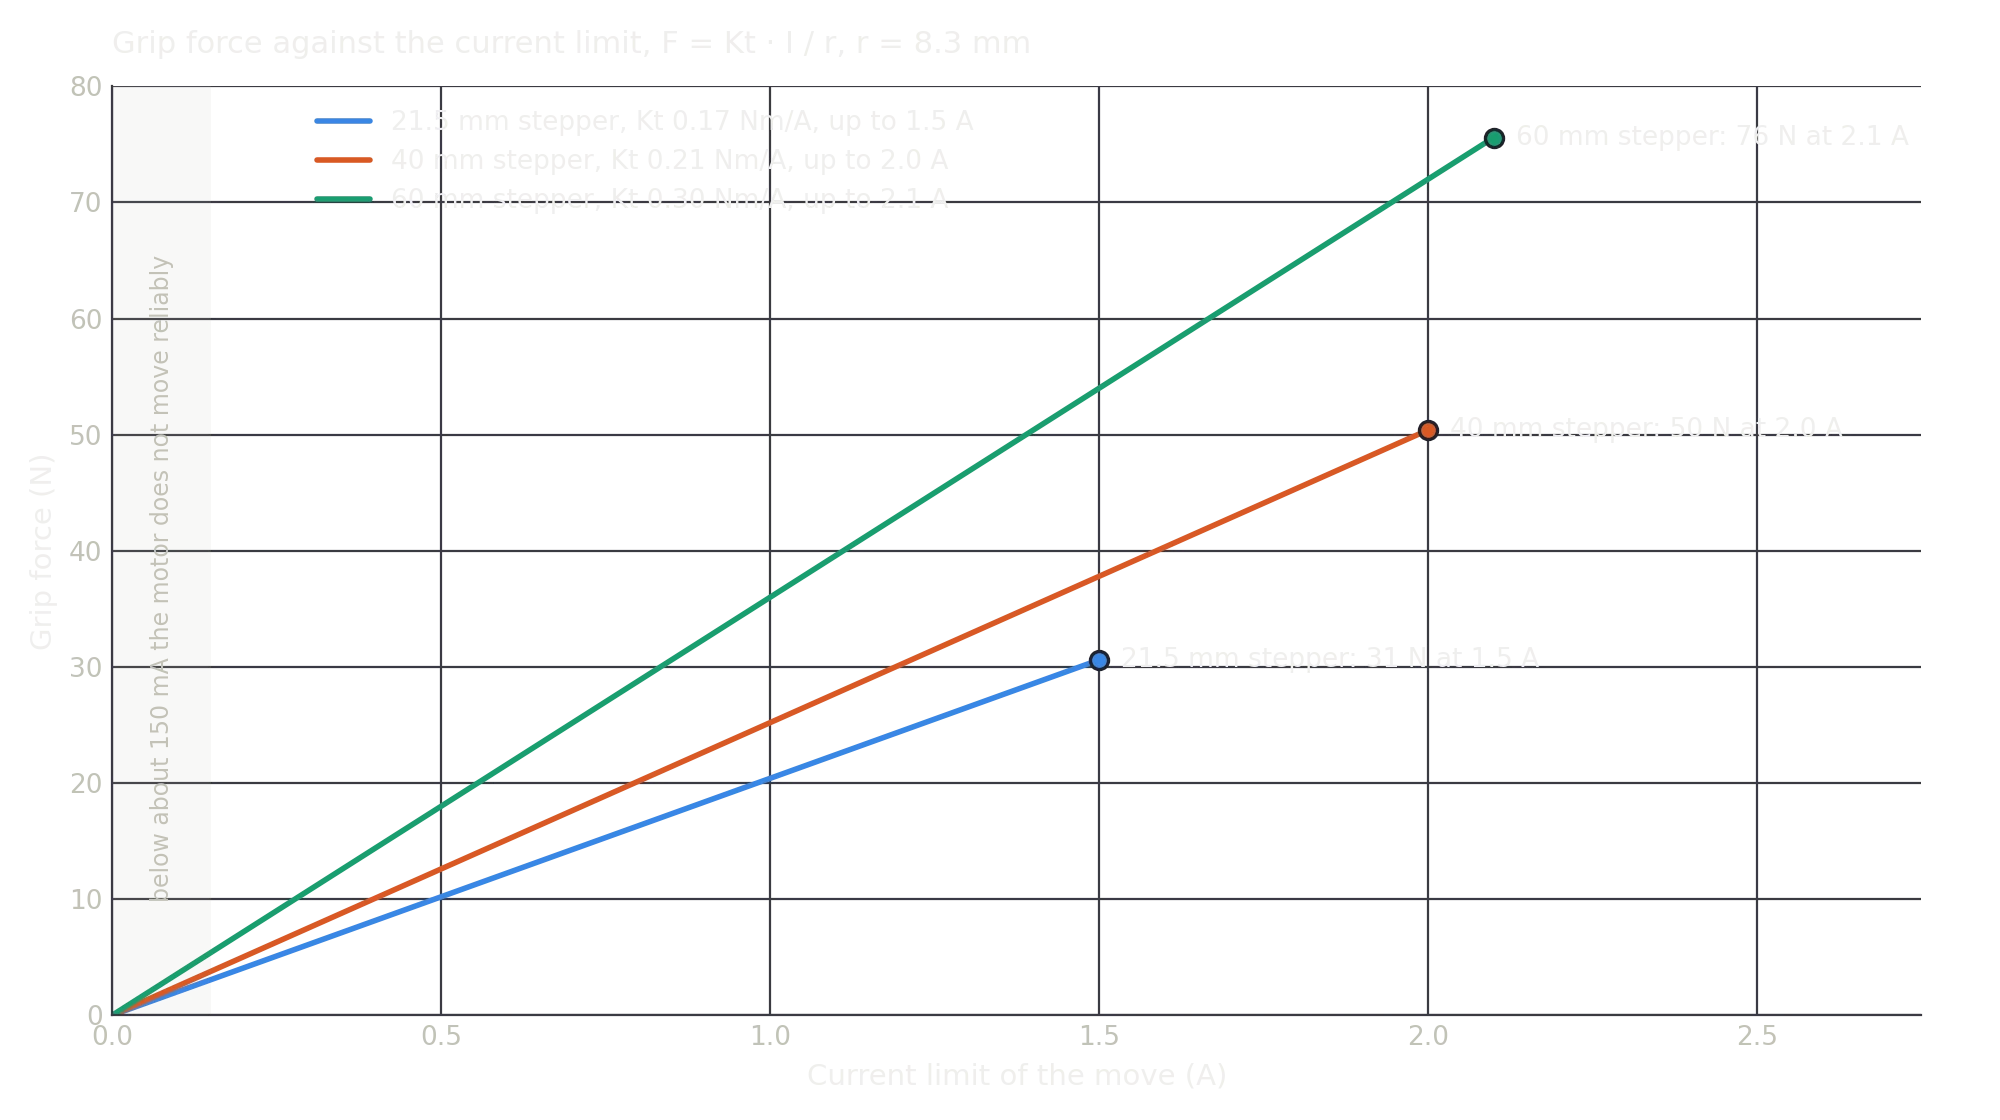
The curves use the listed torque constants; they are not force-gauge measurements. STEPFOC estimates #Kt
from a no-load speed/voltage test, rather than measuring shaft torque. The constant must match the driver's
\(q\)-axis current convention; a motor datasheet's current rating or supply current cannot be substituted directly.
A self-built gripper with another stepper needs its own force calibration. Below about
150 mA the motor does not move reliably, so the usable range starts at a few newtons. Motor GUI commands up to
1500 mA; the full force of the 40 mm and 60 mm steppers needs a command from Python or over CAN.
The current limit caps motor torque; it does not guarantee that the commanded current or the estimated contact force is reached. Mechanism friction, finger flex and the contact position affect the actual force.
Stay within the stepper's maximum
The firmware does not clamp the gripper's current. A current above the stepper's maximum overheats the motor; the thermistor stops the gripper at 75 °C, but a motor driven far over its rating heats faster than the thermistor follows. The maximums are in the table above.
For a symmetric grip, each jaw applies \(F/2\). The torque balance is \(T = F_\mathrm{left} r + F_\mathrm{right} r = F r\); counting \(F\) once for each jaw would count the motor's torque twice. These are theoretical forces before losses in the mechanism. A compression gauge between the jaws reads the force at one contact; double that reading before comparing it with the combined force here. Record the current, fingers and contact position when measuring; the same setup is needed for a useful comparison.
Try it
Ideal combined grip force 10 N · estimated static payload 0.15 kg with the chosen friction and safety factor
Each jaw 24 mm/s · the jaws close at 48 mm/s · the full stroke takes 2.2 s
The formulas of this page, with your numbers: the force from the current and the stepper's torque constant, the weight held by friction with the safety factor of the next section, and the speed from the speed byte over the rail's stroke.
Payload
The grip force is not the weight the gripper can lift. An object held by friction between the two jaws is held by \(\mu(F_\mathrm{left} + F_\mathrm{right}) = \mu F\), with \(\mu\) the friction coefficient between the jaw faces and the object. Dividing the available friction force by a chosen safety factor \(S\) gives the static estimate:
Using an assumed \(\mu\) = 0.3 and \(S\) = 2, the model gives about 11 N of supported weight (1.2 kg) at 76 N of combined grip force, or 4.7 N (0.47 kg) at 31 N. These are static estimates. Upward acceleration of 1 g doubles the load; acceleration and emergency-stop loads need a separate check. Friction can be lower than 0.3, so measure it with your jaws on your object. A form-fit grip needs its own load assessment.
Speed
The speed byte of a move is mapped by the firmware to the motor's speed in encoder ticks per second, linearly from 500 at speed 0 to 60000 at speed 255:
The motor's encoder has 16384 ticks per revolution, so the angular speed is \(\omega = \text{ticks/s} / 16384 \times 2\pi\) and each jaw moves at
| Speed byte | Motor speed | Each jaw moves at | The jaws close at |
|---|---|---|---|
| 0 | 500 ticks/s, 0.03 rev/s | 1.6 mm/s | 3 mm/s |
| 30 | 7500 ticks/s, 0.46 rev/s | 24 mm/s | 48 mm/s |
| 128 | 30400 ticks/s, 1.9 rev/s | 97 mm/s | 190 mm/s |
| 255 | 60000 ticks/s, 3.7 rev/s | 190 mm/s | 380 mm/s |
Both jaws move, so the gap closes at twice the speed of one jaw. At speed 255 a 105 mm stroke takes about 0.3 s. The gripper calibration runs at speed 40 and 500 mA.
Position
The position byte is linear over the stroke: 0 is the fully open end stop found by the gripper calibration, 255 the fully closed one. One step of the byte is the stroke divided by 255: 0.22 mm on the 100 mm rail, 0.41 mm on the 150 mm rail, 0.61 mm on the 200 mm rail. The driver considers the position reached within 5 encoder ticks, about 0.03 mm.
Comments
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF