Bill of materials
This is a copy
The original is BOM.md in the gripper's repository; this page is that file as of
2026-10-31 (commit 9862f62), with the reference images shown inline. If a link is broken or a part is wrong,
open an issue there, and the fix lands here with the next sync. The shop's
starter kit covers the driver and everything its setup needs.
This BOM lists all components required to build the MSG gripper. Quantities are for one gripper.
Note
If any product links are broken, unavailable, or no longer point to the correct item, please open an issue, send us a message on Discord, or contact us via email. You can also use the reference images to find the same or an equivalent part from another supplier.
Screws and Nuts
| Diameter / Type | Length | Quantity | Description | Link |
|---|---|---|---|---|
| M3 nut | 1 | |||
| M4 | 10 mm | 2 | Screw | |
| M3 | 6 mm | 4 | Cheese head screw | |
| M3 | 25 mm | 4 | Screw | |
| M3 | 8 mm | 6 | Screw | |
| M2 | 10 mm | 1 | Screw | |
| M2 | 4 mm | 8 | Screw | |
| M2.5 | 8 mm | 6 | Screw | |
| M2 | 6 mm | 4 | Screw | |
| M3 | 22 mm | 4 | For 17HS08-1004S stepper | |
| M3 | 40 mm | 4 | For 17HS16-2004S1 stepper | |
| M3 | 60 mm | 4 | For 17HS24-2104S stepper |
Brass Inserts
| Thread | Length | Outer Diameter | Quantity | Description | Link |
|---|---|---|---|---|---|
| M3 | 5 mm | 4.5 mm | 8 | 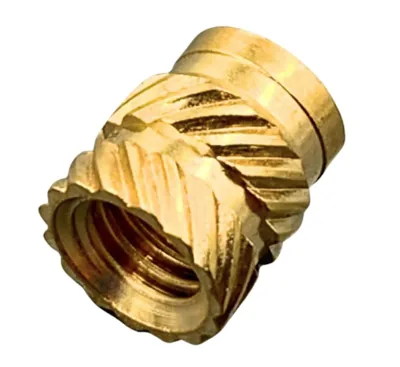 |
Link |
Motors (You need one of these per gripper!)
| Type | Quantity | Description | Link |
|---|---|---|---|
| 17HS08-1004S | 1 | 21.5mm stepper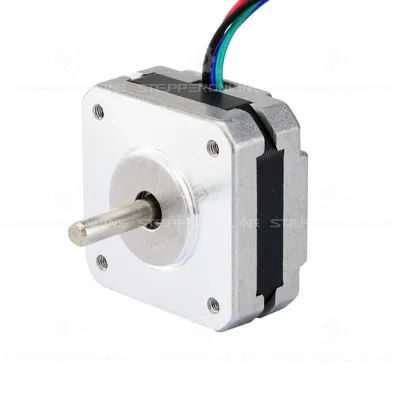 |
Link |
| 17HS16-2004S1 | 1 | 40mm stepper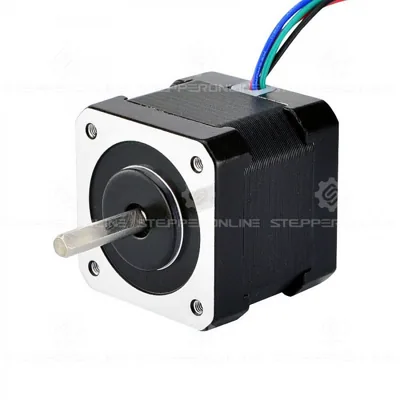 |
Link |
| 17HS24-2104S | 1 | 60mm stepper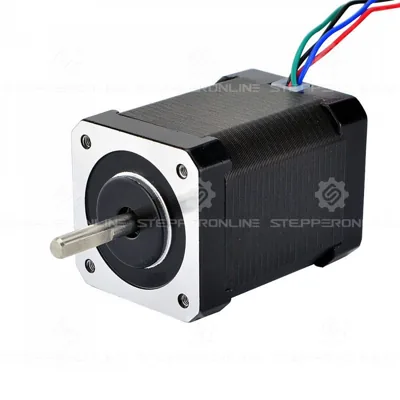 |
Link |
Mechanical Components
| Type | Quantity | Description | Link |
|---|---|---|---|
| Shaft coupler | 1 | 8 mm bore, M4 screw holes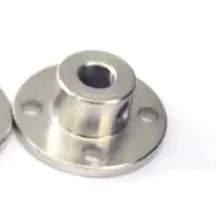 |
Link |
| MGN7C slider | 2 | Linear guide carriage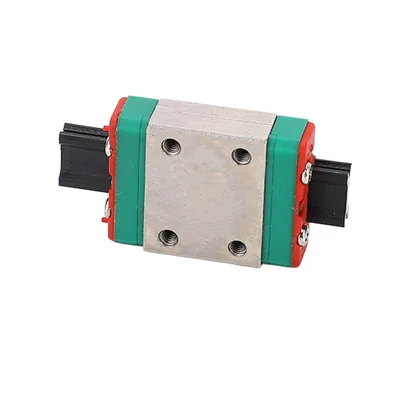 |
Link |
| Linear guide | 1 | 100 mm, 150 mm and 200 length works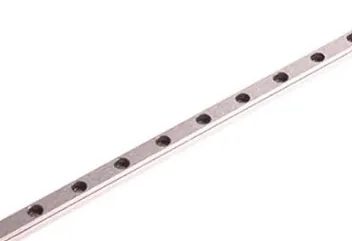 |
Link |
| Diametrical Neodymium Magnet | 1 | 6 mm diameter, 2.5 mm thickness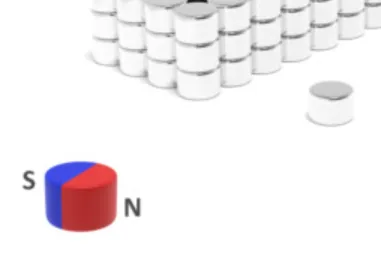 |
Link |
| Magnet 8 x 2.5mm or 8 x 3mm | 1 | 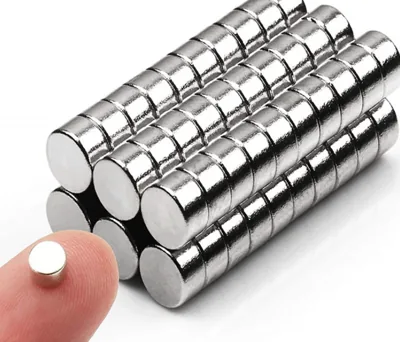 |
Link |
| Gear 32P 21T for 5mm shaft | 1 | 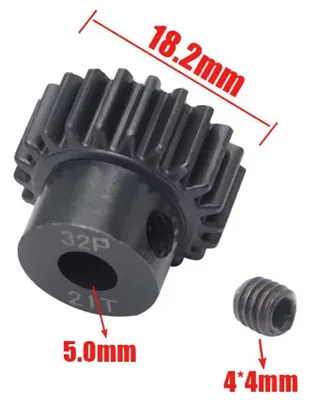 |
Link |
| Thermal cement | 1 |  |
Link |
| Sponge tape — 30 mm width, 1 mm thickness | 1 | Link |
Electronics
| Type | Quantity | Description | Link |
|---|---|---|---|
| STEPFOC motor controller | 1 | Motor controller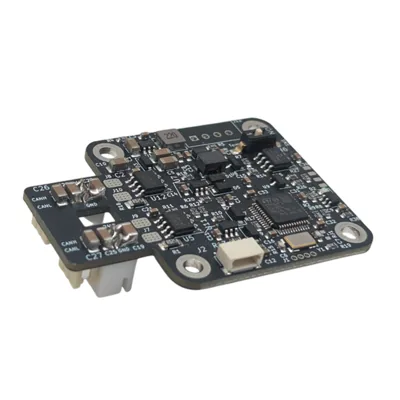 |
Link |
| 100K Thermistor | 1 | NTC temperature sensor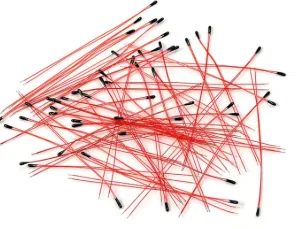 |
Link |
| XH 2.54 mm cable | 1 | 300 mm, 2P, double-ended (24 V power)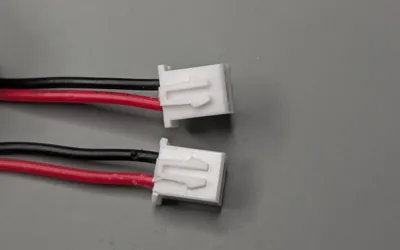 |
Link |
| ZH 1.5 mm cable | 1 | 300 mm, 2P, double-ended (CAN bus)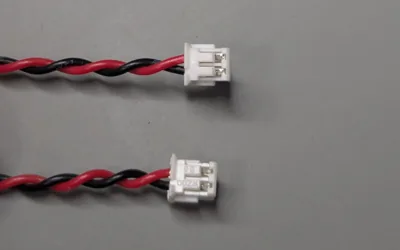 |
Link |
| M8 Male 4-pin connector | 1 | 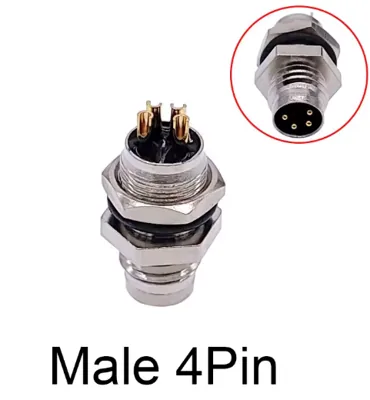 |
Link |
| OV9732 Camera | 1 | 100 Degree version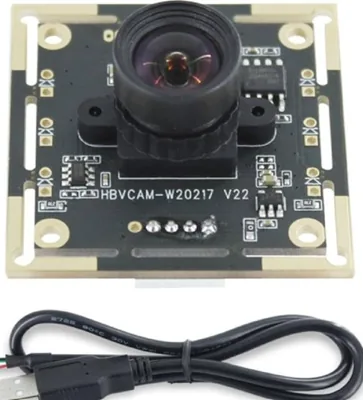 |
Link |
Cables
Note
PAROL6 and PAR6 robots use different cables for SSG48 and MSG grippers. Using incorrect one can damage your robot
Official cables from Source Robotics:
- PAROL6 cable
- PAR6 cable - Coming soon
If you want to build your own cable, use the parts below and follow the wiring guide.
Tip
See the cable building guide in the Assembly manual for full wiring diagrams for both the PAR6 and PAROL6 robots.
| Type | Length / Spec | Quantity | Description | Link |
|---|---|---|---|---|
| 26 AWG cable | 0.15 mm², 4-wire twisted pair | 0.4 m | ~40 cm usually sufficient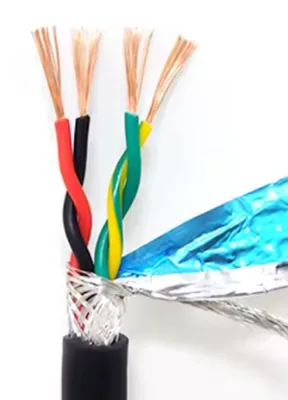 |
Link |
| M8 4-pin male wire connector | — | 1 | 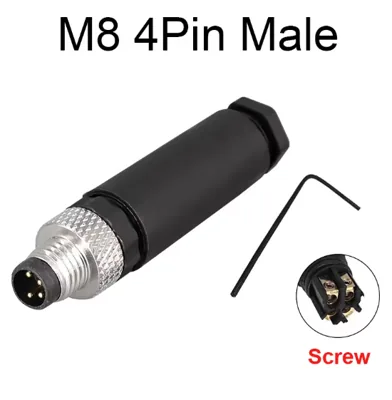 |
Link |
| M8 4-pin female wire connector | — | 1 | 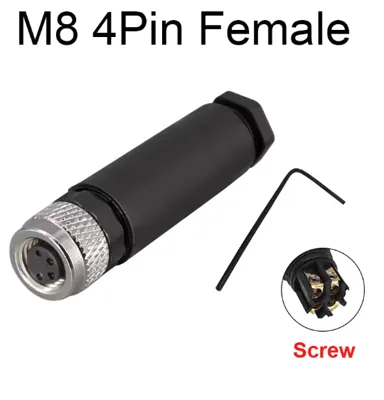 |
Link |
Note
Equivalent parts from other suppliers may be used as long as specifications match.
Comments
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF