Over CAN
CAN is the gripper's interface: the one cable carries it next to the power, and a robot's control board, a PC with the CANvas adapter or any microcontroller with a CAN transceiver drives the gripper with it. The gripper is a STEPFOC driver on the bus, so the frames are the driver's; this page is the part a gripper needs.
The frame
CAN 2.0 data frames with 11-bit identifiers at 1 Mbit/s. The identifier carries the node, the command and the error state:
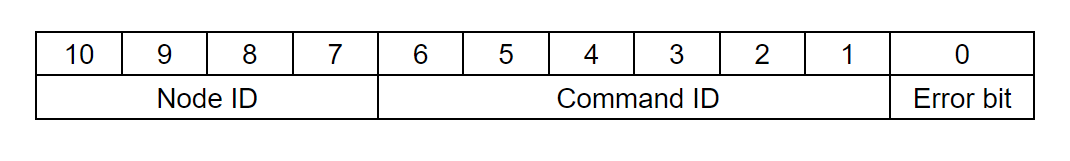
- Node ID, bits 10 to 7: which device. Every gripper ships as node 0; set another with Send_CAN_ID or
#CANIDand save it. Use 0 to 13: the driver's bootloader reserves 14 and 15, and a device on one of those cannot be updated over CAN. - Command ID, bits 6 to 1: which message. The gripper command is 61, its answer 60, the calibration 62.
- Error bit, bit 0: in a frame from the gripper, 1 while any error is active. In a frame from the host it is ignored.
So the gripper command to node 0 travels on identifier (0 << 7) | (61 << 1) = 0x7A, and the answer comes back on
(60 << 1) | error = 0x78 or 0x79; to node 3 the command is 0x1FA and the answer 0x1F8. Multi-byte values are
big-endian; flags inside a byte are numbered from the most significant bit.
The messages a gripper needs
| Message | ID | What for |
|---|---|---|
| Send_gripper_data_pack | 61 | the move command: position, speed, current, the activate, action and E-stop bits; 0 bytes to poll |
| Respond_Gripper_data_pack | 60 | the answer: position, current, the state and error bits |
| Send_gripper_calibrate | 62 | the gripper calibration, after every power-up |
| Send_Clear_Error | 1 | clears the errors |
| Send_ESTOP, Send_Idle | 0, 12 | stop |
| Send_Watchdog | 15 | the gripper stops when the host stops talking |
| Send_CAN_ID, Send_Save_config | 11, 13 | another node ID, saved |
| Send_Respond_State_of_Errors, Send_Respond_Temperature | 26, 23 | the driver's error flags, the motor temperature |
The CAN reference has the bytes of each; the driver's other messages, which a gripper does not need, are on the STEPFOC site.
A control loop
- At power-up: Send_Clear_Error, then Send_gripper_calibrate; poll with empty Send_gripper_data_pack frames until the calibrated bit is 1 (up to about ten seconds; the routine gives up after 24 s). Send nothing else meanwhile.
- For each grip: one Send_gripper_data_pack with the position, speed and current and the activate and action bits set. Its answer still carries the state from before it; ignore it. Then poll with empty frames until the object-detection field reads 1, 2 or 3, or your own timeout passes.
- Keep polling at a steady rate (50 Hz is plenty) if you set the watchdog: every frame resets it, and the gripper stops by itself when your program stops.
The answer to every frame tells the whole state, so a host never has to ask twice.
Host checklist
- Clear, then calibrate. With an error active, the driver drops the calibration request; a clear sent during the calibration ends it.
- During the calibration, only empty frames. A full Send_gripper_data_pack ends the calibration as well, and the gripper stays uncalibrated. Wait for the calibrated bit; the routine gives up after 24 s.
- The first answer is old. The answer to a full command is sent before the gripper acts on it. Ignore it, and give the move about 100 ms before you trust the object detection: at the start of a move the jaws are slow, which can briefly read as an object found.
- The action status repeats your bit. It is the action bit you last sent and stays 1 while the gripper holds. Follow a move by its object detection.
- An identical command does nothing. To repeat a move to the position the gripper holds, change the speed or the current by one.
- E-stop recovery: first a command with the E-stop bit at 0 (and the action bit at 0), then Send_Clear_Error. While the last command carries the E-stop bit, a clear does not hold.
- Watchdog: with Send_Watchdog set, keep the polls coming. The gripper commands and the status requests reset it; Send_Clear_Error and Send_gripper_calibrate do not. After a timeout, fix the host, clear, and resume.
- Current: keep the commanded current within the stepper's maximum, 1.5, 2.0 or 2.1 A; the firmware does not clamp it (Force and speed).
From a PC
The CANvas adapter shows up as a serial port and
speaks slcan; python-can opens it with bustype='slcan', and the Python library wraps the messages.
Any CAN adapter that python-can supports works the same way.
On a bus with other devices
A gripper on a robot shares the bus with the robot's joints or other grippers. Give each device its own node ID (connect one at a time, Send_CAN_ID, Send_Save_config), terminate both ends of the bus (CAN termination), and keep in mind that a lower node ID wins the bus arbitration.
Comments
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF