The gripper at a glance
The SSG-48 is a two-jaw parallel gripper driven by a brushless gimbal motor under field-oriented control. The Spectral Micro driver inside the body regulates the motor's current, so a move sets not only where the jaws go and how fast, but how hard they press: the current limit is the grip force, from about 8 N at 150 mA to about 80 N at 1500 mA. The jaws stop on an object, hold it with that force, and the driver reports that an object was found.
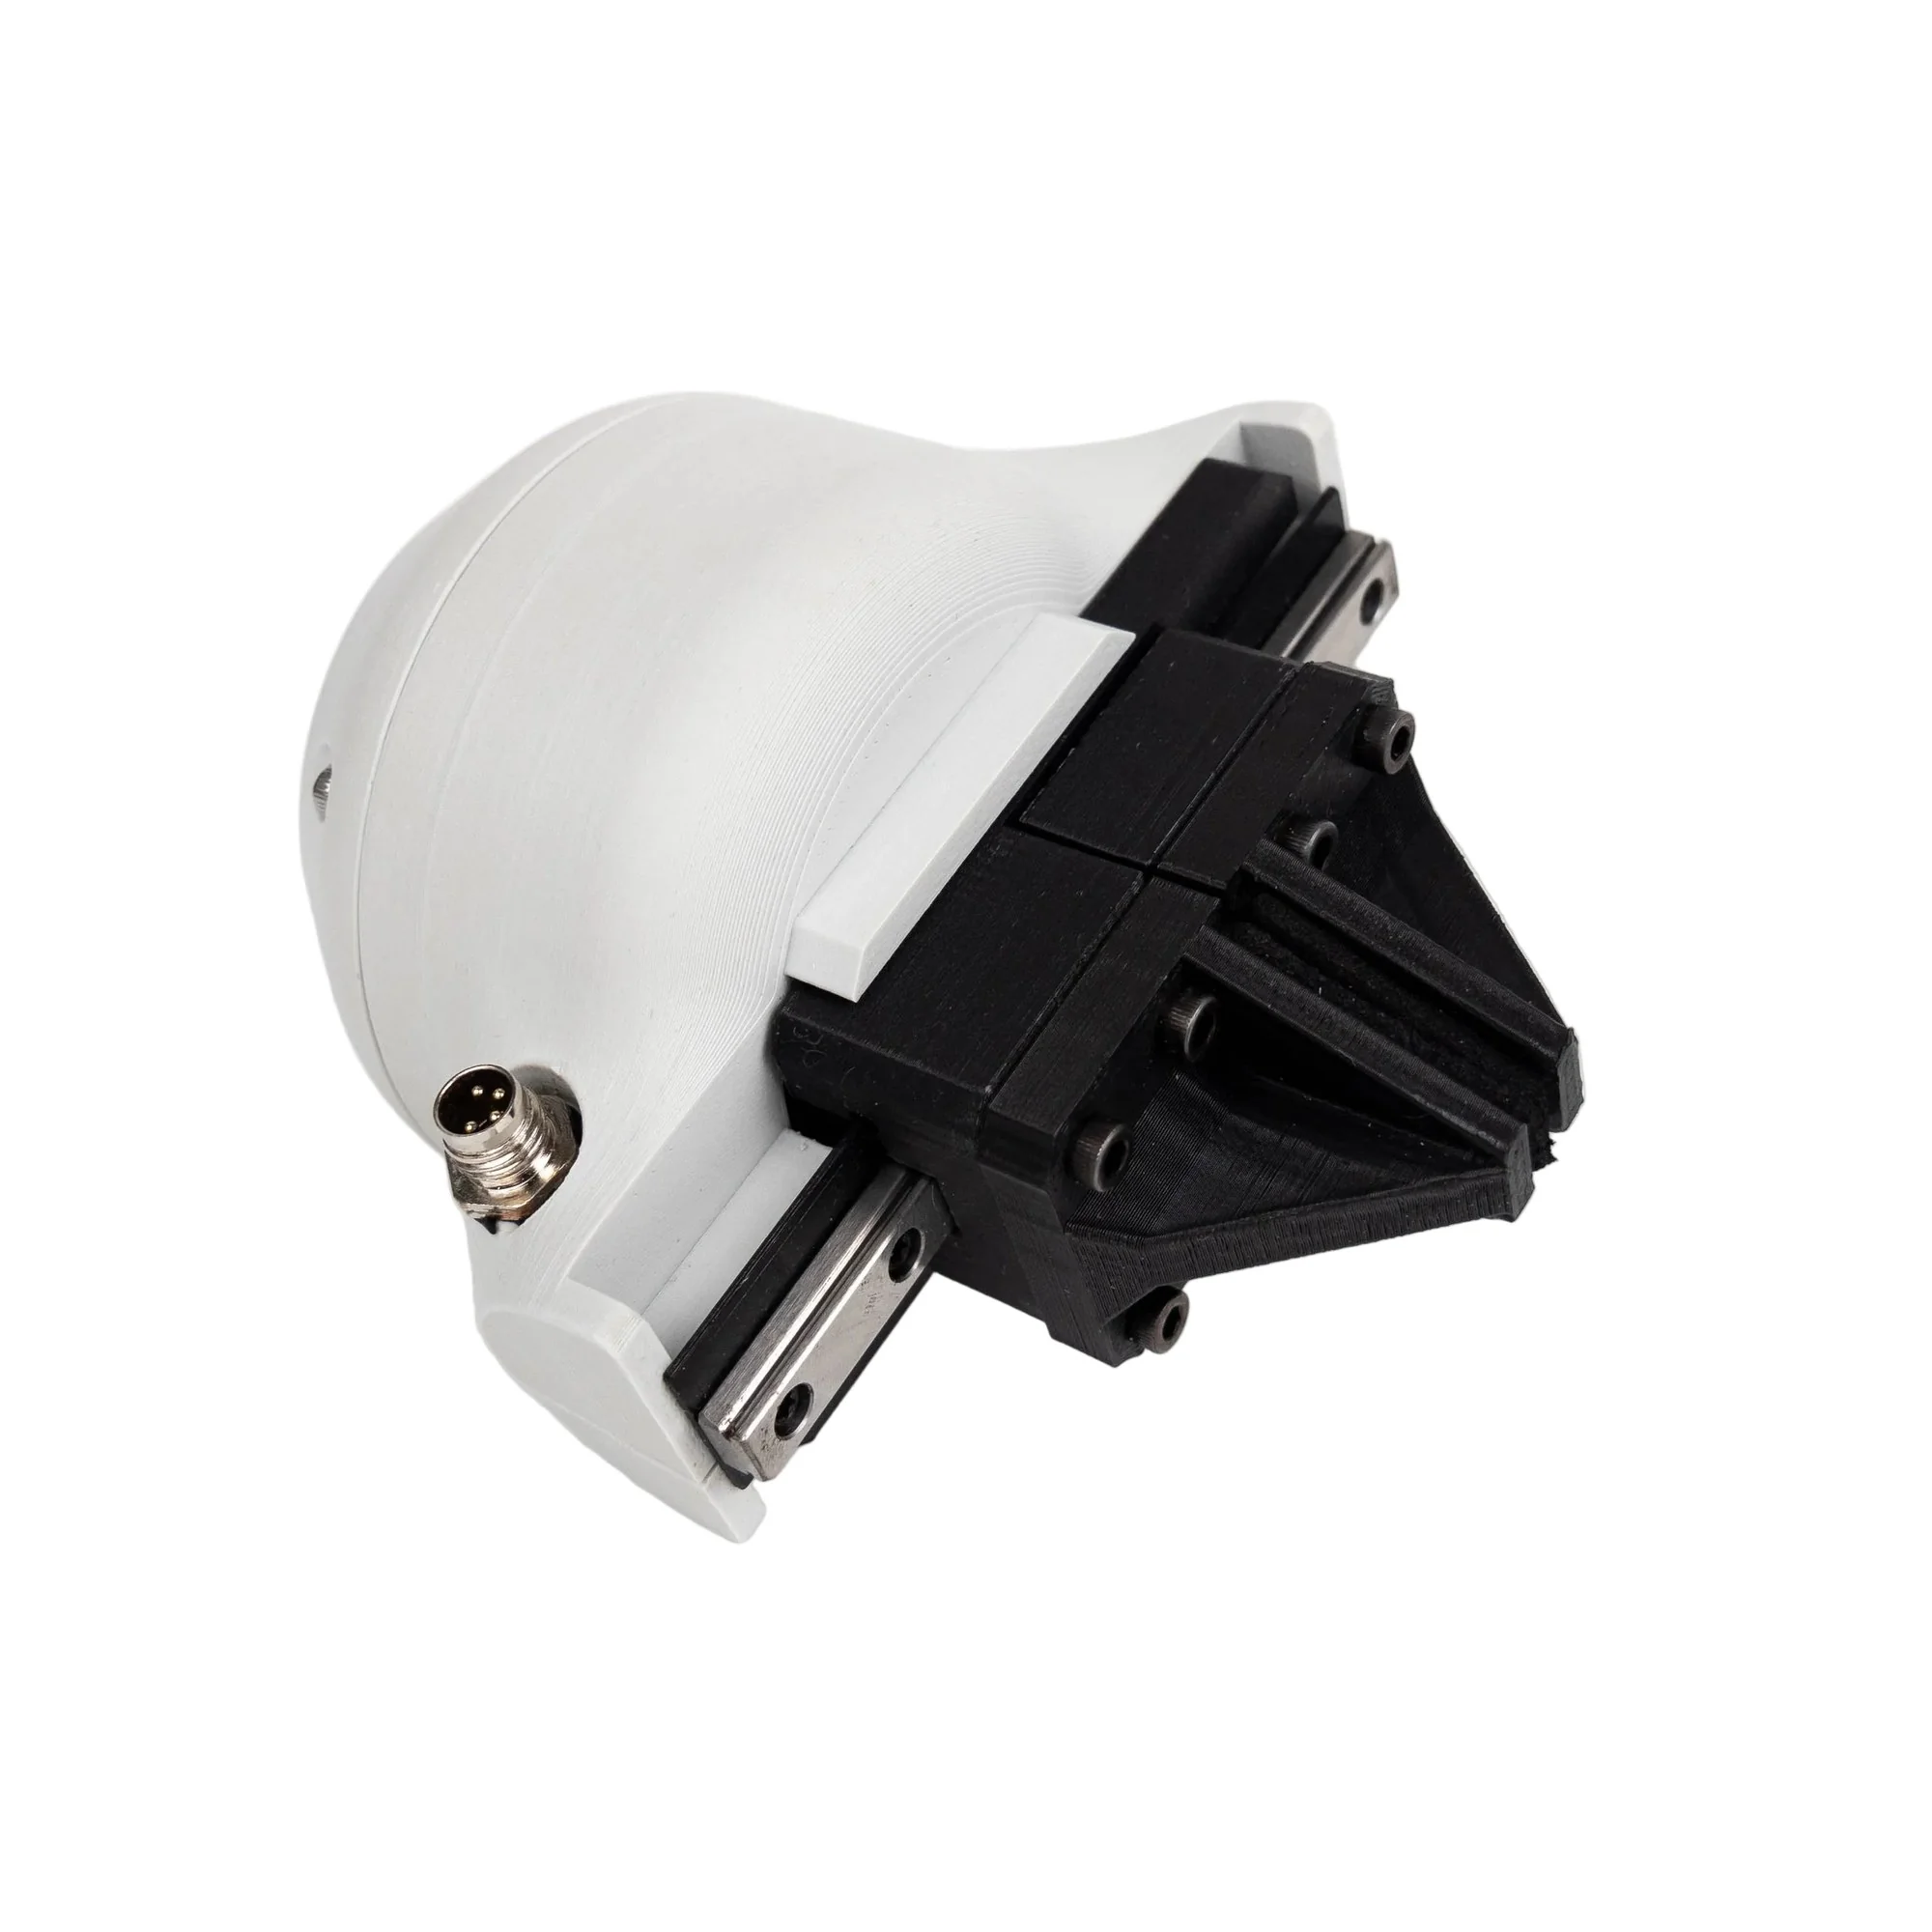
The parts
| Part | What it does |
|---|---|
| GBM5208-75 gimbal motor | the actuator: a brushless motor wound for high torque at low speed and low current |
| Spectral Micro driver, inside the body | field-oriented control of the motor, the gripper state machine, the CAN and UART interfaces |
| Pinion on the motor, two racks on a linear rail | the pinion turns, the two racks move in opposite directions: the jaws open and close symmetrically |
| MGN7 linear rail, 100 mm | carries the two jaw plates; 48 mm of stroke |
| Jaw plates | printed, with a four-hole pattern for your own fingers; fin-ray and pinch fingers in the repository |
| Thermistor in the motor windings | temperature protection: the gripper stops at 75 °C |
| M8 4-pin connector | 24 V and the CAN bus, one cable to the robot |
| Coupler connector | mounts the gripper on the PAROL6 or PAR6 wrist, on a UR5 flange, or on your own with the template |
The driver's status LED, its UART port and its CAN termination switch are inside the body, under the coupler connector.
What the firmware does
After power-up the gripper calibrates by finding both end stops. Then it takes move commands: a position from 0 (open) to 255 (closed), a speed from 0 to 255 and a current limit in mA. When the jaws stop short of the target with the current at its limit, an object is in the way and is held; when they reach the target, the position is held. Every answer carries the state: moving, object found while closing or opening, or at the position. The gripper stops itself on an over-temperature, an E-stop bit from the host, a CAN watchdog that runs out, and every fault the driver detects. How the gripper works and Errors and recovery have the details.
How it is controlled
- CAN, 1 Mbit/s, on the same cable as the power: one message moves the gripper and is answered with its state. From a PC with the CANvas adapter, from a ROS 2 node, from PAROL6 or PAR6, or from your own controller. See Over CAN.
- Python, the
Spectral-BLDClibrary on top of CAN. See With Python. - Motor GUI in the browser: connect, calibrate, open and close, watch the plots. See Motor GUI.
- UART, the driver's serial port inside the body: for configuration, and for a self-built gripper. See Over UART.
The MSG gripper is the SSG-48's successor: the same protocol and software, with a stepper and the STEPFOC driver, three rail lengths and a camera mount. Programs written for one run on the other.
Comments
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF