Waldo Commander (web)
Waldo Commander, by a member of the community, is a browser interface on top of the Python API: control from any device on the network, Python programs with an editor and step-through debugging, a 3D simulation to preview paths, teaching by demonstration recorded as Python, and a built-in MCP server through which an LLM can read the robot's status, write and run programs and drive the arm with your approval. It runs in simulator mode without a robot.
git clone https://github.com/Jepson2k/Waldo-Commander.git
cd Waldo-Commander
pip install -e ".[parol6]"
waldo-commander
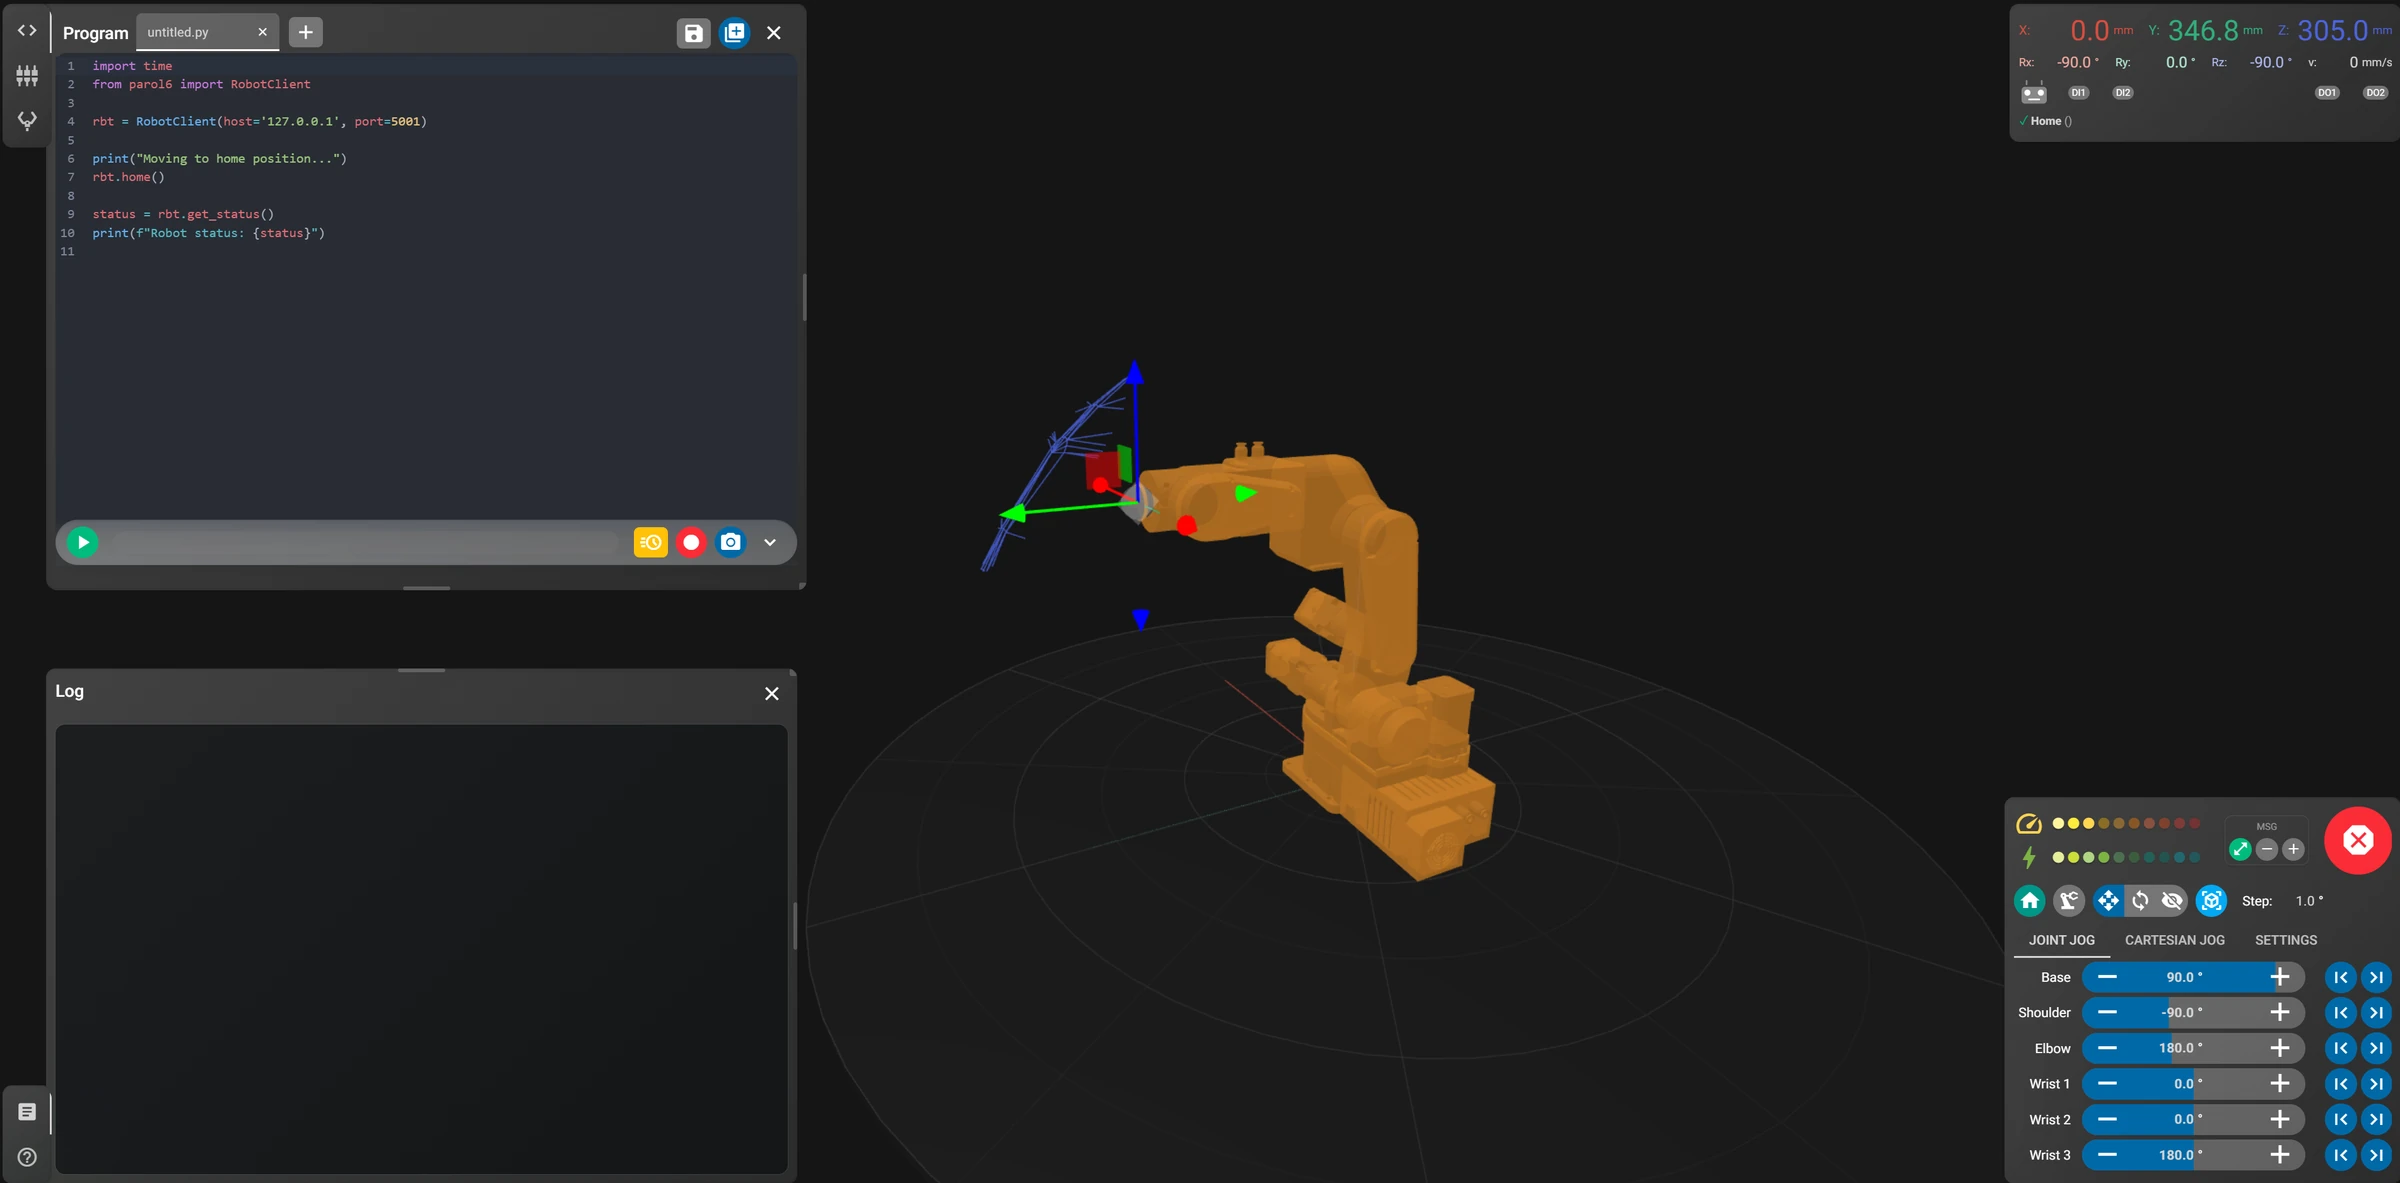
It is built on waldoctl, the abstraction layer the Python API implements, so what it offers tracks the API's features. Its documentation is at jepson2k.github.io/Waldo-Commander.
Comments
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF