The commander software
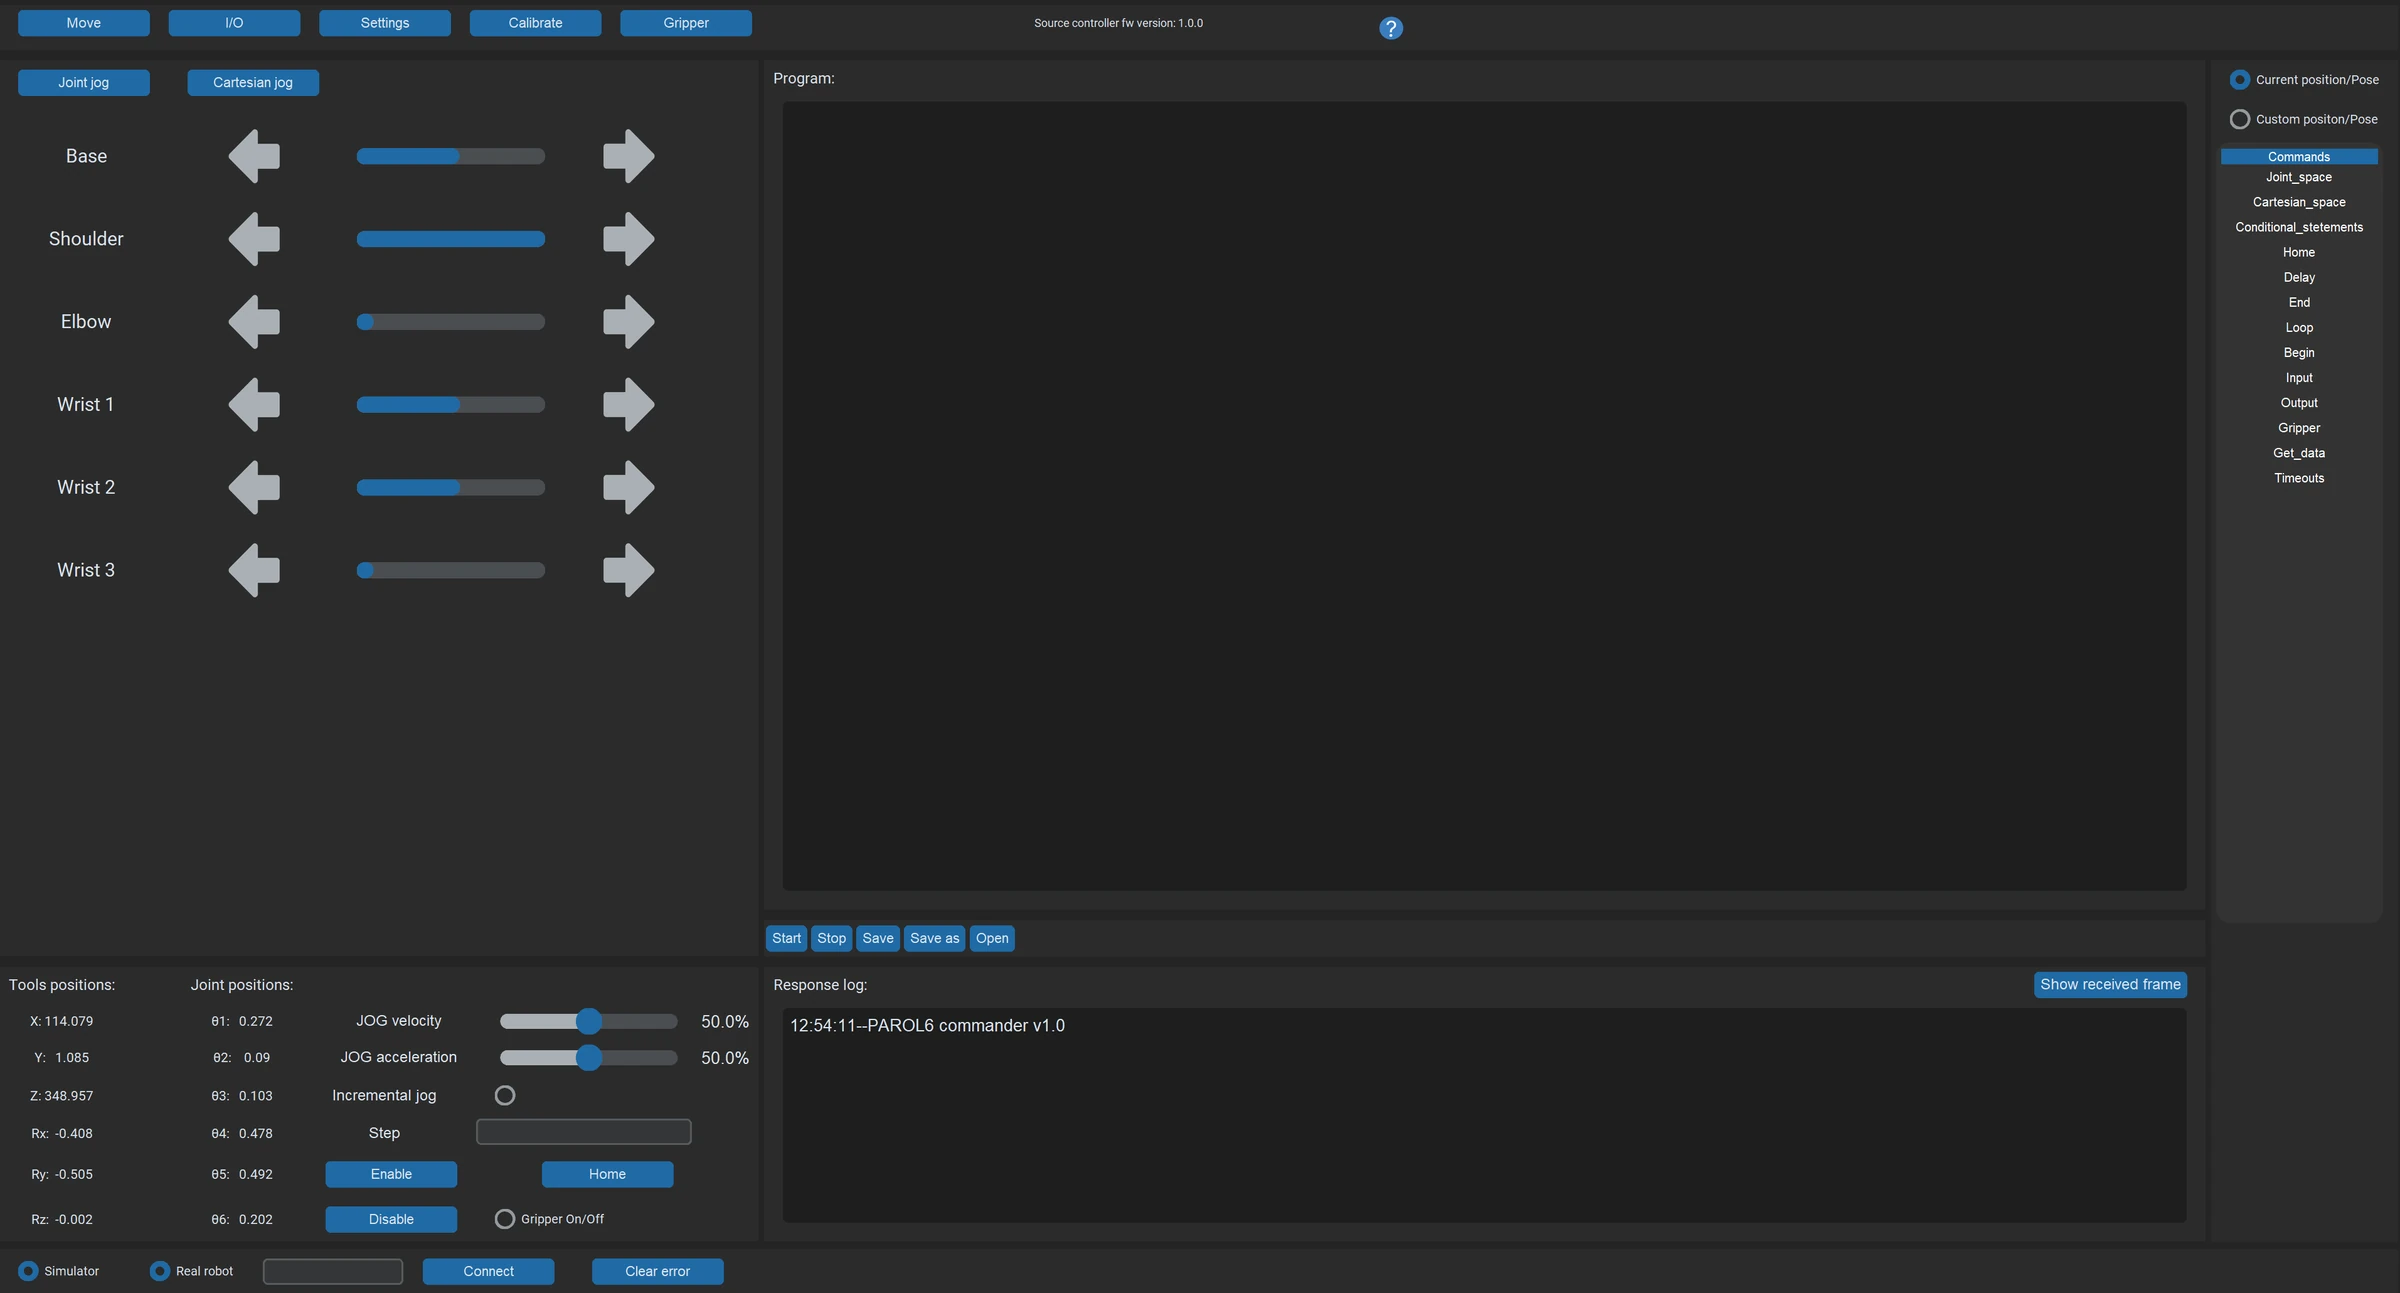
The PAROL6 commander software is the desktop program for using the robot by hand: a GUI with joint and Cartesian jogging, a 3D simulator that mirrors the robot, a response log, a program editor and interpreter for RBTscript, the I/O tab and the gripper tab. It is written in Python with customtkinter and the Robotics Toolbox, runs a 100 Hz loop to the control board, and is the program to start with.
In this guide
- Installation
- The GUI: the windows, the menus, connecting, jogging, the tabs
Its program language, RBTscript, is in the Programming Guide: RBTscript, Examples.
What it is and is not
It is the tool for the first day, for teaching poses, for demos and for simple sequences. It has no blending, no collision checking, no network interface and no tool selection: its kinematic model is the one with the pneumatic gripper. For programs that need those, the Python API. The two cannot be connected to the robot at the same time.
The experimental kinematics branch
The repository's experimental_kinematics branch resolves most Cartesian jogging errors but can command
dangerous motion. The main branch is the safe one; use the other at your own risk.
Comments
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF