The flange
Joint 6 ends in an 8 mm output shaft. Tools clamp onto it with a shaft coupler (8 mm bore, M4 set screws, three in the BOM) that bolts to the tool's holder; the SSG-48 and MSG grippers use a printed coupler connector made for this shaft. The coupler's set screws take blue threadlocker: joint 6 slipping on its shaft is the first thing to check when a tool's orientation drifts (Couplers and threadlocker).
Connections at the forearm
| M8 4-pin connector | 24 V, GND, CAN H, CAN L for an electric gripper; wired from the control board's CAN 1 and 24 V |
| Two pneumatic tubes, 4 mm | From the two push-in fittings at the base, through the arm, to the forearm |
The tubes and the gripper cable run through the arm and come out at the forearm. Joint 5 is held inside its limits by its stops. Joint 6 has no limit with the bare flange; with a tool, the tool's cable and tubes run from the forearm to the tool and wrap as joint 6 turns, so keep joint 6 within the turn they allow (Joint limits and directions).
The tool in the software
The software must know the tool to compute the pose of its tip. The commander's kinematic model is built for the standard pneumatic gripper; the Python API has tool definitions with variants and a settable TCP offset (Tools and the TCP):
rbt.select_tool("PNEUMATIC")                       # default variant: vertical
rbt.select_tool("PNEUMATIC", variant_key="horizontal")
rbt.select_tool("SSG-48", variant_key="pinch")
rbt.select_tool("MSG", variant_key="150mm")
rbt.select_tool("VACUUM")
rbt.select_tool("NONE")                            # the bare flange
Tool centre point
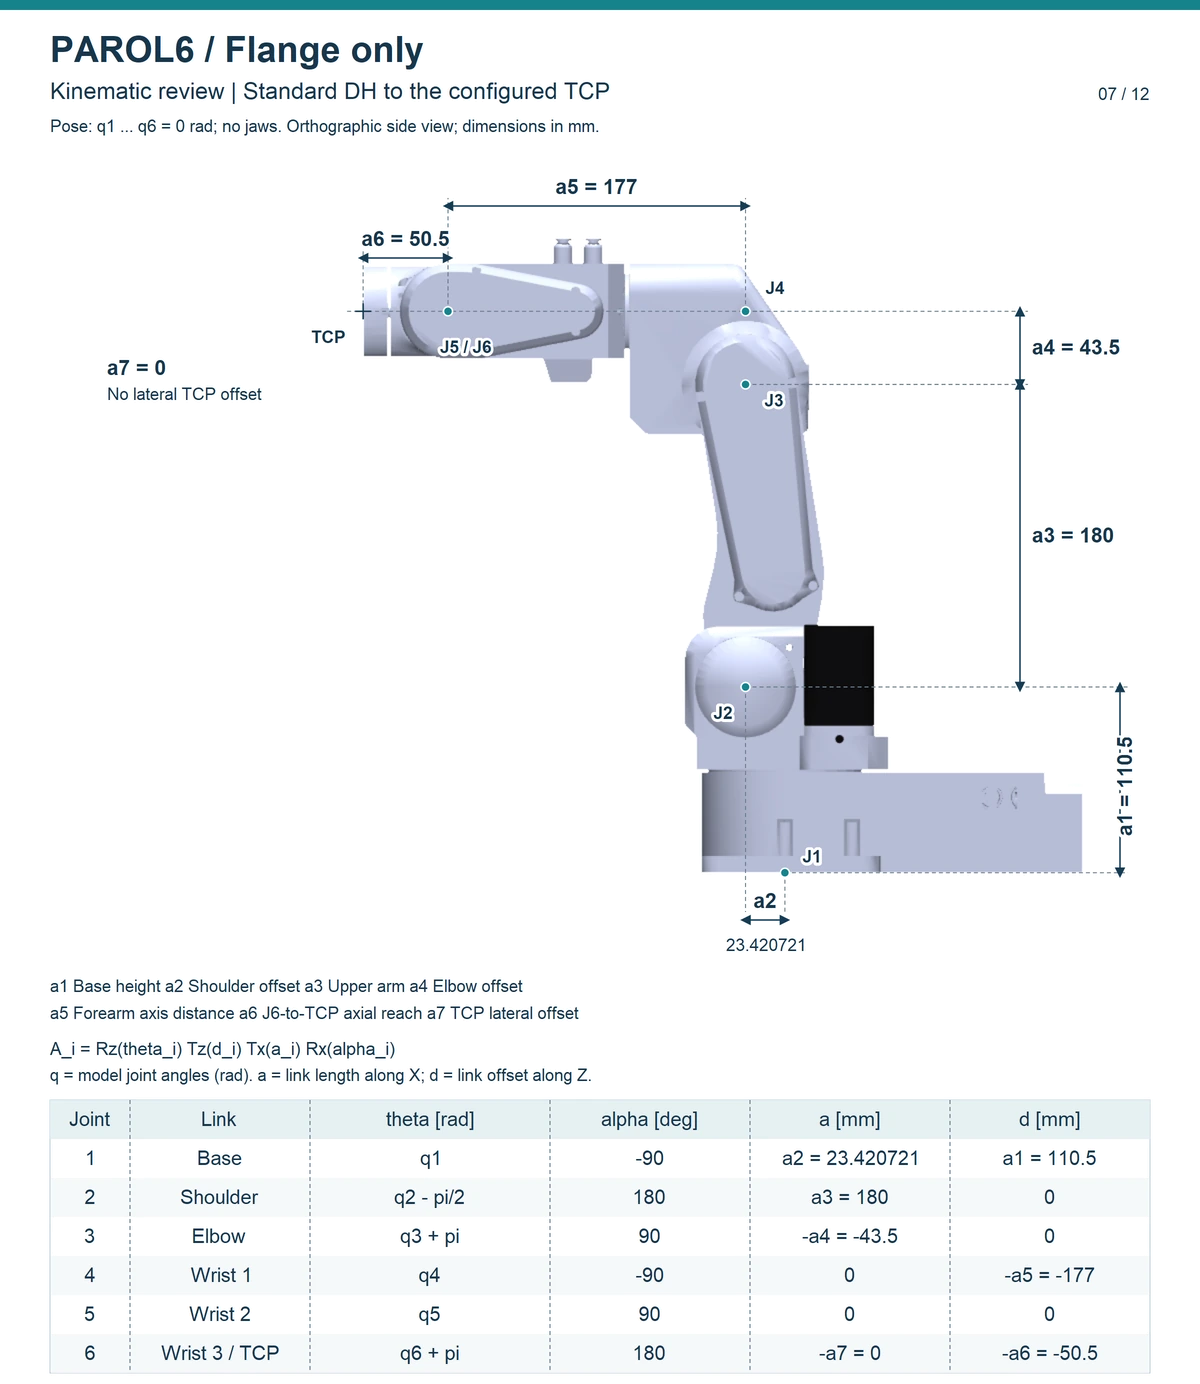
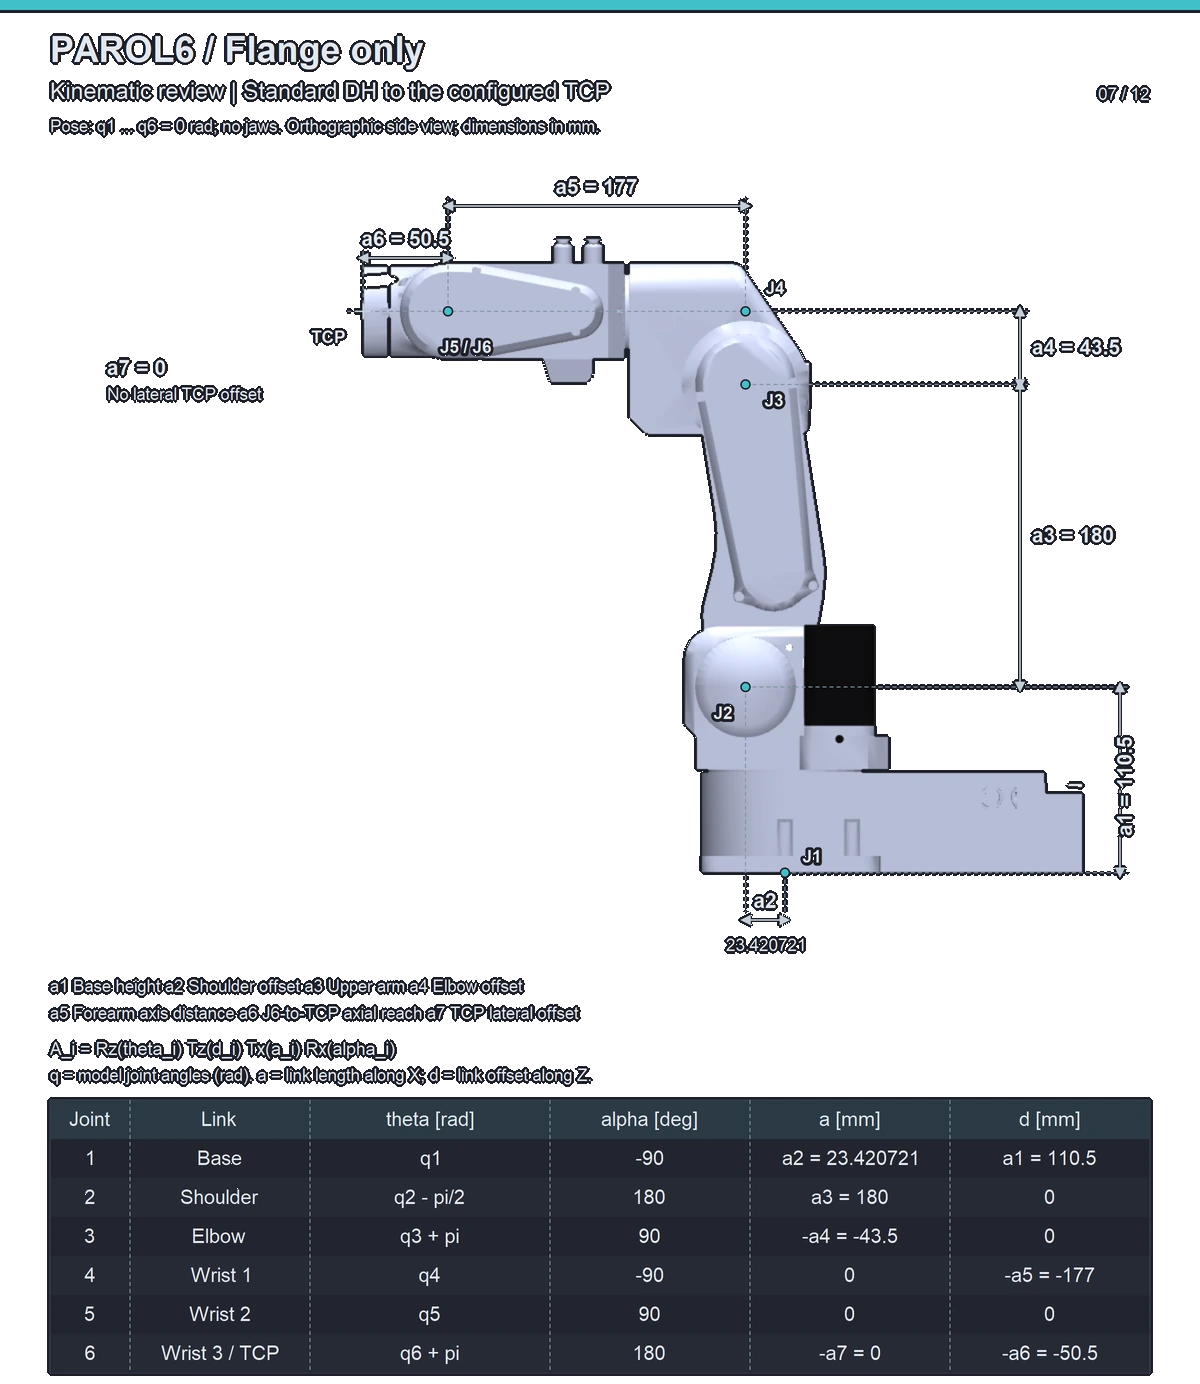
The tool centre point (TCP) is a6 = 50.5 mm from the joint 6 centre along the tool axis and a7 = 0 mm to the side. With nothing on the flange, the TCP is the flange's reference point, the origin of the flange frame: on the joint 6 axis at the flange face, Z out of the flange, X up in the standby pose. The Python API has the frame's Y and Z the other way (Reference frames). The sheet is the robot's model from robot_descriptions (version 2.15.1) with every joint at 0. Tell the software about the tool (Tools and the TCP); every tool is compared on Dimensions and kinematics.
Homing and the tool
Joint 5 homes against a feature of the tool holder. The pneumatic gripper holder and the SSG-48's coupler connector have it; a tool of your own needs it too, and the firmware's joint 5 homing offset must match the tool (Your own tool).
Payload
1 kg near the base, 0.5 kg at full reach, the tool included. A gripper with a camera and a cable can be most of that. A short video shows the arm with a 1 kg payload: PAROL6 robot arm 1kg payload.
Comments
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF