Spectral Micro Manual
Source Robotics d.o.o. publishes this document for the Spectral Micro BLDC driver. It is revised as the product and
its firmware change; the document number, firmware version, revision and date above identify the version you are
reading, and the document history on the About page says what changed. Take care that the firmware version named
under Applies to matches what #Info reports on your driver: the version selector in the header switches
between firmware releases. The text and the images are licensed CC BY-SA 4.0, the code examples MIT.
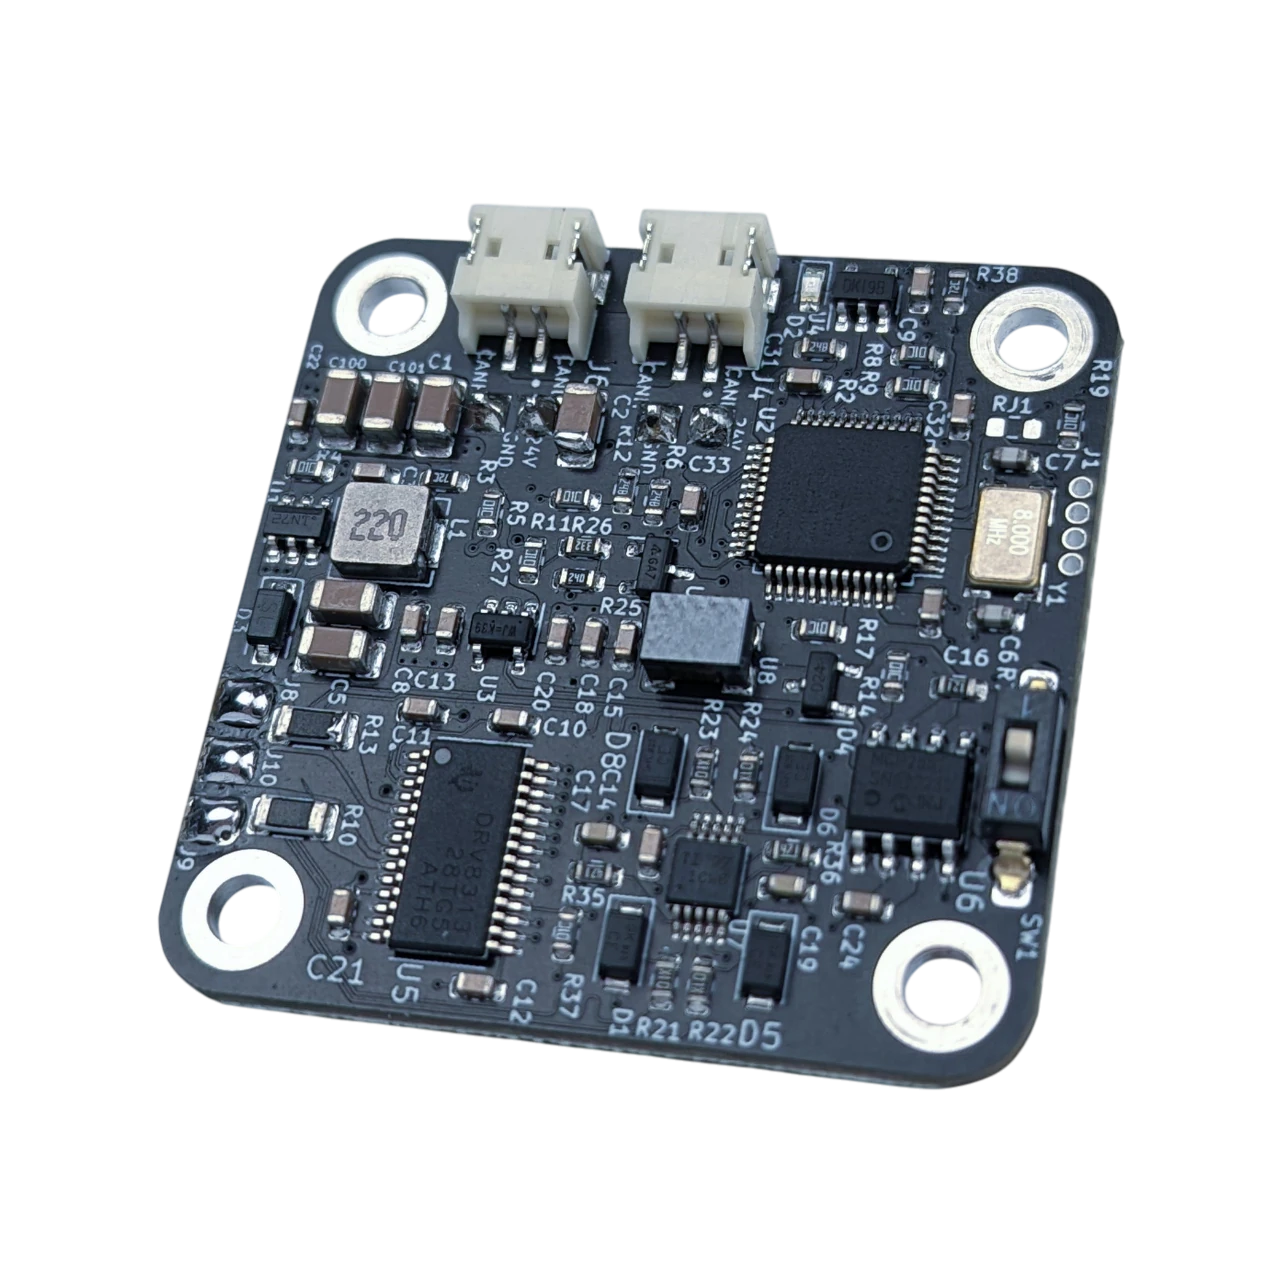
Drag to turn the board, scroll to zoom. The model is the board's STEP file from the repository, the PCB and everything mounted on it.
-
Quick start
One page from the box to a calibrated motor that follows commands, through Motor GUI or the terminal, with a link into the manual at every step.
-
The manual
Safety, Technical data, Mounting and wiring, First setup, Operation, Firmware, Troubleshooting.
-
Motor GUI
The usual way to set up and test: the tool and working in it — connect, calibrate, tune with live plots, record telemetry, update the firmware.
-
API reference
Every CAN message and UART command, the defaults, the errors and the Python library, read from the firmware.
-
Learn
Guides with code, from a mobile robot to a quadruped leg, the bootloader, and the theory corner on FOC, the cascade and impedance control.
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF