Motor parameters and calibration
Calibration teaches the driver its motor: it checks the magnet and the supply, takes the motor's resistance, inductance and pole pairs from you, computes the current loop gains, spins the motor in open loop to learn the direction of the wiring, finds the angle offset between the encoder and the motor's electrical zero, and measures the motor constants Kt, KV and the flux linkage. It runs once per motor; the result is kept by saving.
The motor turns
Calibration spins the motor in both directions, fast at times. Fix the motor to the bench and take everything off the shaft.
Supply voltage
Calibrate at 24 V. At a lower voltage the KV and Kt come out wrong.
1. Restore the defaults
The EEPROM of a new driver, or of one that ran another motor, can hold values that do not fit, such as another
motor's parameters. Calibration starts from what is there, so start from the factory values. (A damaged
configuration should not show up with firmware 106 and newer, which checks the stored blocks at power-up and
replaces a damaged one with the defaults; if #Info still shows -1 somewhere, restoring the defaults fixes it.)
This also sets the CAN node ID to 0 and resets the serial number, hardware version and batch date stored in the
EEPROM; note the hardware version and batch date #Info prints if you need them.
Saving the configuration says what else it does.
2. Enter the motor parameters
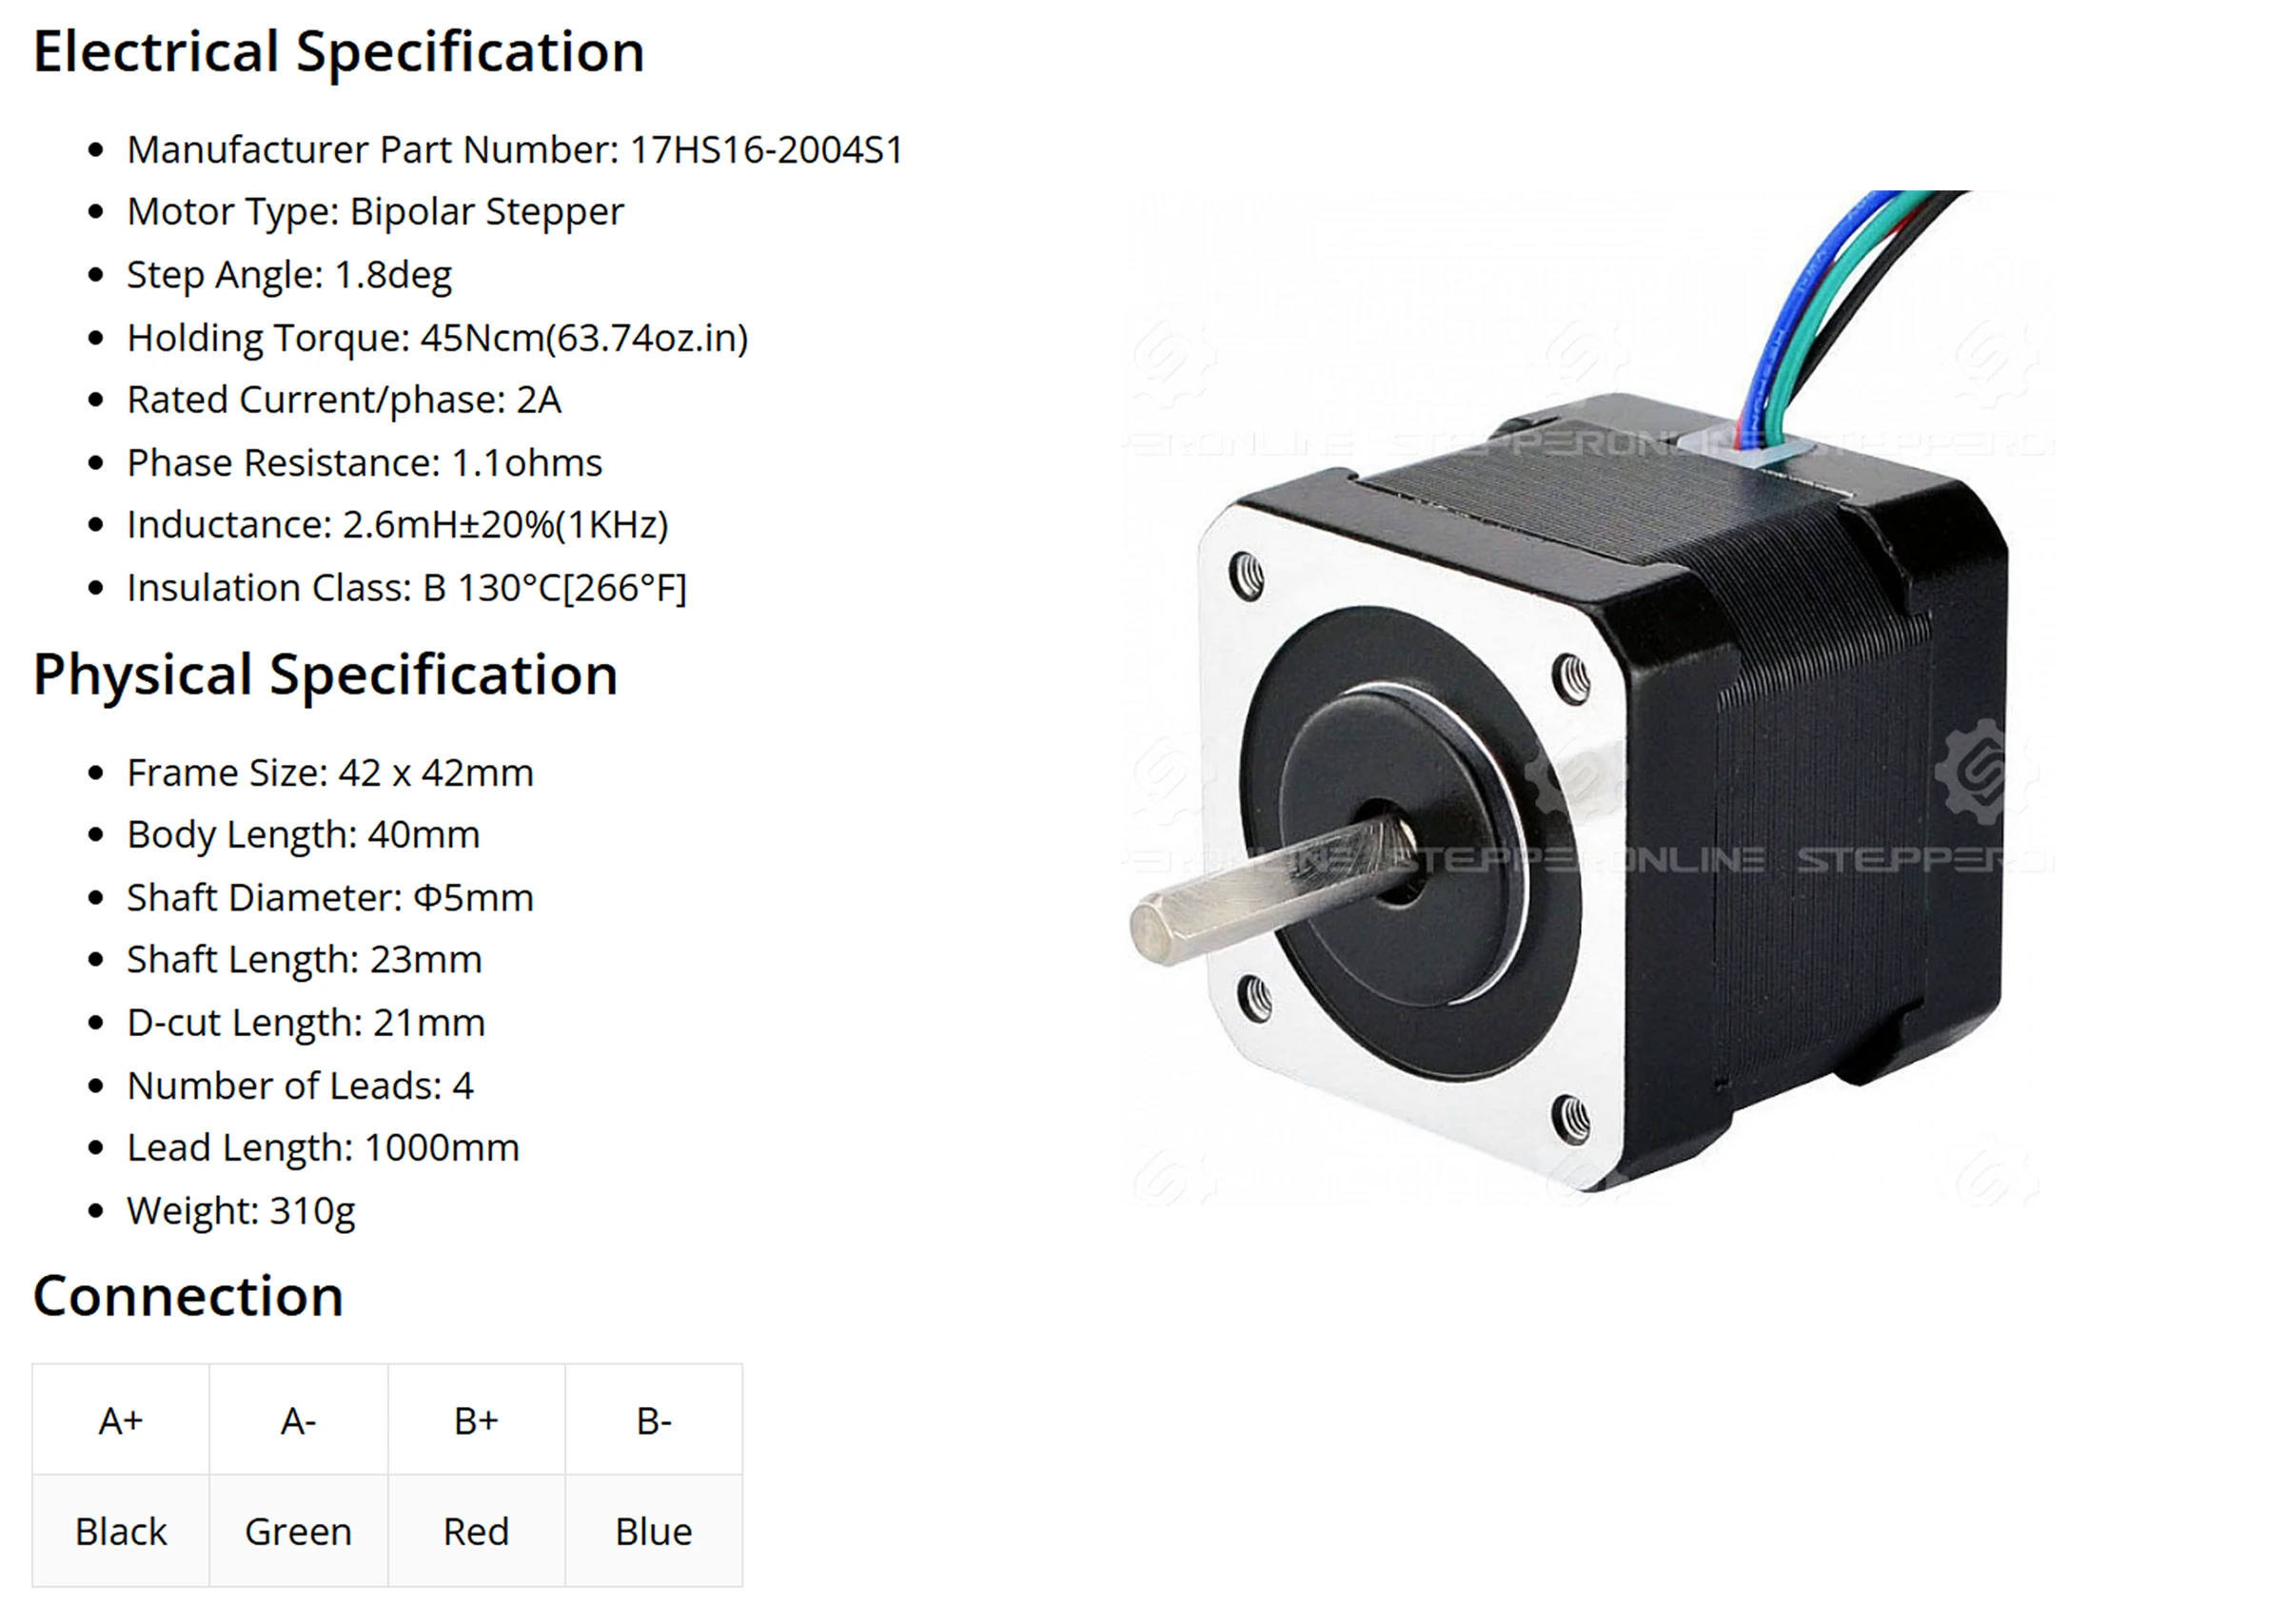
STEPFOC does not measure the resistance and inductance of a stepper (the Spectral Micro does for a BLDC); you enter them from the motor's datasheet, as the values of one coil, and the pole pairs. Calibration fails on a value left at 0, and accepts only 50, 75, 100 or 125 pole pairs.
In the motor settings enter Pole pairs (50 for a 1.8° motor, 75 for 1.2°, 100 for 0.9°, 125 for 0.72°), Resistance in ohms and Inductance in henries, and apply them.
The current loop bandwidth (#Cbw, 500 Hz by default) decides the gains calibration computes from R and L;
leave it for now, Current limit and loop tuning comes back to it. It is not saved: after a power
cycle it is 500 Hz again.
3. Run it
The LED flashes fast while the routine runs, and the driver prints each step as it goes:
----------------
Calibration mode
----------------
Pole pair test: Passed
Magnet test: Passed
Vbus test: Passed
Resistance = 1.100000Ohm
Inductance = 0.002600H
Kp_iq = ...
Ki_iq = ...
Open loop direction: good
Calibrating angle offset... stage 1/13, sweep point 0
...
Angle offset is: ...
Phase order is good!
KV is: ...
Kt is: ...
Flux linkage is: ...
----------------
Calibration success!
Save config with #Save
Going to idle!
----------------
What the steps are:
| Step | What happens | Fails with |
|---|---|---|
| Pole pair test | the entered pole pairs are one of 50, 75, 100, 125 | Pole pair test: Failed and the list of values |
| Magnet test | the encoder sees enough field: a magnet is there and close enough. The test says nothing about centring, the gap or the glue | Magnet test: Failed: magnet missing, too far, or axially magnetised |
| Vbus test | the supply is within limits | Vbus test: Failed |
| Resistance, inductance | the entered values are not 0; they are printed back and Kp_iq, Ki_iq computed from them and the bandwidth | Resistance test: Failed / Inductance test: Failed, with Please enter your stepper resistance by using #R command |
| Open loop | the motor is stepped open loop at a fixed 5000 mV. The direction the encoder saw is remembered, so a reversed coil is compensated from here on | nothing in this firmware: the step always reports good, and a motor that did not turn fails the next step |
| Angle offset | a short spin checks that the motor turns (two tries, 90 electrical degrees apart); then the field locks the rotor and a sweep finds the offset at which both directions turn alike. It prints Calibrating angle offset... with its progress every half second |
Phase order is wrong! / Switch motor phases and try again!: the motor did not turn on either try. A line Spin-confirm delta: … ticks (need > 8192), Vbus: … mV says how far it turned and at what voltage |
| Kt, KV, flux linkage | the motor spins at 500 mA for about a second; KV is the speed it reaches per volt of supply, Kt follows as 8.27 ÷ KV and the flux linkage from Kt | — |
A whole run takes up to about a minute, most of it in the angle-offset search. When a step fails, the log ends
with Calibration failed!, the driver goes to idle, the motor counts as not calibrated and the LED stays on
steadily. Nothing is saved; fix the cause and run #Cal again.
The 'Switch motor phases' message
It is left over from firmware 103, which needed the coils wired a particular way. Since firmware 105 the
wiring is detected and compensated, so Phase order is wrong! / Switch motor phases and try again! means the
motor did not turn or did not respond: a coil not connected or shorted, a supply too weak, or a magnet that
slips. Swapping wires does not fix it. (Open loop: Failed with the same advice cannot appear in this
release.)
The measured values are estimates
KV, Kt and the flux linkage come from one short spin and differ a little from one run to the next, more on motors with uneven windings. For the loops this does not matter; for a torque estimate in newton-metres, measure Kt yourself.
4. Save
Without it the calibration is gone at the next power cycle. The driver goes to idle and the LED shows normal operation; the state shows Calibrated and the constants.
Set the current limit next
Calibration leaves the current limit at 1600 mA, whatever it was before: more than a small motor's rating.
Set it for your motor with #Ilim before the motor runs, and save again
(Current limit and loop tuning).
Check
After a power cycle #Info prints Calibrated and the constants calibration found, and Motor GUI shows
Calibrated. Not calibrated means the save did not happen: calibrate and save again.
When to calibrate again
- After changing the motor, the magnet or the wiring.
- After restoring the defaults.
- After a firmware update that clears the calibration (a release note says so when it does).
A calibration that reports success but a motor that runs badly afterwards usually means the magnet moved on the shaft between calibration and use: fix the magnet and calibrate again.
Troubleshooting
| Message | Cause |
|---|---|
Magnet test: Failed |
no magnet, magnet too far (more than about 1.5 mm), or an axially magnetised magnet |
Vbus test: Failed |
supply off, too low, or the cable the wrong way round (if the driver survived it) |
Resistance test: Failed, Inductance test: Failed |
the resistance or the inductance still 0 |
Phase order is wrong! |
see the note above: the motor did not turn on the spin check; check the four wires and their solder joints, the supply and its current limit, and the magnet |
| the routine stops in a step and prints nothing more | reset the driver (#Reset) and try again; the angle-offset search prints a progress line every half second, so wait for a minute before you decide |
| success, but the LED stays on and no error is reported | should not happen with firmware 106 and newer, which replaces a damaged configuration block with the defaults at power-up. If #Info shows -1 somewhere, restore the defaults, enter the parameters and calibrate again |
#Calangle runs an angle-offset search on its own, with an older routine than the one #Cal uses: it gives up
after about two minutes and keeps the offset it reached. After a change of motor, magnet or wiring, run the whole
#Cal instead.
Calibration runs over the serial connection only: a terminal, or Motor GUI over the serial adapter, not over CAN.
Comments
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF