Errors and LED states
The LED
| Pattern | State |
|---|---|
| three short flashes, a pause | normal operation: calibrated, no error |
| fast flashing, about ten times a second | calibration running |
| a few flashes, then blinking for about 2 s after power-up | the bootloader waits for a host before it starts the firmware; it keeps blinking when there is no valid firmware |
| on, steady | error mode, or not calibrated |
| off | no power, or #LED 0 |
| Normal operation | Calibration | Error mode |
|---|---|---|
 |
 |
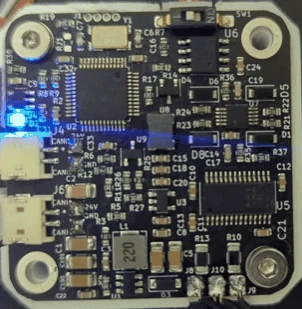 |
The error flags
The flags as the firmware keeps them, the line #Error prints for each, and where each sits in the two bytes of
Send_Respond_State_of_Errors (bits numbered from the most significant).
| Flag | #Error prints |
Byte, bit | Raised when |
|---|---|---|---|
Error |
In error state! |
0, 7 | any of the flags below is set (also the error bit of every CAN identifier) |
temperature_error |
Temp error |
0, 6 | the thermistor reads above #Tlim (with #Term 1) |
encoder_error |
Encoder error |
0, 5 | the encoder reports no magnet (too weak a field) |
Vbus_error |
Vbus error |
0, 4 | the supply is below 9 V or above #Vmax (29000 mV after #Default) |
Driver_error |
Driver error (undervoltage, thermal shutdown, or overcurrent) |
0, 3 | never in this firmware; reserved (STEPFOC reads no fault output of its driver stage) |
Velocity_error |
Velocity error |
0, 2 | the speed exceeds 30,000,000 ticks/s, a fixed threshold (Velocity_limit_error), not #Vlimit |
Current_error |
Current error |
0, 1 | never in this firmware; reserved |
ESTOP_error |
Received ESTOP command |
0, 0 | Send_ESTOP was received |
Calibrated (0) |
Not calibrated |
1, 7 (1 = calibrated) | the motor has not been calibrated |
Activated |
— | 1, 6 | the activated flag, not an error |
Watchdog_error |
Watchdog error |
1, 5 | the watchdog time passed without a motion frame or a status request |
Gripper mode has its own flags in Respond_Gripper_data_pack: a temperature error (a copy of the thermistor error), a timeout error (a copy of the CAN watchdog error, not a move timeout) and an E-stop error, which stays while the E-stop bit is 1; see the Gripper reference.
Clearing
#Clear and Send_Clear_Error clear every flag except Calibrated and go to idle; a flag whose cause persists is
set again at once. The watchdog, E-stop and velocity errors clear and stay clear; the Vbus, encoder and
temperature errors come back until the cause is gone, and so does a gripper E-stop while its E-stop bit is 1.
Calibration clears the calibration error.
Comments
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF