CAN interface
CAN bus should be your primary choice when developing robotic application.
STEPFOC uses 5V CAN bus that adheres to the CAN 2.0 standard. Each STEPFOC driver has 2 CAN bus connectors allowing you to easily daisy chain multiple devices.
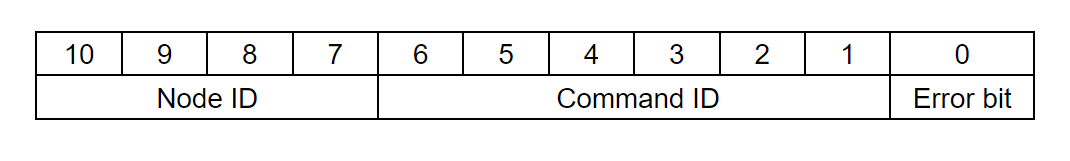
Bits 10 - 7 of CAN ID represent Node ID.
Node IDs can range from 0 - 15 Meaning you can have maximum 16 different devices on one CAN bus.
Bits 6 - 1 of the CAN ID represent Command ID.
Command IDs can range from 0 - 63.
Bit 0 represents error bit. If STEPFOC controller has any active error this bit will be set to 1. Note this bit is send always by the driver and is independent about the command ID and data.
Node with smallest Node ID is strongest in CAN bus arbitration.
If you want to learn more about CAN bus we recommend you read this article!
This page describes can protocol
You can use our Python CAN bus API to communicate with your STEPFOC controllers!
If you want to see more examples on how to write Python scripts to control your motor over CAN check this guide!
List of commands
Message names
Send_... are messages the host sends to the STEPFOC controller. To some of them the driver answers with a message prefixed with Respond.
Respond_... are messages the STEPFOC controller sends to the host.
Send_Respond_... are data the host requests from the controller with a remote frame (RTR bit set). The controller answers with a data frame with the same command ID.
| Command ID | Name | Type | Data |
|---|---|---|---|
| 9 | Respond_Heartbeat |
Respond | None |
| 3 | Respond_data_pack_1 |
Respond | Position [Encoder ticks] Velocity [Encoder ticks/s] Current [mA] |
| 5 | Respond_data_pack_2 |
Respond | Reserved, not used |
| 7 | Respond_data_pack_3 |
Respond | Reserved, not used |
| 60 | Respond_Gripper_data_pack |
Respond | Position Current Gripper activation status Gripper action status Object detection status Temperature error Timeout error Estop error Calibration status |
| 32 | Respond_data_hall |
Respond | Position HALL trigger additional_pin2 |
| Command ID | Name | Type | Data |
|---|---|---|---|
| 2 | Send_data_pack_1 |
Send | Position [Encoder ticks] Velocity [Encoder ticks/s] Current [mA] |
| 6 | Send_data_pack_2 |
Send | Reserved, not used |
| 8 | Send_data_pack_3 |
Send | Reserved, not used |
| 4 | Send_data_pack_PD |
Send | Position [Encoder ticks] Velocity [Encoder ticks/s] Current [mA] |
| 61 | Send_gripper_data_pack |
Send | Position Velocity Current [mA] Gripper activation Gripper action Estop status Release direction |
| 62 | Send_gripper_calibrate |
Send | None |
| 16 | Send_PD_Gains |
Send | KP KD |
| 17 | Send_Current_Gains |
Send | Kpiq Kiiq |
| 18 | Send_Velocity_Gains |
Send | Kpv Kiv |
| 19 | Send_Position_Gains |
Send | Kpp |
| 20 | Send_Limits |
Send | Velocity limit Current limit |
| 22 | Send_Kt |
Send | Kt |
| 11 | Send_CAN_ID |
Send | CAN ID |
| 0 | Send_ESTOP |
Send | None |
| 12 | Send_Idle |
Send | None |
| 13 | Send_Save_config |
Send | None |
| 14 | Send_Reset |
Send | None |
| 1 | Send_Clear_Error |
Send | None |
| 15 | Send_Watchdog |
Send | Time Action |
| 30 | Send_Heartbeat_Setup |
Send | Time |
| 29 | Send_Cyclic_command |
Send | Reserved, not implemented |
| 31 | Send_data_pack_HALL |
Send | Speed trigger_value |
| Command ID | Name | Type | Respond data |
|---|---|---|---|
| 23 | Send_Respond_Temperature |
Send/Respond | Temperature |
| 24 | Send_Respond_Voltage |
Send/Respond | Vbus voltage |
| 25 | Send_Respond_Device_Info |
Send/Respond | Serial number Hardware version Batch date software version |
| 26 | Send_Respond_State_of_Errors |
Send/Respond | Error Temperature error Encoder error Vbus error Driver error Velocity error Current error ESTOP error Calibration status Activated status Watchdog error |
| 27 | Send_Respond_Iq_data |
Send/Respond | Iq current |
| 28 | Send_Respond_Encoder_data |
Send/Respond | Position [Encoder ticks] Velocity [Encoder ticks/s] |
| 10 | Send_Respond_Ping |
Send/Respond | None |
Watchdog
By default watchdog is turned off.
Each valid CAN message received by the STEPFOC controller resets its watchdog timer.
Watchdog measures time between the commands that STEPFOC receives.
If it is bigger than time you set it will report Watchdog error and go to error mode.
To clear the error you will need to call:
"Send_Clear_Error"
Heartbeat
By default the heartbeat is off (rate 0). Send_Heartbeat_Setup turns it on; a rate of 0 turns it off again. Send_Save_config keeps the setting.
Heartbeat is function that will Send "Respond_Heartbeat" msg every time interval you set in "Send_Heartbeat_Setup".
This is useful when your host device needs to see if STEPFOC is connected/alive.
In case your STEPFOC sends any other data (as a response to command) it will reset its heartbeat timer.
Heartbeat timer reset
For example if STEPFOC is sending data every 10ms and heartbeat is setup to send every 1s; heartbeat will never send its data.
Cyclic
Not implemented
Command ID 29 (Send_Cyclic_command) is reserved. The firmware has no handler for it, and the Python library's Send_Cyclic_command() does nothing.
Commands
Bit numbering
In the tables below, bit numbers count from the most significant bit of the byte: bit 7 is the first flag the firmware packs into the byte, bit 0 the last.
Respond_Heartbeat
This is the command that driver will send as its heartbeat every X ms. It is an empty data frame.
- Command ID: 9
- Direction: driver -> host
- Python call: None, this command is sent only by driver
- Length: 0 byte
- Type of frame: standard
Respond_data_pack_1
This is the command that driver will send as a response to movement commands like Send_data_pack_1 and Send_data_pack_PD.
- Command ID: 3
- Direction: driver -> host
- Python call: None, this command is sent only by driver
- Length: 8 byte
- Type of frame: standard
| Size (bytes) | Variable (Spectral_BLDC Lib python attribute) | Type | Details |
|---|---|---|---|
| 0 - 2 | position | signed 24bit | unit is encoder ticks |
| 3 - 5 | speed | signed 24bit | unit is encoder ticks/s |
| 6 - 7 | current | signed 16bit | unit is mA |
Respond_Gripper_data_pack
This is the command that driver will send as a response to Send_gripper_data_pack.
- Command ID: 60
- Direction: driver -> host
- Python call: None, this command is sent only by driver
- Length: 4 byte
- Type of frame: standard
| Size (bytes) | Variable (Spectral_BLDC Lib python attribute) | Type | Details |
|---|---|---|---|
| 0 | gripper_position | unsigned 8bit | 255 fully closed, 0 fully open |
| 1-2 | gripper_current | 16 bit signed | measured current, unit mA |
| 3 (bit 7) | gripper_activated | bit (0/1) | gripper activate (1) / deactivated (0) |
| 3 (bit 6) | gripper_action_status | bit (0/1) | 1 is goto, 0 is idle or performing auto release or in calibration |
| 3 (bits 5 and 4) | gripper_object_detection | 2 bits; bit 5 is the low bit, bit 4 the high bit | 0 in motion, 1 object detected closing, 2 object detected opening, 3 at position |
| 3 (bit 3) | gripper_temperature_error | bit (0/1) | gripper_temperature_error |
| 3 (bit 2) | gripper_timeout_error | bit (0/1) | gripper_timeout_error |
| 3 (bit 1) | gripper_estop_error | bit (0/1) | gripper_estop_error |
| 3 (bit 0) | gripper_calibrated | bit (0/1) | gripper calibration status; calibrated (1) / not calibrated (0) |
Respond_data_hall
This is the command that driver will send as a response to Send_data_pack_HALL. It will return motor position in encoder ticks and state of the hall pin.
- Command ID: 32
- Direction: driver -> host
- Python call: None, this command is sent only by driver
- Length: 4 byte
- Type of frame: standard
| Size (bytes) | Variable (Spectral_BLDC Lib python attribute) | Type | Details |
|---|---|---|---|
| 0 - 2 | position | signed 24bit | unit is encoder ticks |
| 3 (bit 7) | HALL_trigger | bit (0/1) | 1 while waiting for the trigger, 0 once it has triggered |
| 3 (bit 6) | additional_pin2 | bit (0/1) | RAW pin state |
Send_data_pack_1
This command will place the driver in position, speed or current control mode depending on the amount of parameters you give it.
Note that if you don't want feedforward just set it to 0.
- Command ID: 2
- Direction: Host -> driver
- Python call: Send_data_pack_1()
- Type of frame: standard
- Length: 8 byte - If using position setpoint with speed and current feedforward
| Size (bytes) | Variable | Type | Details |
|---|---|---|---|
| 0 - 2 | Position setpoint | signed 24bit | unit is encoder ticks |
| 3 - 5 | Velocity feedforward | signed 24bit | unit is encoder ticks/s |
| 6 - 7 | Current feedforward | signed 16bit | unit is mA |
- Length: 5 byte - If using speed setpoint and current feedforward
| Size (bytes) | Variable | Type | Details |
|---|---|---|---|
| 0 - 2 | Velocity setpoint | signed 24bit | unit is encoder ticks/s |
| 3 - 4 | Current feedforward | signed 16bit | unit is mA |
- Length: 2 byte - If using current setpoint
| Size (bytes) | Variable | Type | Details |
|---|---|---|---|
| 0 - 1 | Current setpoint | signed 16bit | unit is mA |
Driver will respond to this command with:
Respond_data_pack_1
Send_data_pack_PD
This command will place the driver in impedance PD control mode.
- Command ID: 4
- Direction: Host -> driver
- Python call: Send_data_pack_PD()
- Type of frame: standard
- Length: 8 byte
| Size (bytes) | Variable | Type | Details |
|---|---|---|---|
| 0 - 2 | Position | signed 24bit | unit is encoder ticks |
| 3 - 5 | Velocity | signed 24bit | unit is encoder ticks/s |
| 6 - 7 | Current | signed 16bit | unit is mA |
Driver will respond to this command with:
Respond_data_pack_1
Send_data_pack_HALL
This command will try spin the motor at set speed until the hall sensor attached to additional_pin2 on the driver triggers.
- Command ID: 31
- Direction: Host -> driver
- Python call: Send_data_pack_HALL()
- Type of frame: standard
- Length: 4 byte
| Size (bytes) | Variable | Type | Details |
|---|---|---|---|
| 0 - 2 | speed | signed 24bit | unit is encoder ticks/s |
| 3 (bit 7) | trigger_value | bit (0/1) | the sensor level that triggers: 0 or 1 |
Driver will respond to this command with:
Respond_data_hall
Send_gripper_data_pack
This command will command the motor (SSG48 gripper) to move to specific position with speed/torque.
- Command ID: 61
- Direction: Host -> driver
- Python API reference: Send_gripper_data_pack()
- Type of frame: standard
- Length: 5 byte
| Size (bytes) | Variable | Type | Details |
|---|---|---|---|
| 0 | Position | unsigned 8bit | 0 fully open, 255 fully closed |
| 1 | Velocity | unsigned 8bit | 0 min speed, 255 max speed |
| 2-3 | Current | signed 16bit | current limit for the move, unit mA; the firmware does not clamp it, see the gripper manual for the safe range |
| 4 (bit 7) | Gripper activate | bit (0/1) | 0 deactivate the gripper, 1 activate the gripper |
| 4 (bit 6) | Gripper action status | bit (0/1) | 1 go to the position, 0 idle |
| 4 (bit 5) | Gripper estop status | bit (0/1) | 1 raises the gripper E-stop error |
| 4 (bit 4) | Gripper release direction | bit (0/1) | read by the firmware but not used |
Driver will respond to this command with:
Respond_Gripper_data_pack
Alternatively you can send empty Send_gripper_data_pack command.
- Command ID: 61
- Direction: Host -> driver
- Python API reference: Send_gripper_data_pack()
- Type of frame: standard
- Length: 0 byte
Driver will respond to this command with:
Respond_Gripper_data_pack
Send_gripper_calibrate
This command will start gripper calibration. It is an empty data frame.
- Command ID: 62
- Direction: Host -> driver
- Python API reference: Send_gripper_calibrate()
- Type of frame: standard
- Length: 0 byte
Driver will not respond to this command!
Send_PD_Gains
This command will set KP and KD gains for the PD impedance loop.
- Command ID: 16
- Direction: Host -> driver
- Python API reference: Send_PD_Gains()
- Type of frame: standard
- Length: 8 byte
| Size (bytes) | Variable | Type |
|---|---|---|
| 0 - 3 | KP | float 32 |
| 4 - 7 | KD | float 32 |
Driver will not respond to this command!
Send_Current_Gains
This command will set Ki and Kp PI parameters for the PI current control loop.
- Command ID: 17
- Direction: Host -> driver
- Python API reference: Send_Current_Gains()
- Type of frame: standard
- Length: 8 byte
| Size (bytes) | Variable | Type |
|---|---|---|
| 0 - 3 | Kp_iq | float 32 |
| 4 - 7 | Ki_iq | float 32 |
Driver will not respond to this command!
Send_Velocity_Gains
This command will set Ki and Kp PI parameters for the PI speed/velocity control loop.
- Command ID: 18
- Direction: Host -> driver
- Python API reference: Send_Velocity_Gains()
- Type of frame: standard
- Length: 8 byte
| Size (bytes) | Variable | Type |
|---|---|---|
| 0 - 3 | Kpv | float 32 |
| 4 - 7 | Kiv | float 32 |
Driver will not respond to this command!
Send_Position_Gains
This command will set Kp P parameter for the P position control loop.
- Command ID: 19
- Direction: Host -> driver
- Python API reference: Send_Position_Gains()
- Type of frame: standard
- Length: 4 byte
| Size (bytes) | Variable | Type |
|---|---|---|
| 0 - 3 | Kpp | float 32 |
Driver will not respond to this command!
Send_Limits
This command will set velocity/speed and current limits.
This will limit max speed and current that can be reached during motor operation.
- Command ID: 20
- Direction: Host -> driver
- Python API reference: Send_Limits()
- Type of frame: standard
- Length: 8 byte
| Size (bytes) | Variable | Type | Details |
|---|---|---|---|
| 0 - 3 | Velocity limit | float 32 | unit is encoder ticks/s |
| 4 - 7 | Current limit | float 32 | unit is mA |
Driver will not respond to this command!
Send_Kt
This command will set Kt of the motor driver.
- Command ID: 22
- Direction: Host -> driver
- Python API reference: Send_Kt()
- Type of frame: standard
- Length: 4 byte
| Size (bytes) | Variable | Type |
|---|---|---|
| 0 - 3 | Kt | float 32 |
Driver will not respond to this command!
Send_CAN_ID
This command will set a new CAN ID for your motor driver.
Note that ID you send is the new motor ID.
- Command ID: 11
- Direction: Host -> driver
- Python API reference: Send_CAN_ID()
- Type of frame: standard
- Length: 1 byte
| Size (bytes) | Variable | Type |
|---|---|---|
| 0 | ID | byte |
The ID must be 0 to 15 (only 4 bits go on the bus). It is kept until power-off unless you send Send_Save_config.
Driver will not respond to this command!
Send_ESTOP
This command will stop the motor and set ESTOP error to 1.
It is an empty data frame.
- Command ID: 0
- Direction: Host -> driver
- Python API reference: Send_ESTOP()
- Type of frame: standard
- Length: 0 byte
Driver will not respond to this command!
Send_Idle
This command will set the motor driver to idle state.
It is an empty data frame.
- Command ID: 12
- Direction: Host -> driver
- Python API reference: Send_Idle()
- Type of frame: standard
- Length: 0 byte
Driver will not respond to this command!
Send_Save_config
This command will save the current motor config to the EEPROM.
It is an empty data frame.
- Command ID: 13
- Direction: Host -> driver
- Python API reference: Send_Save_config()
- Type of frame: standard
- Length: 0 byte
Driver will not respond to this command!
Send_Reset
This command will reset the MCU of the motor driver.
It is an empty data frame.
- Command ID: 14
- Direction: Host -> driver
- Python API reference: Send_Reset()
- Type of frame: standard
- Length: 0 byte
Driver will not respond to this command!
Send_Clear_Error
This command will clear all active errors of the motor driver.
It is an empty data frame.
- Command ID: 1
- Direction: Host -> driver
- Python API reference: Send_Clear_Error()
- Type of frame: standard
- Length: 0 byte
Driver will not respond to this command!
Send_Watchdog
This command will set Watchdog parameters like watchdog time and action.
- Command ID: 15
- Direction: Host -> driver
- Python API reference: Send_Watchdog()
- Type of frame: standard
- Length: 5 byte
| Size (bytes) | Variable | Type | Details |
|---|---|---|---|
| 0 - 3 | watchdog_time_ms | int | |
| 4 | Action | int | 0 idle, 1 hold, 2 brake; stored, but this firmware does not act on it |
Send_Heartbeat_Setup
This command will set heartbeat parameters of the motor driver.
- Command ID: 30
- Direction: Host -> driver
- Python API reference: Send_Heartbeat_Setup()
- Type of frame: standard
- Length: 4 byte
| Size (bytes) | Variable | Type |
|---|---|---|
| 0 - 3 | Heartbeat_rate_ms | int |
Send_Cyclic_command
Not implemented
Command ID 29 is reserved. The firmware has no handler for it, and the Python library's Send_Cyclic_command() does nothing.
Send_Respond_Temperature
This command will request that motor driver responds with its current temperature. (Temperature of the thermistor).
Direction host -> driver is remote frame and direction driver -> host is standard data frame.
- Command ID: 23
- Direction: Host -> driver
- Python API reference: Send_Respond_Temperature()
- Type of frame: REMOTE
- Length: 0 byte
Driver respond to this command with:
- Command ID: 23
- Direction: driver -> Host
- Python API reference: Send_Respond_Temperature()
- Type of frame: standard
- Length: 2 byte
| Size (bytes) | Variable (Spectral_BLDC Lib python attribute) | Type | Details |
|---|---|---|---|
| 0 - 1 | temperature | 16 bit signed | unit of degrees |
Send_Respond_Voltage
This command will request that motor driver responds with its current supply voltage.
Direction host -> driver is remote frame and direction driver -> host is standard data frame.
- Command ID: 24
- Direction: Host -> driver
- Python API reference: Send_Respond_Voltage()
- Type of frame: REMOTE
- Length: 0 byte
Driver respond to this command with:
- Command ID: 24
- Direction: driver -> Host
- Python API reference: Send_Respond_Voltage()
- Type of frame: standard
- Length: 2 byte
| Size (bytes) | Variable (Spectral_BLDC Lib python attribute) | Type | Details |
|---|---|---|---|
| 0 - 1 | voltage | 16 bit unsigned | unit of mV |
Send_Respond_Device_Info
This command will request that motor driver responds with its version information saved in the EEPROM.
Direction host -> driver is remote frame and direction driver -> host is standard data frame.
- Command ID: 25
- Direction: Host -> driver
- Python API reference: Send_Respond_Device_Info()
- Type of frame: REMOTE
- Length: 0 byte
Driver respond to this command with:
- Command ID: 25
- Direction: driver -> Host
- Python API reference: Send_Respond_Device_Info()
- Type of frame: standard
- Length: 7 byte
| Size (bytes) | Variable (Spectral_BLDC Lib python attribute) | Type | Details |
|---|---|---|---|
| 0 | HARDWARE_VERSION | byte | hardware version of the driver |
| 1 | BATCH_DATE | byte | date when the batch was produced |
| 2 | SOFTWARE_VERSION | byte | version of the software on the driver |
| 3 - 6 | SERIAL_NUMBER | 32 bit | serial number of the driver |
Send_Respond_State_of_Errors
This command will request that motor driver responds with state of all possible errors.
Direction host -> driver is remote frame and direction driver -> host is standard data frame.
- Command ID: 26
- Direction: Host -> driver
- Python API reference: Send_Respond_State_of_Errors()
- Type of frame: REMOTE
- Length: 0 byte
Driver respond to this command with:
- Command ID: 26
- Direction: driver -> Host
- Python API reference: Send_Respond_State_of_Errors()
- Type of frame: standard
- Length: 2 byte
| Size (bytes) | Variable (Spectral_BLDC Lib python attribute) | Type | Details |
|---|---|---|---|
| 0 (bit 7) | error | bit (0/1) | General error |
| 0 (bit 6) | temperature_error | bit (0/1) | |
| 0 (bit 5) | encoder_error | bit (0/1) | |
| 0 (bit 4) | vbus_error | bit (0/1) | |
| 0 (bit 3) | driver_error | bit (0/1) | |
| 0 (bit 2) | velocity_error | bit (0/1) | |
| 0 (bit 1) | current_error | bit (0/1) | |
| 0 (bit 0) | estop_error | bit (0/1) | |
| 1 (bit 7) | calibrated | bit (0/1) | |
| 1 (bit 6) | activated | bit (0/1) | |
| 1 (bit 5) | watchdog_error | bit (0/1) |
Send_Respond_Iq_data
This command will request that motor driver responds with current Iq current data.
Direction host -> driver is remote frame and direction driver -> host is standard data frame.
- Command ID: 27
- Direction: Host -> driver
- Python API reference: Send_Respond_Iq_data()
- Type of frame: REMOTE
- Length: 0 byte
Driver respond to this command with:
- Command ID: 27
- Direction: driver -> Host
- Python API reference: Send_Respond_Iq_data()
- Type of frame: standard
- Length: 2 byte
| Size (bytes) | Variable (Spectral_BLDC Lib python attribute) | Type | Details |
|---|---|---|---|
| 0 - 1 | current | signed 16bit | unit is mA |
Send_Respond_Encoder_data
This command will request that motor driver responds with current encoder position and speed data.
Direction host -> driver is remote frame and direction driver -> host is standard data frame.
- Command ID: 28
- Direction: Host -> driver
- Python API reference: Send_Respond_Encoder_data()
- Type of frame: REMOTE
- Length: 0 byte
Driver respond to this command with:
- Command ID: 28
- Direction: driver -> Host
- Python API reference: Send_Respond_Encoder_data()
- Type of frame: standard
- Length: 8 byte
| Size (bytes) | Variable (Spectral_BLDC Lib python attribute) | Type | Details |
|---|---|---|---|
| 0 - 3 | position | signed 32bit | unit is encoder ticks |
| 4 - 7 | speed | signed 32bit | unit is encoder ticks/s |
Send_Respond_Ping
This command will request that motor driver responds with its own ping.
Direction host -> driver is remote frame and direction driver -> host is standard data frame.
- Command ID: 10
- Direction: Host -> driver
- Python API reference: Send_Respond_Ping()
- Type of frame: REMOTE
- Length: 0 byte
Driver respond to this command with:
- Command ID: 10
- Direction: driver -> Host
- Python API reference: Send_Respond_Ping()
- Type of frame: standard
- Length: 0 byte
More about CAN
Multi-byte values are big-endian: the most significant byte is in data[0] and goes on the bus first, the least significant byte last. For the 16-bit value 32814 (0x802E): data[0] = 0x80, data[1] = 0x2E. A 24-bit value uses three bytes the same way, a 32-bit value four.
Floats are IEEE 754 single precision (1 sign bit, 8 exponent bits, 23 fraction bits), big-endian, in 4 bytes.
Bits inside a byte are numbered from the most significant bit: bit 7 is the first flag the firmware packs, bit 0 the last (see the bitfield tables above).
Found a mistake on this page? Edit it on GitHub · Report it