Tested motors
The Spectral Micro drives three-phase brushless motors with a phase resistance of about 2 to 24 Ω: the calibration routine's default voltages are made for that range. The motors below have been run on it. Calibration measures each motor's resistance, inductance and pole pairs, so nothing has to be looked up before the first run.
| Motor | Kind | Where | |
|---|---|---|---|
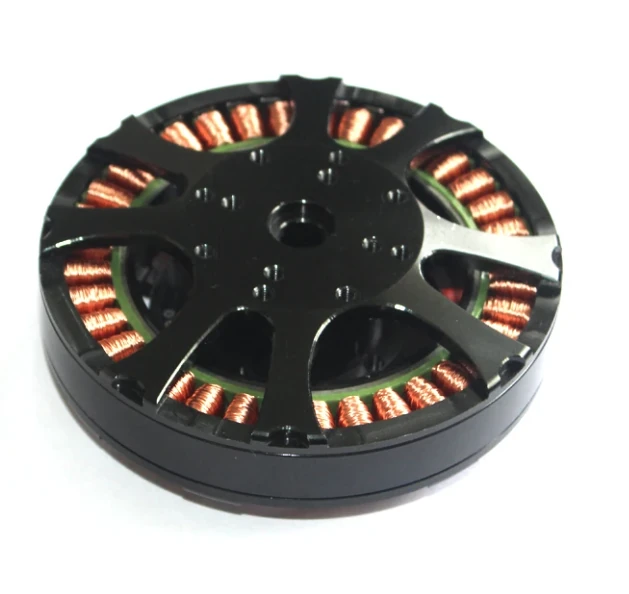 |
BGM8108 | gimbal motor, 8108 class | AliExpress |
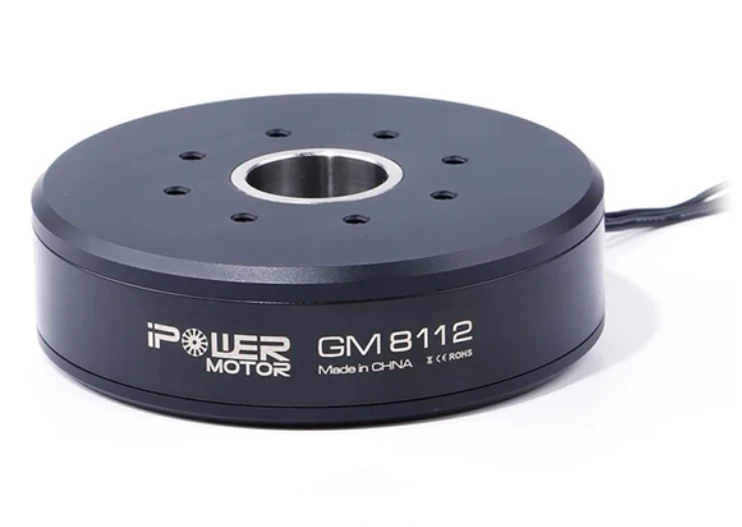 |
GM8112 | gimbal motor, 8112 class | AliExpress |
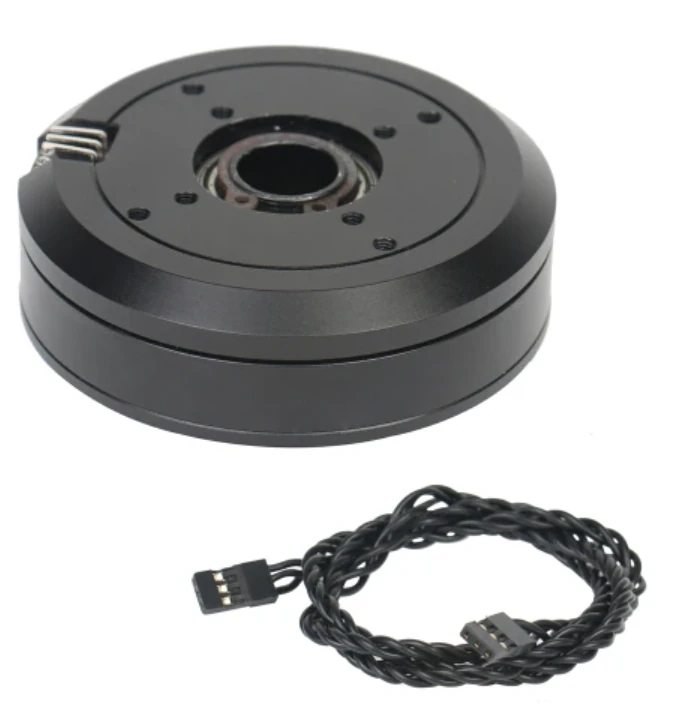 |
GM7008H | gimbal motor, 7008 class | AliExpress |
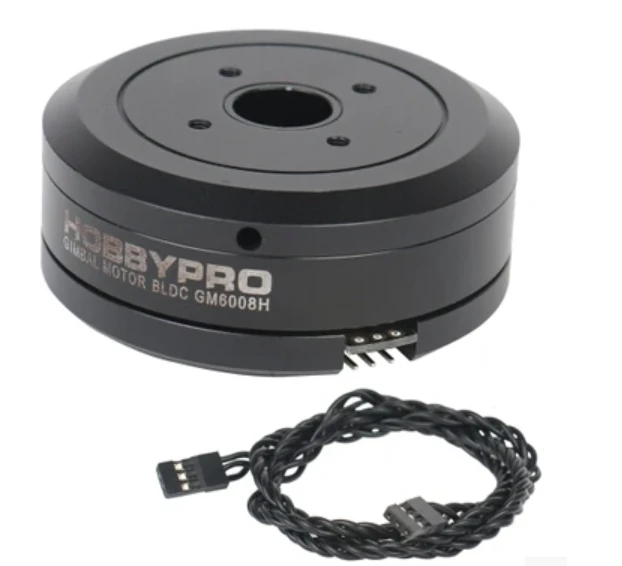 |
GM6008H | gimbal motor, 6008 class | AliExpress |
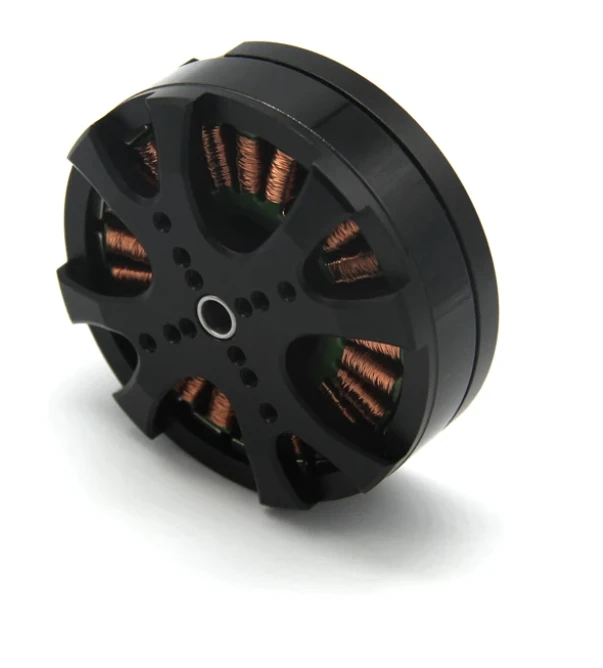 |
GBM5208 | gimbal motor, 5208 class | AliExpress |
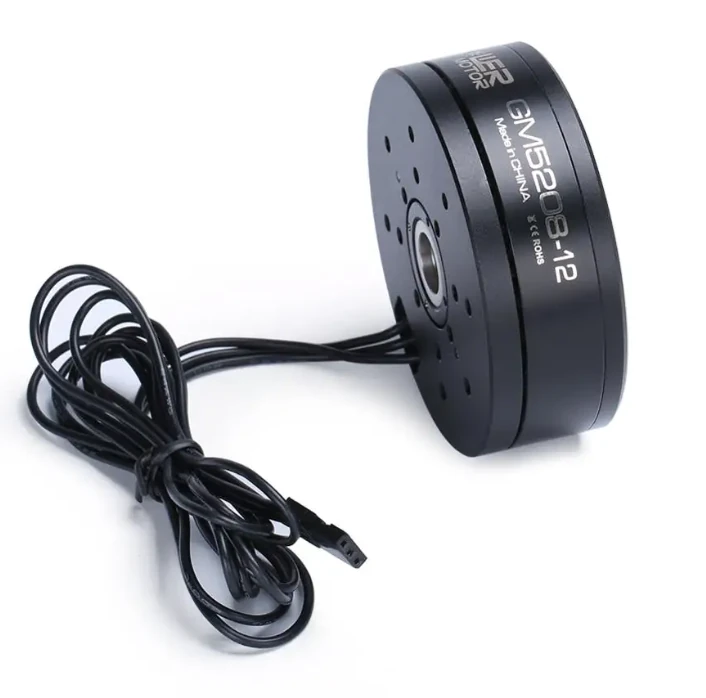 |
GM5208 | gimbal motor, 5208 class | AliExpress |
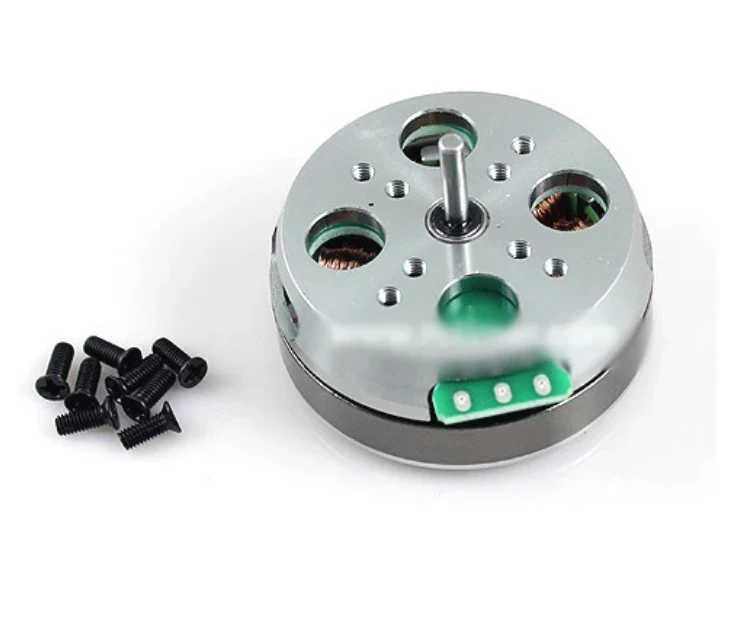 |
GBM5010 | gimbal motor, 5010 class | AliExpress |
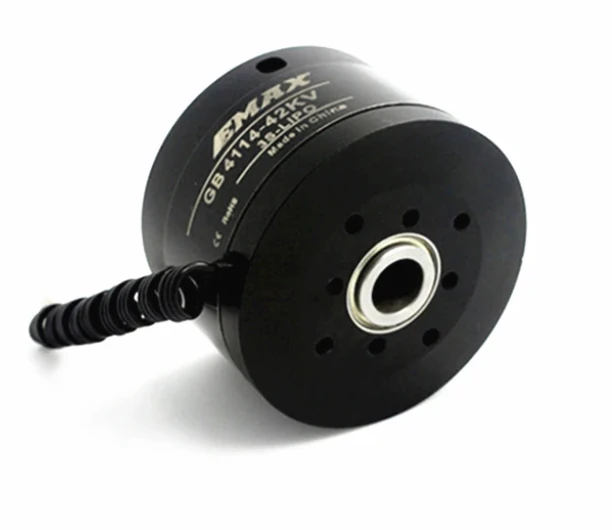 |
GB4114 | gimbal motor, 4114 class | AliExpress |
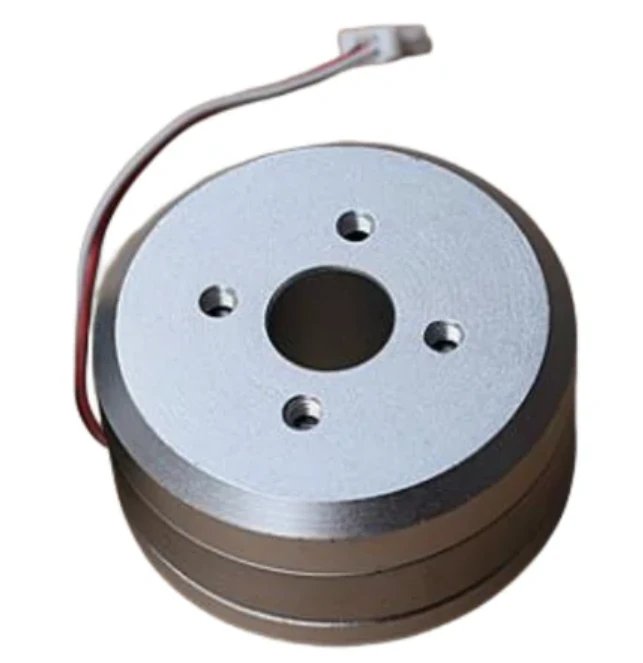 |
2804 | gimbal motor, 2804 class | AliExpress |
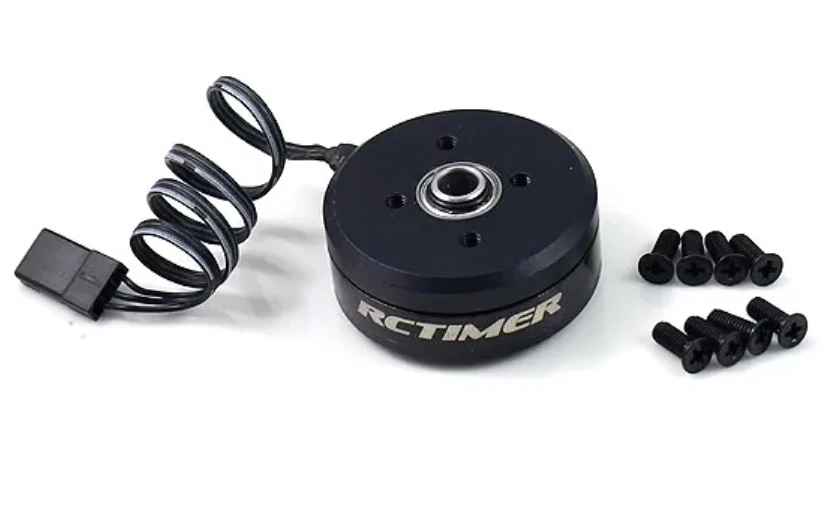 |
2804 (RCTimer) | gimbal motor, 2804 class | AliExpress |
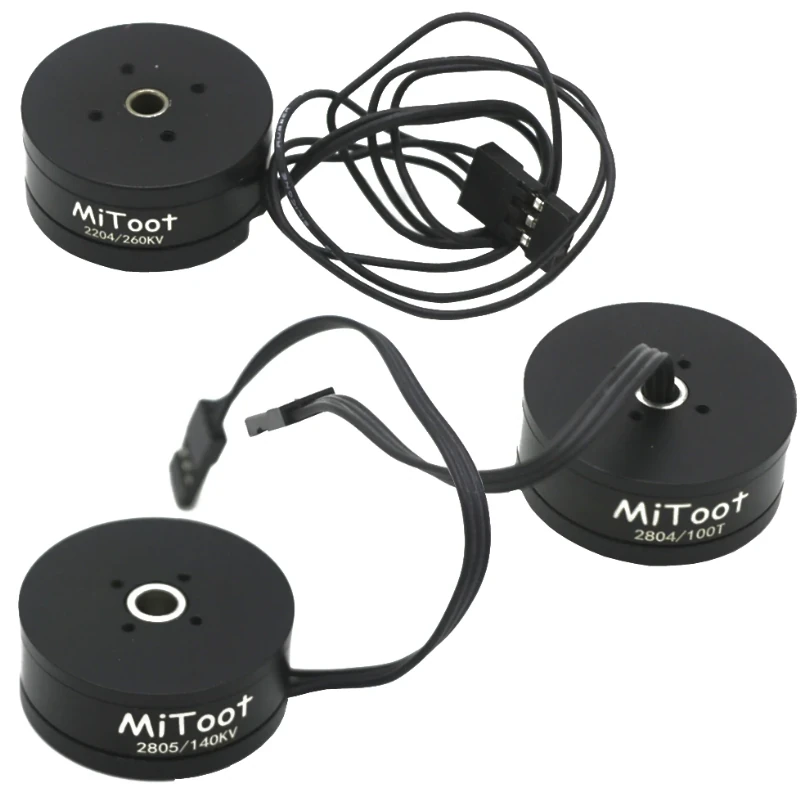 |
2804 100KV | gimbal motor, 2804 class, 100 KV | AliExpress |
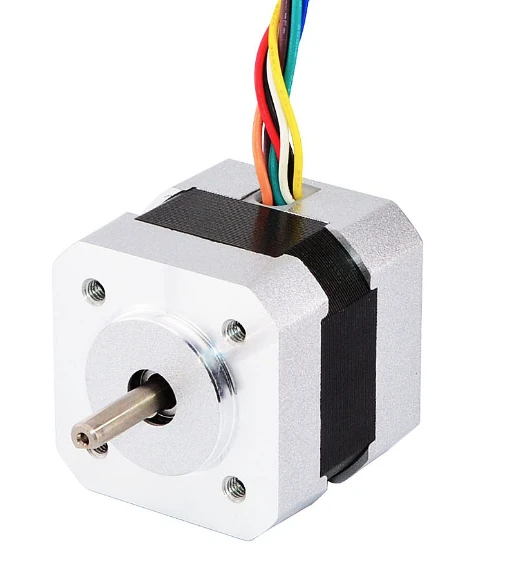 |
42BLS40-24-01 | NEMA 17-format brushless motor, 24 V, 26 W, 1.8 A, 219 g | Stepperonline |
Before the first test, set the current limit for the motor with #Ilim: calibration leaves it at 1600 mA. The
factory default of 1000 mA suits the gimbal motors above; a motor rated for more can go up to the driver's
2800 mA. See Current limit and loop tuning.
Choosing a motor
A lower phase resistance and inductance give a higher speed at a given supply voltage; the velocity constant
KV that calibration finds tells how fast the motor can turn: roughly 0.8 × Vbus × KV revolutions per minute.
A high pole-pair count (the large gimbal motors have 11 to 14) gives smooth torque at low speed and limits the
top speed through the driver's maximum electrical frequency. Motors with visibly uneven windings, a resistance
that differs between the phases or an uneven back-EMF calibrate badly and run rough.
Drone motors
Motors with a phase resistance well under 1 Ω draw a destructive current at the calibration routine's default voltages. The Spectral Micro is not made for them.
Comments
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF