Errors and LED states
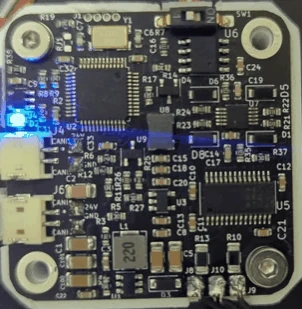
The LED
| Pattern | State |
|---|---|
| three short flashes, a pause | normal operation: calibrated, no error |
| fast flashing, about 10 times a second | calibration running |
| blinking for about 2 s after power-up | the bootloader waits for a host before it starts the firmware |
| on, steady | error mode, or not calibrated |
| off | no power, or #LED 0 |
| Normal operation | Calibration | Error mode |
|---|---|---|
 |
 |
 |
The error flags
The flags as the firmware keeps them, the line #Error prints for each, and where each sits in the two bytes of
Send_Respond_State_of_Errors (bits numbered from the most significant).
| Flag | #Error prints |
Byte, bit | Raised when |
|---|---|---|---|
Error |
In error state! |
0, 7 | any of the flags below is set (also the error bit of every CAN identifier) |
temperature_error |
Temp error |
0, 6 | the thermistor reads above #Tlim or below −20 °C (with #Term 1) |
encoder_error |
Encoder error |
0, 5 | the magnet is not detected or the reading fails its check |
Vbus_error |
Vbus error |
0, 4 | the supply is below 9 V or above #Vmax (29 V after #Default); from firmware 109 a low supply is not checked in the first 500 ms after power-up |
Driver_error |
Drv error |
0, 3 | the MOSFET driver reported a fault on its fault pin: undervoltage, thermal shutdown or overcurrent. #Error also prints FAULT pin is LOW: the gate driver reports a fault while the fault output is still active |
Velocity_error |
Velocity error |
0, 2 | the measured speed exceeds 20,000,000 ticks/s (about 1220 revolutions per second), a fixed limit: a runaway or an encoder fault, not #Vlimit |
Current_error |
Current error |
0, 1 | never in this firmware; reserved |
ESTOP_error |
Received ESTOP command |
0, 0 | Send_ESTOP was received, or from firmware 110 #Estop over UART |
Calibrated (0) |
Not calibrated |
1, 7 (1 = calibrated) | the motor has not been calibrated |
Activated |
— | 1, 6 | the activated flag, not an error |
Watchdog_error |
Watchdog error |
1, 5 | the watchdog time passed without a motion command or an answered request over CAN |
wrong_product |
Wrong firmware for this board (product lock) |
1, 4 | from firmware 109: the firmware found the other product's stamp, or a calibration its product cannot make, at start-up; it drives nothing |
Gripper mode has its own flags in Respond_Gripper_data_pack: a temperature error (the driver's temperature error), a timeout error (the driver's watchdog error: the CAN watchdog ran out) and an E-stop error; see the Gripper reference.
Clearing
#Clear and Send_Clear_Error clear every flag except Calibrated and go to idle; a flag whose cause persists is
set again at once. While any flag is set the driver disables the motor, which coasts whatever #Brake says. The watchdog, E-stop and velocity errors clear and stay clear; the Vbus, encoder, driver and
temperature errors come back until the cause is gone. Calibration clears the calibration error. A wrong product
stays until the right firmware is flashed. Clearing a watchdog error also ends a watchdog hold or descend.
Comments
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF