Current limit and loop tuning
Calibration leaves the driver with current loop gains computed for your motor and with conservative velocity and position gains. Two things remain: the current limit, which you must set for your motor, and the loop gains, which you tune if the defaults do not suit it.
Motor GUI shows the motor's response on its plots while you change a gain, which is what makes tuning quick.
The current limit
Set the current limit to the rated phase current of your motor in mA. Calibration uses its own 1600 mA for its steps and, from firmware 109, puts your limit back when it ends (107 and older left 1600 mA: set it again after calibrating there).
The factory default (#Default) of 1000 mA suits the gimbal motors in
Tested motors; a motor rated for more can go up to the driver's 2800 mA.
#Ilim clamps the limit to 2800 mA; from firmware 109 Send_Limits over CAN does too. The firmware does not trip on
phase current by itself; the MOSFET driver's hardware protection only catches a hard fault. A limit above the motor's
rating overheats the motor.
Crunching and whining sounds at speed usually mean the current limit, or the current loop gains, are too high.
The loops
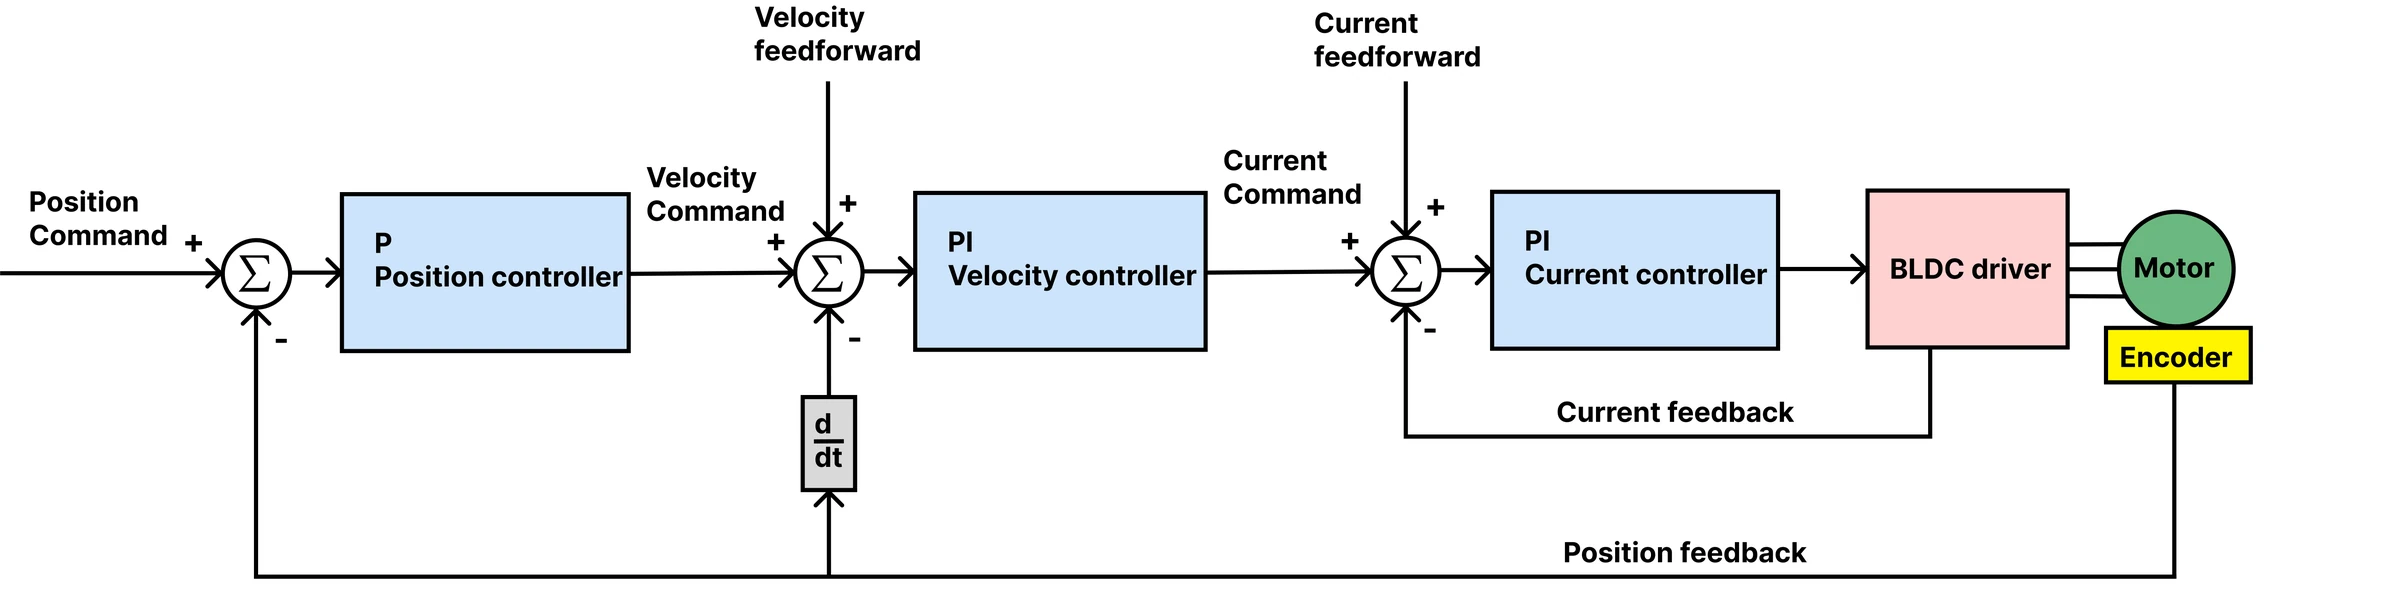
Tune from the inside out: the current loop first, then velocity, then position. Before you start:
- The motor must be calibrated and without active errors; the driver refuses the control modes otherwise.
- Fix the motor to the bench, nothing on the shaft. A loop that oscillates can shake a loose motor off the table.
- If the defaults oscillate, lower all gains until the motor is quiet, then raise them one at a time in small steps.
The gains are in the settings: change one, Apply gains, command a move with the jog controls and read the
response on the plots. Apply preset loads a starting set for a kind of motor: a product preset writes its
own current and velocity gains; the Generic motor presets set soft limits and velocity gains and leave the
current gains to #Cbw and the calibration. Apply a preset before you calibrate, so that the calibration
computes the current gains.
Save when you are done.
Each gain is a command: #Kpiq 0.5, #Kpv 0.02, …, then #Save. Command a move with #Iq, #V or #P
and judge the response by ear and by #Cyc 20, which streams position, speed and current.
The current loop
The current loop is a PI controller that turns a current request into a voltage.
Its gains Kpiq and Kiiq follow from the motor's resistance R, its inductance L (both measured by calibration) and
one number, the bandwidth: Kpiq ≈ ω·L and Kiiq = ω·R·T, with ω = 2π × the bandwidth and T the 200 µs control period
(Kiiq is applied once per control loop).
The PI then cancels the coil's own lag, and the current follows a request like a first-order filter at that bandwidth. Calibration computes them this way at 160 Hz, the default from firmware 109; so does setting the bandwidth:
The bandwidth can be 10 to 500 Hz (a tenth of the 5000 Hz control loop). A higher one follows a request and
rejects a disturbance faster, and is louder. Gains set by hand with #Kpiq and #Kiiq work too; parameter 49
then tells which bandwidth they amount to.
Drives calibrated with older firmware
Firmware 107 and older computed the gains for 500 Hz on the 5000 Hz loop, which is fast for that loop rate.
Their saved gains stay as they are after an update to 109: parameter 49 reads about 500 Hz until the drive is
calibrated again. Calibrate again after the update where the motor can turn freely. A calibration made with
107 or older stored the resistance about 10 % and the inductance about 45 % too low, so #Cbw on the old
values gives gains for a lower bandwidth than it names (on an SSG-48 apply its preset instead, which writes
the gains). 160 Hz is the default; on the gimbal-motor bench 300 Hz settled a speed step 3.6 times faster at the
same holding noise, and 500 Hz added half again the current noise. The SSG-48 preset sets 300 Hz. See
Upgrading from older firmware.
Test with a current setpoint of a few hundred mA (Jog current, or #Iq 300): the motor should push with a
steady, quiet torque. Keep the current well under the limit.
The velocity loop
- Raise
Kpvuntil the motor oscillates at a steady speed command, then back off 20 %. - Raise
Kivslowly until it oscillates, then back off a little.Kivis an integrator: too much makes the motor unstable, none leaves a steady-state error. - Test with a speed setpoint (Jog velocity, or
#V 20000; 16384 ticks per second is one revolution per second) and with different speeds.
The position loop
- Raise
Kppuntil the motor overshoots or oscillates when it reaches a target, then back off. - Test with a position step (Jog position, or
#P 16384and#P 0): one revolution and back. The response should be quick, without overshoot; the plot shows both.
Testing
Run the motor over the whole range of speeds and loads it will see, with a load if you can, and adjust. Then save.
The speed estimate
The velocity loop needs the speed, which the driver estimates from the encoder count. From firmware 109 parameter 50 picks how:
| Parameter 50 | Estimate | How it behaves |
|---|---|---|
| 0 | moving average of the last 20 count differences | about 2 ms late, in steps of 250 ticks/s: the estimate of every release before |
| 1 | PLL, the speed is its integrator | smooth, a little late |
| 2 (default) | direct PLL, integrator plus the proportional term | almost no lag, a little more noise |
Both PLLs are critically damped at the natural frequency of parameter 51, 100 Hz by default (10 to 250 Hz). The lag of the moving average is what limits the velocity gain.
On the gimbal-motor bench the direct PLL at 100 Hz allowed twice the Kpv of the moving average before the motor
vibrated (0.11 against 0.056), lowered the speed ripple 1.3 to 3.4 times between 1500 and 48000 ticks/s, and cut the
overshoot of a speed step from about 67 % to 12 % at the same gains.
At 60 Hz it overshot more, at 200 Hz it held with more current noise. Calibration and the gripper's stop detection always use the moving average. Neither parameter is kept by Save. The speed in Respond_data_pack_1 and Send_Respond_Encoder_data, the watchdog descend and the capture is the picked estimate.
Commutation delay compensation
The voltage a control loop sets reaches the motor later than the angle it was computed from was read: the rest of the loop, the wait for the PWM update and half a control period.
By then the rotor has turned on, and the voltage lands a little behind the angle it was meant for. Parameter 64 turns the output voltage forward by the angle the rotor covers in that delay, in the closed-loop modes above 100 ticks/s; 1 to 500 µs are accepted.
The default is 234 µs, the Spectral Micro's own delay measured on the bench: 20 points between 24000 and 120000 ticks/s gave one delay within 2 to 4 % of theory at every speed.
Without it the field lags about 6° electrical at 120000 ticks/s. The delay belongs to the driver's timing, not to the motor, so it suits any motor; 0 switches it off. It is not kept by Save.
The finer points of the velocity loop
Two settings for special cases, both off by default and not kept by Save; both were tested on the STEPFOC bench:
- Position input filter, parameter 74 (Hz, 0 to 200). A host that sends positions at a fixed rate sends a staircase; without the speed the steps are all the loops see. The filter turns the staircase into a smooth path and makes its own speed from it, in position and PD modes. Use it only for a host that sends positions without the speed feedforward, at about the host's rate ÷ 12 (8 Hz for 100 Hz); with a host that sends the speed it makes the tracking worse.
- Velocity-integral deadband, parameter 75 (ticks, 0 to 2000). In position mode the velocity integral sees the position error less this band, so a holding motor stops pushing against a small error it cannot correct. It trades accuracy for holding current.
Impedance (PD) mode
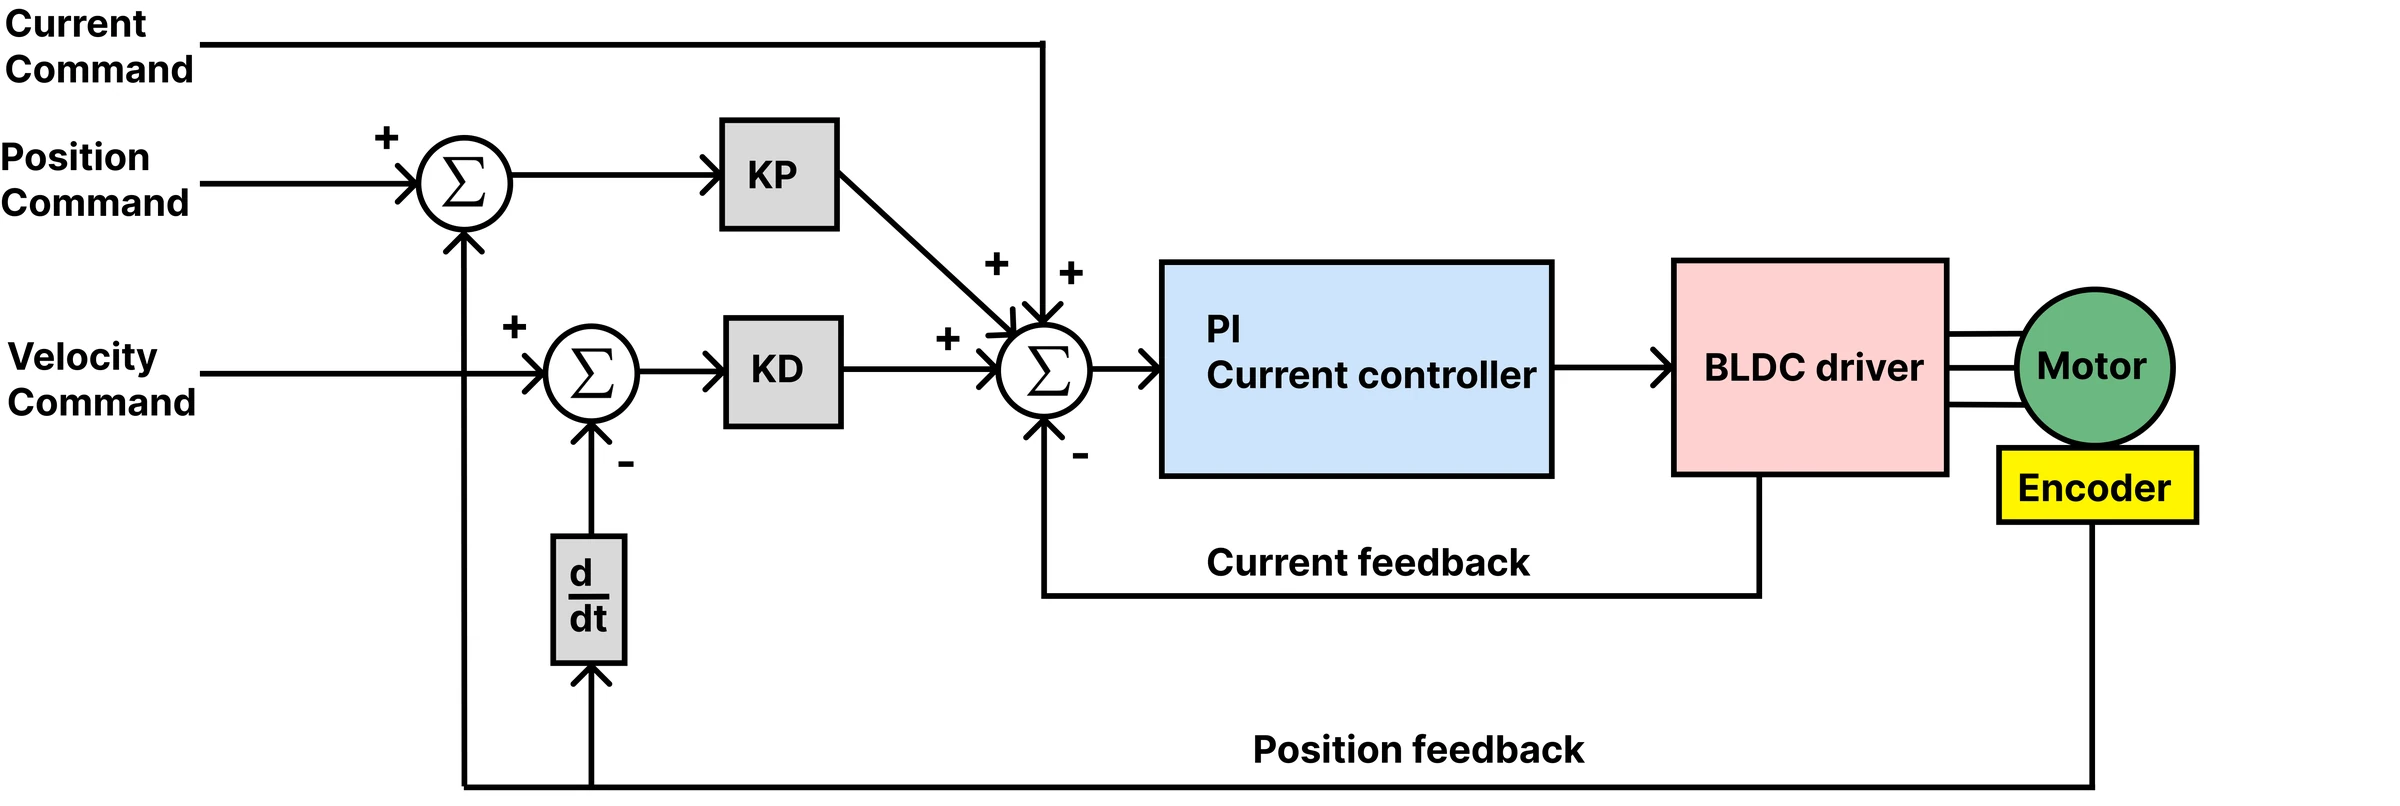
In PD mode the motor behaves like a spring and a damper: the torque is KP × (setpoint − position) + KD × (speed
setpoint − speed) + feedforward current.
Set KP and KD (the gains, or #KP, #KD, or Send_PD_Gains), then command with #PD, #PDV and #PDI or
Send_data_pack_PD. Start with a small KP and KD of 0, raise KP until the motor holds position firmly, then add
KD until it stops ringing. The theory corner explains the loop.
Limits
- The velocity limit (
#Vlimit) clamps the speed the loops may command, in encoder ticks per second. A rough maximum for your motor is 0.8 × Vbus × KV × 16384 / 60 ticks per second, with KV from calibration. - The voltage limit (
#Vlim) clamps the voltage of the current loops in mV; 0 uses the supply voltage. #Rstint 1resets the integrators on every new setpoint, which avoids windup when a program sends one setpoint after another with large steps.
Comments
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF