Jaws
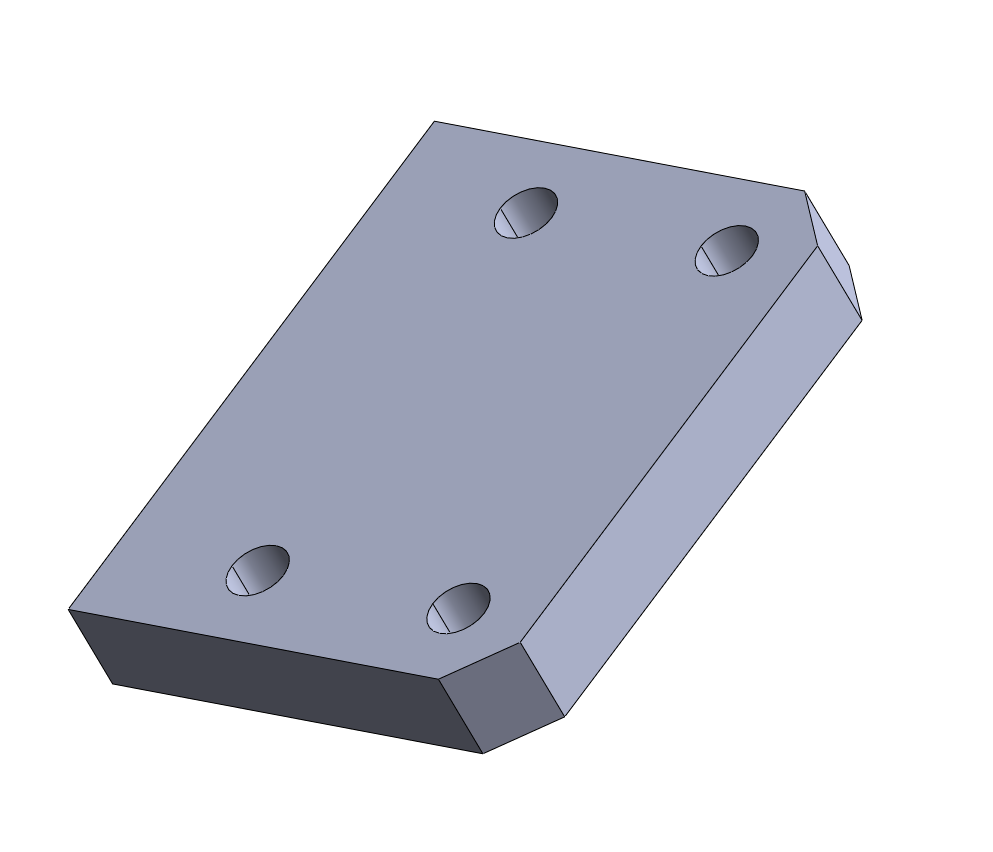
The gripper's two jaw plates carry a four-hole pattern for fingers. The product repository has fingers to print and a template for your own.
| Fingers | Files | Use |
|---|---|---|
| Fin-ray fingers | fin_ray_1, fin_ray_3, Finger_1 and Jaw_plate_fin_ray in gripper jaws |
fingers that wrap around round and irregular objects; printed in a flexible filament |
| Pinch jaws | solid_jaws_pinch and solid_jaws_pinch_foam in STEPS |
solid jaws for small and flat objects, with or without a foam pad |
| Your own | Jaw_plate.STEP, the template |
keep the hole pattern, shape the rest |
Limits
- Fingers at most 80 mm tall and 60 mm wide: longer fingers multiply the lever arm on the jaw plates and the rail, and foul the body at full opening.
- The grip force is set at the finger faces. A finger that bends takes some of it.
Custom fingers on a PAR6
On a PAR6, custom fingers must keep the size of the original fingers: no longer, no wider and no thicker. The PAR6 software works with the gripper's original dimensions (its collision model of the tool and the tool centre point), so a larger finger reaches where the robot does not expect it.
Calibrate after changing the fingers
The gripper calibration finds the end stops with the fingers fitted; fingers that meet earlier or later than the old ones change where 255 is. Calibrate again after a change, which happens at the next power-up anyway.
Comments
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF