Skip to content

Dimensions and CAD

Drag to turn the gripper, scroll to zoom, open and close the jaws, try the fingers and the colours. The model is the gripper's URDF, the fingers its printed options; the current URDF and MuJoCo models are linked from the repository's ssg48_description guide. The shop sells the body in black and grey.
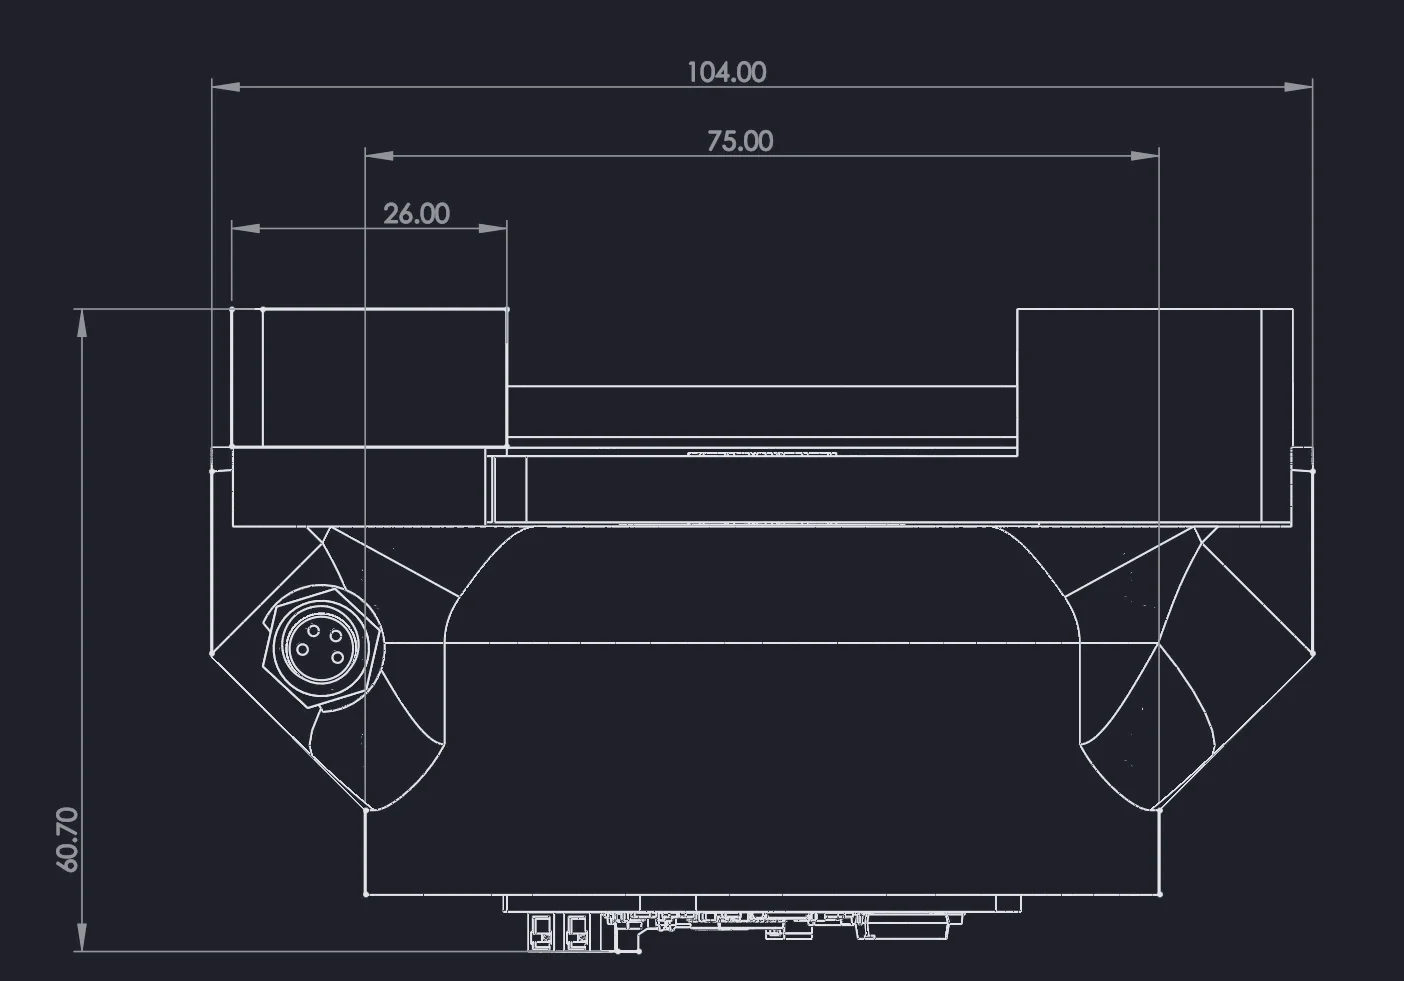
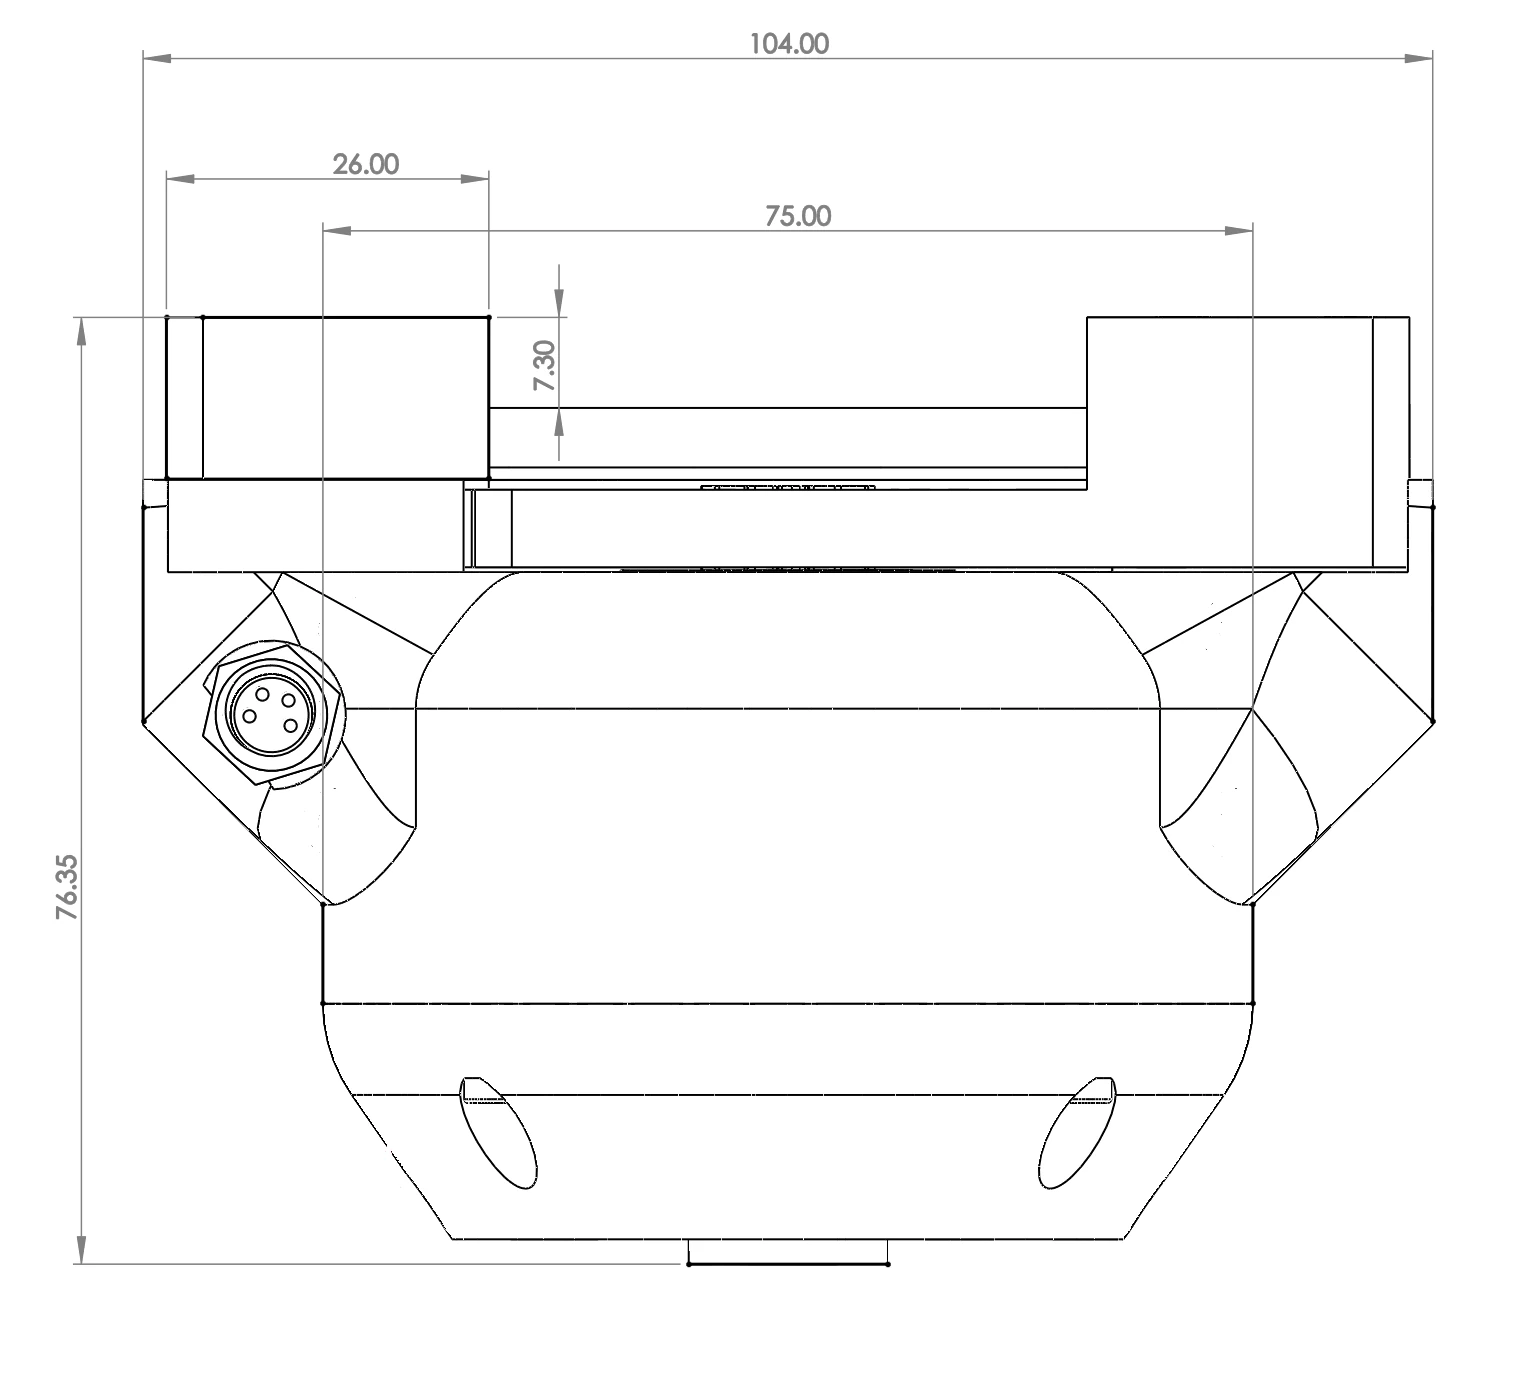
Front view, in millimetres, without a coupler connector: 104 mm over the jaw plates, 75 mm across the body, 26 mm jaw plates, 60.7 mm from the top of the jaw plates to the bottom of the driver board Front view, in millimetres, without a coupler connector: 104 mm over the jaw plates, 75 mm across the body, 26 mm jaw plates, 60.7 mm from the top of the jaw plates to the bottom of the driver board
Figure 3.4: Front view, in millimetres, without a coupler connector: 104 mm over the jaw plates, 75 mm across the body, 26 mm jaw plates, 60.7 mm from the top of the jaw plates to the bottom of the driver board.
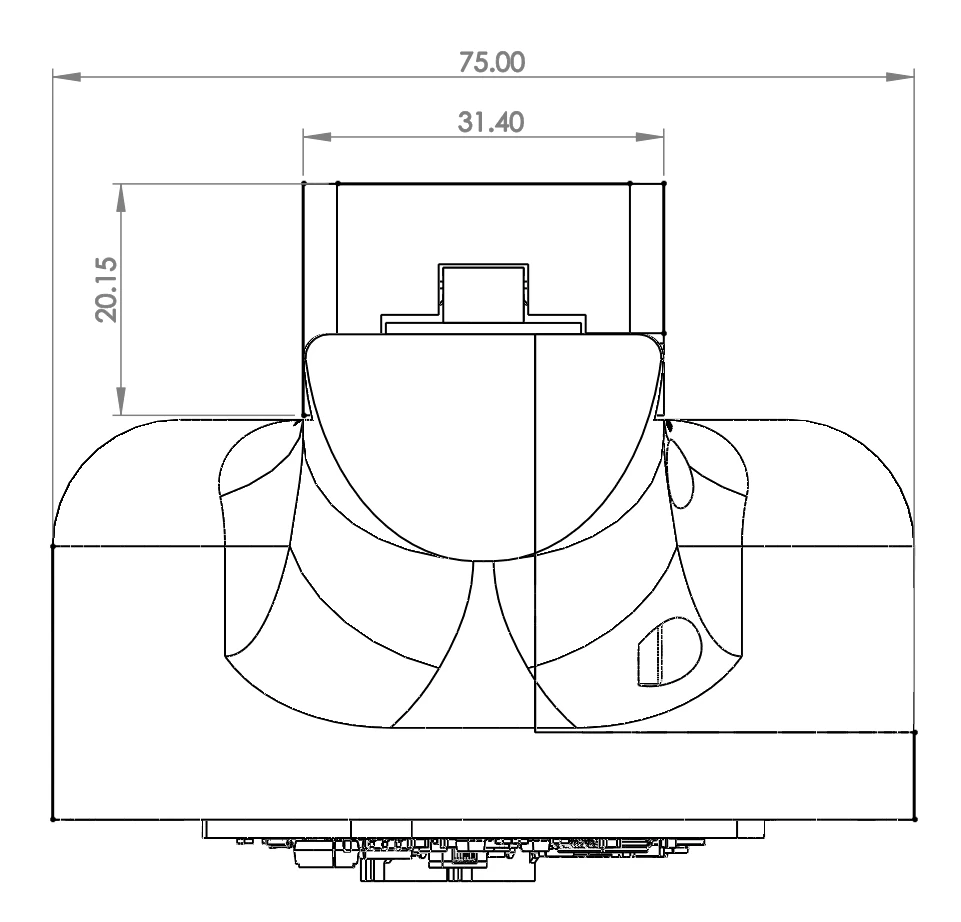
Side view, across the jaw travel: 75 mm across the body, 31.4 mm jaw plates Side view, across the jaw travel: 75 mm across the body, 31.4 mm jaw plates
Figure 3.5: Side view, across the jaw travel: 75 mm across the body, 31.4 mm jaw plates.
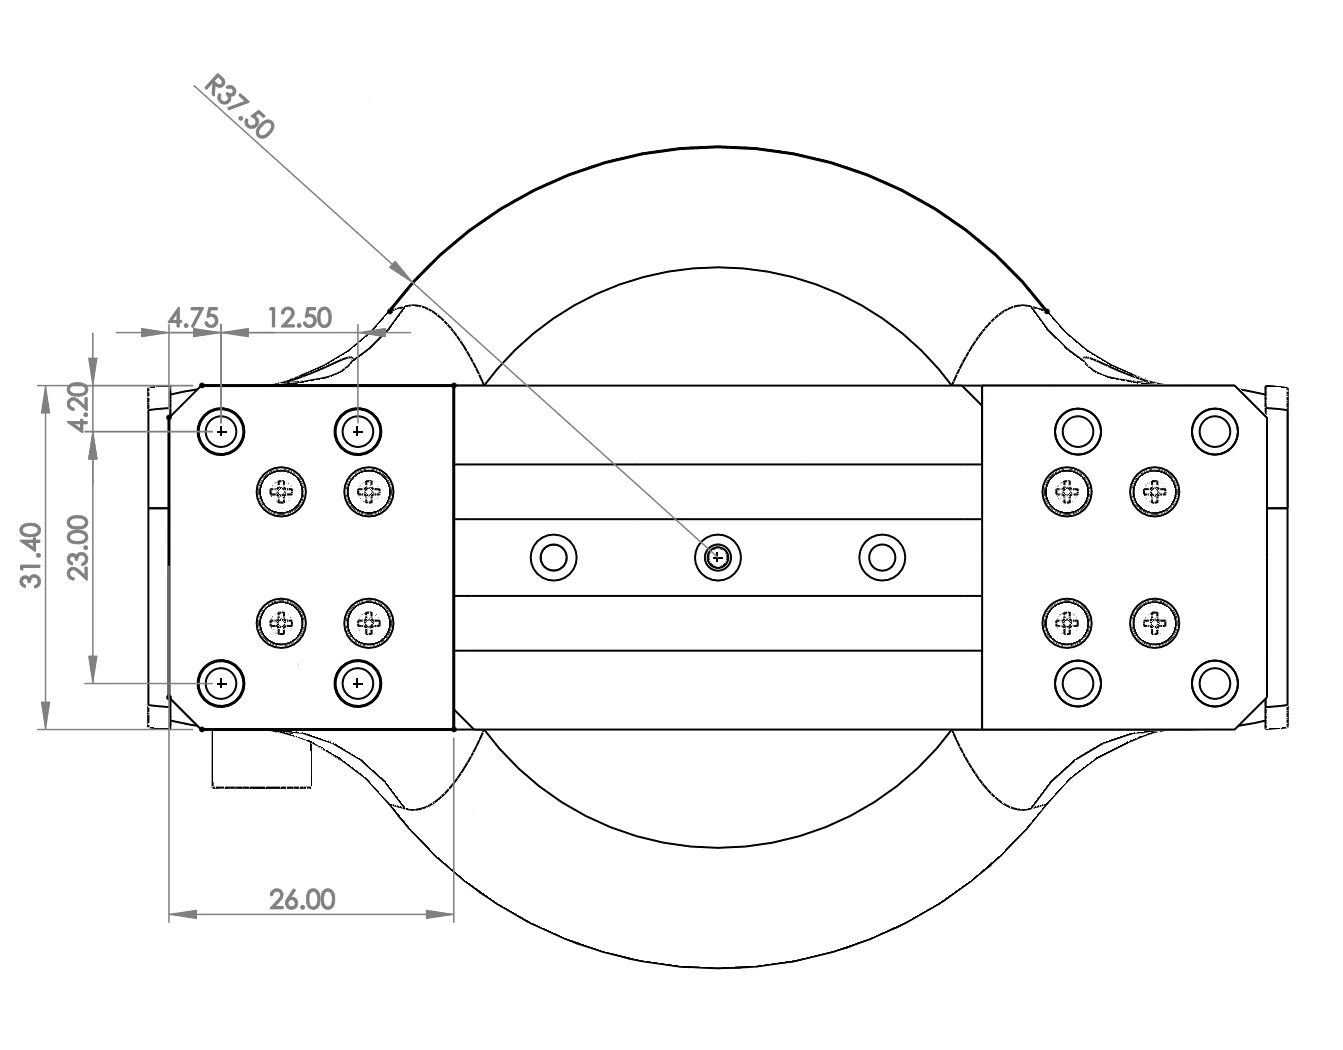
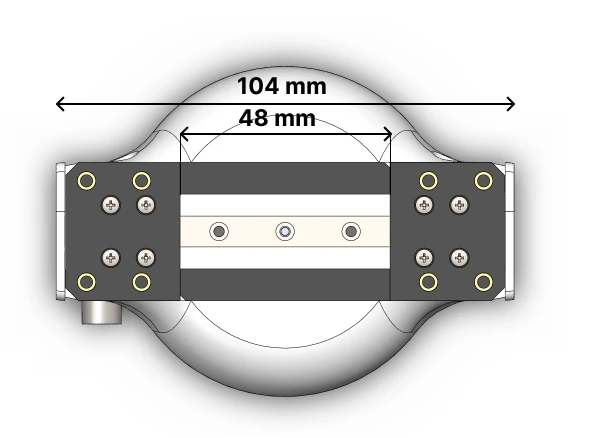
Top view, with the jaw plates and their hole pattern Top view, with the jaw plates and their hole pattern
Figure 3.6: Top view, with the jaw plates and their hole pattern.
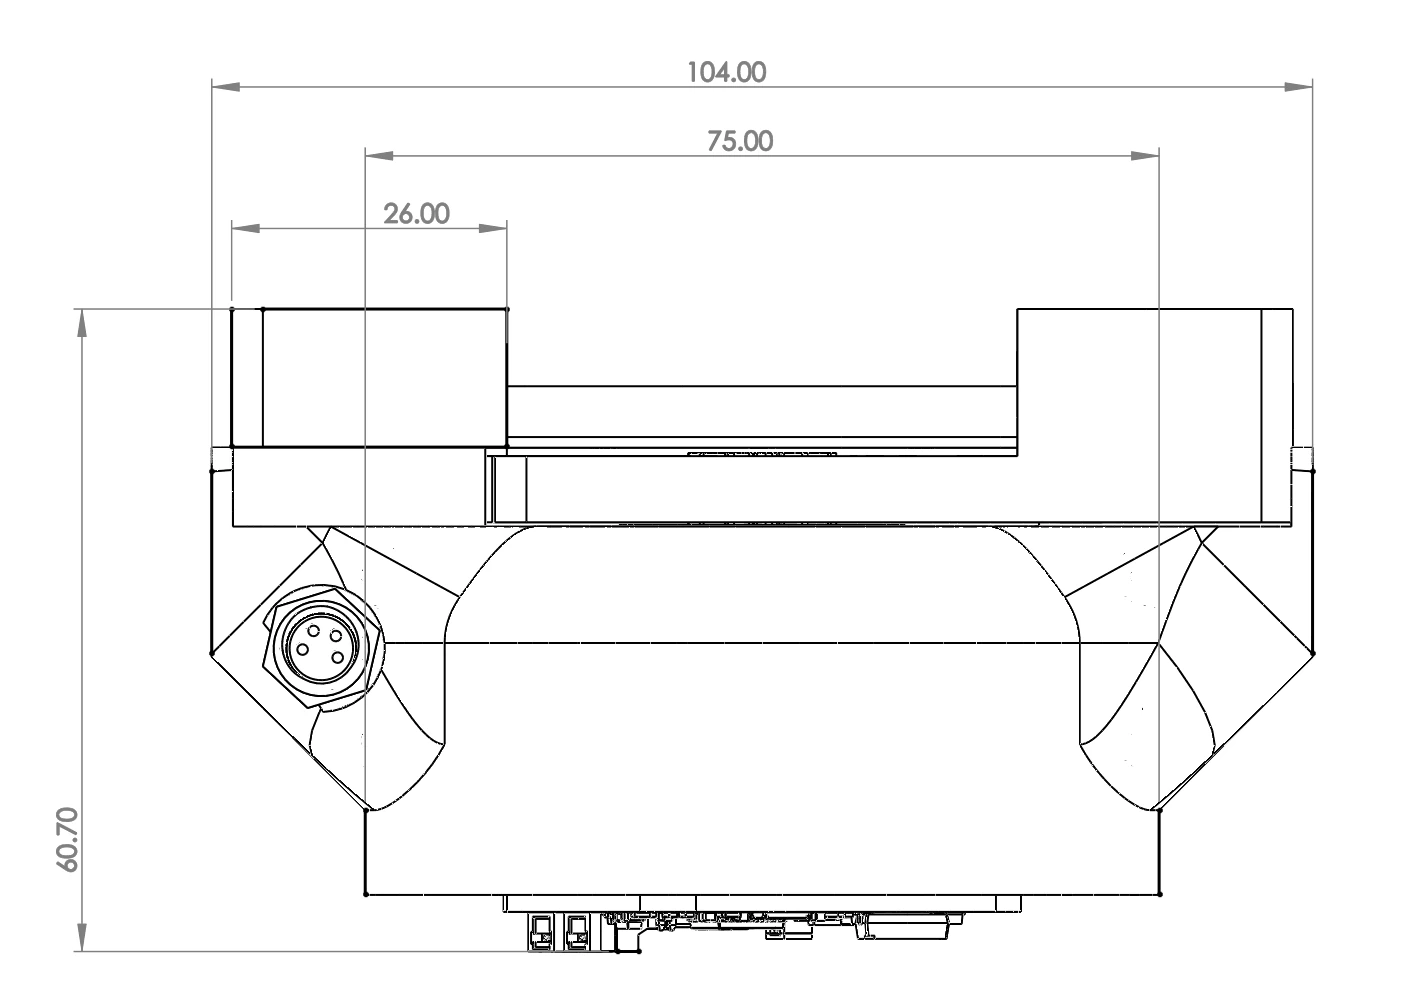
The gripper with the PAROL6 coupler connector: 76.35 mm from the top of the jaw plates to the end of the coupler The gripper with the PAROL6 coupler connector: 76.35 mm from the top of the jaw plates to the end of the coupler
Figure 3.7: The gripper with the PAROL6 coupler connector: 76.35 mm from the top of the jaw plates to the end of the coupler.
48 mm of stroke between the jaw plates, 104 mm overall
Figure 3.8: 48 mm of stroke between the jaw plates, 104 mm overall.

CAD

The STEP files of every part are in the product repository, the reference for anything that has to fit:

  • STEPS: the body parts (Gripper STEP files), the whole gripper (3D MODEL), the jaw plate template, the pinch jaws, the generic coupler connector template and the UR5 adapter plate.
  • Gripper STL parts: the printable parts of both hardware versions and the coupler connectors for PAROL6 and PAR6.
  • gripper jaws: the fin-ray fingers and their jaw plate.
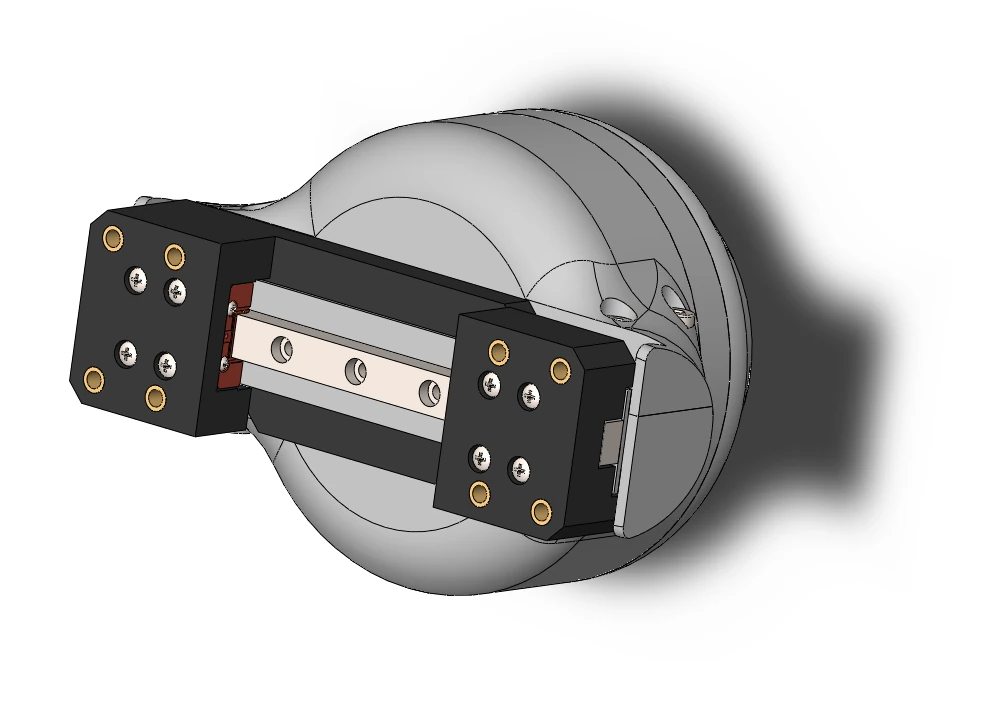
The STEP model of the gripper
Figure 3.9: The STEP model of the gripper.

For simulation

The product repository's ssg48_description guide links the gripper's models, which are kept in robot_descriptions: standalone URDF and MJCF (MuJoCo) packages of the gripper with solid or fin-ray jaws, with their meshes, collision shapes and mass properties, and the PAROL6 and PAR6 models with the gripper mounted.

CAD and downloads lists everything that can be downloaded.

Comments


Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF