Dimensions and kinematics
Drag to turn the robot, scroll to zoom, move each joint with its slider, choose the gripper on the flange, try a colour for the printed parts (the motors stay black). The model is the robot's URDF; the sliders run over its joint limits.
Dimensions
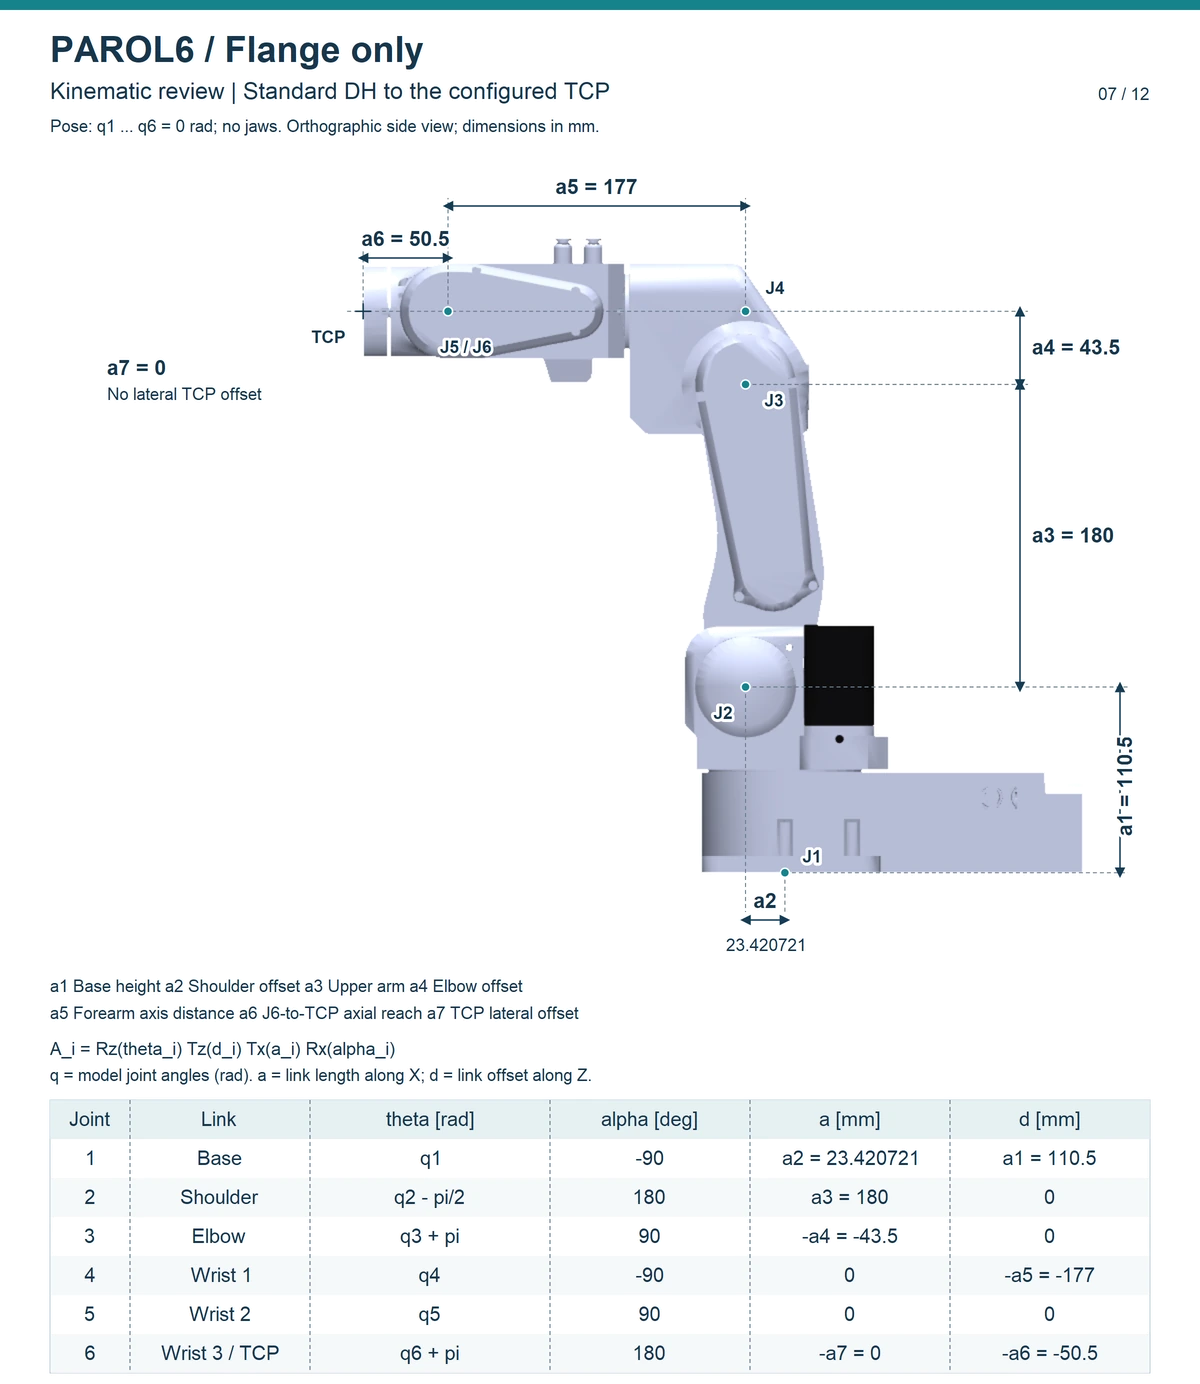
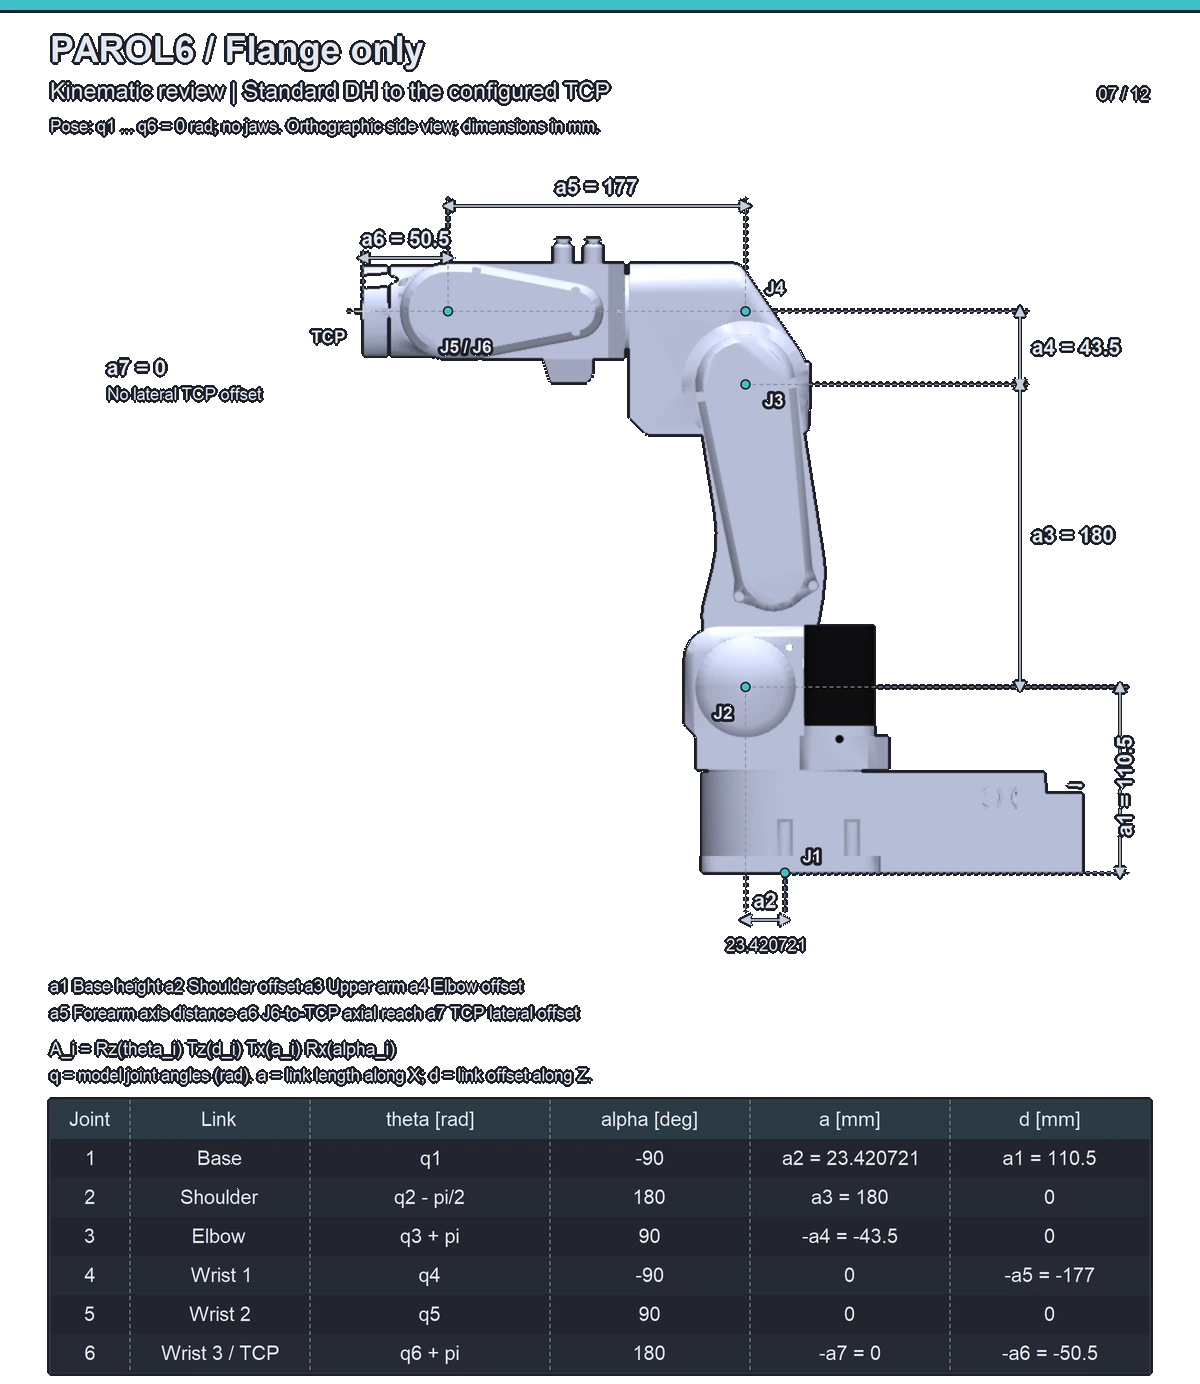
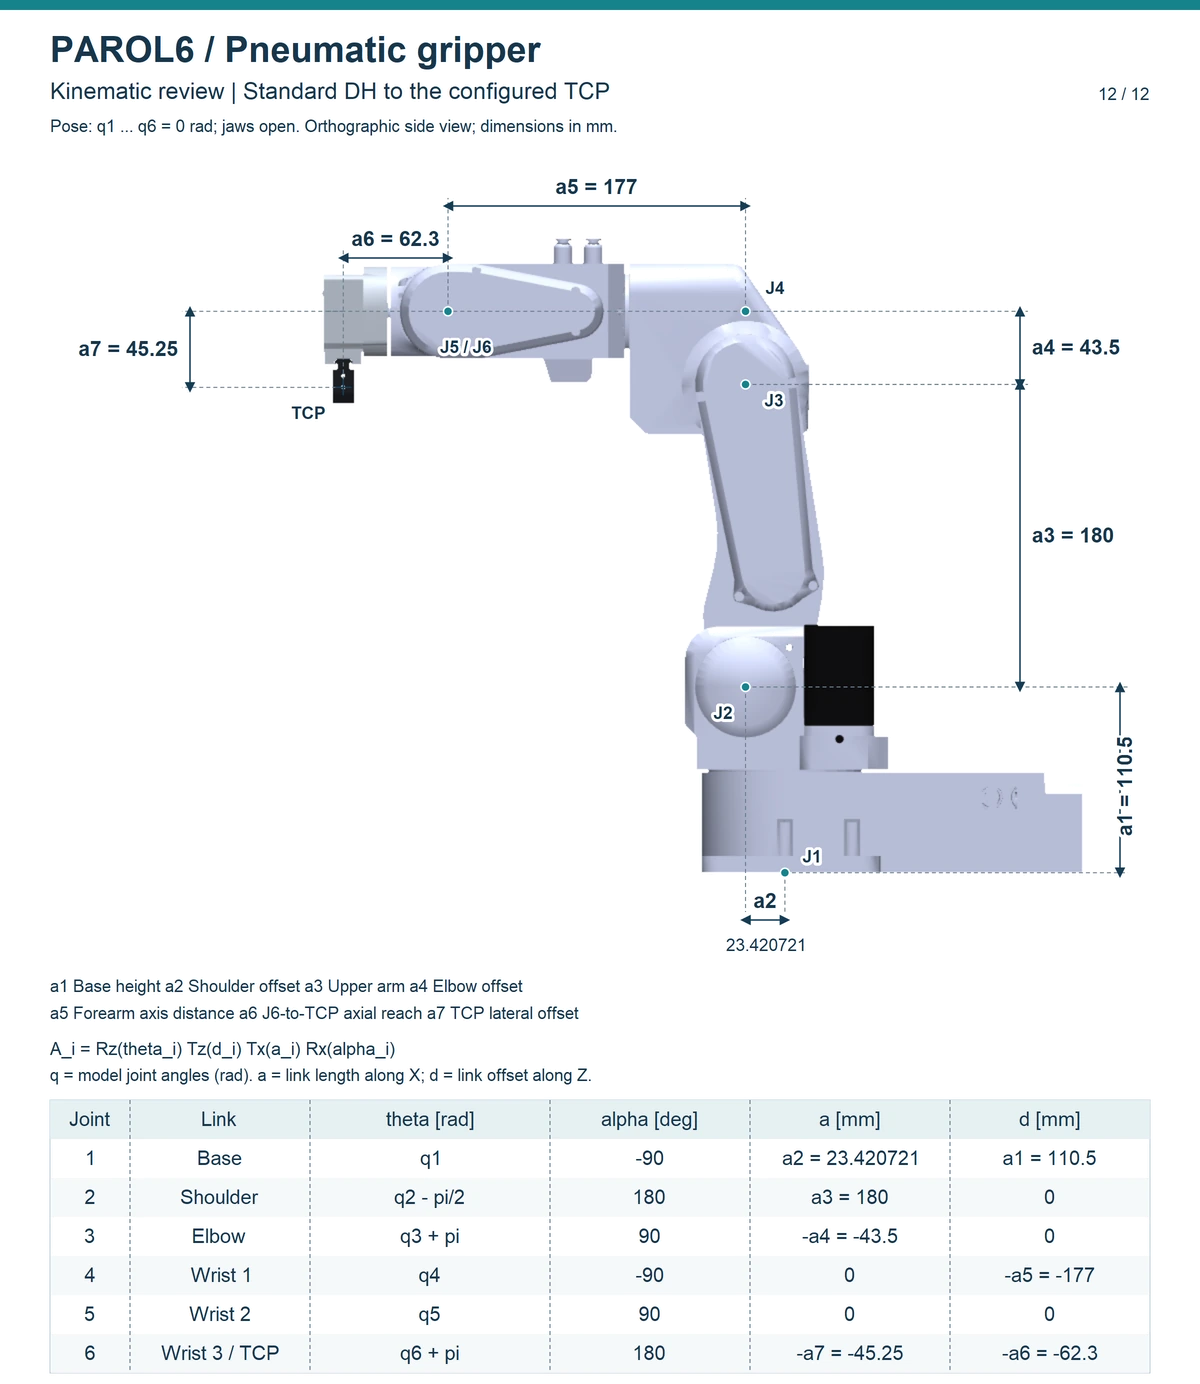
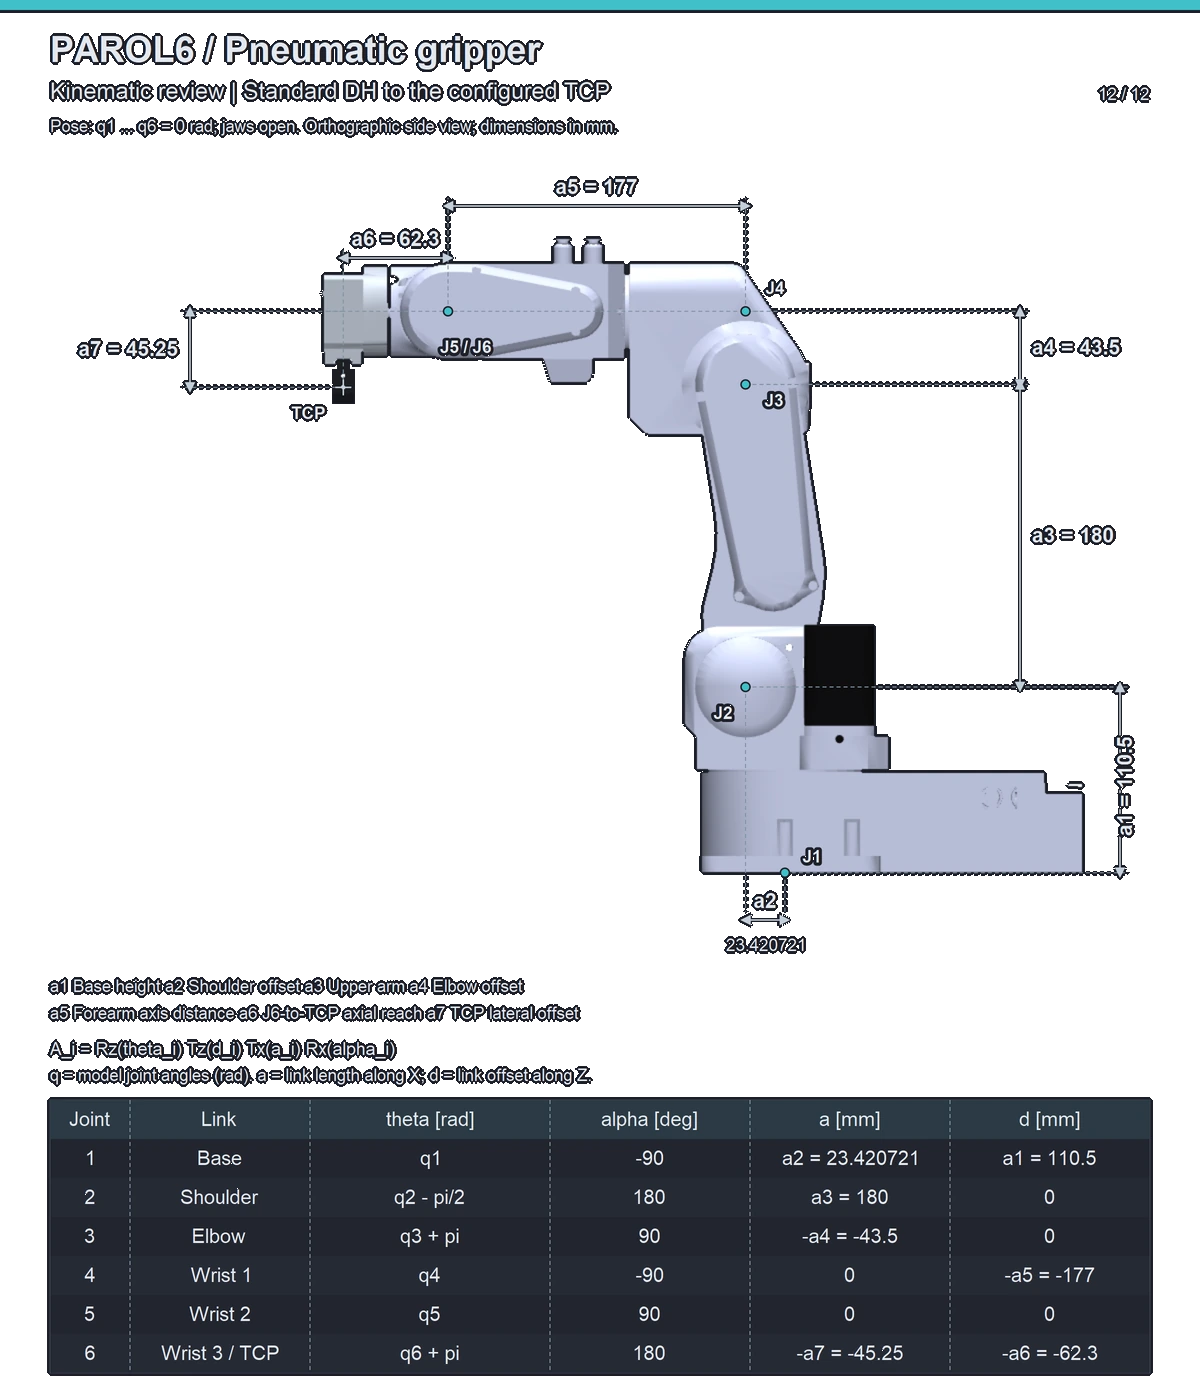
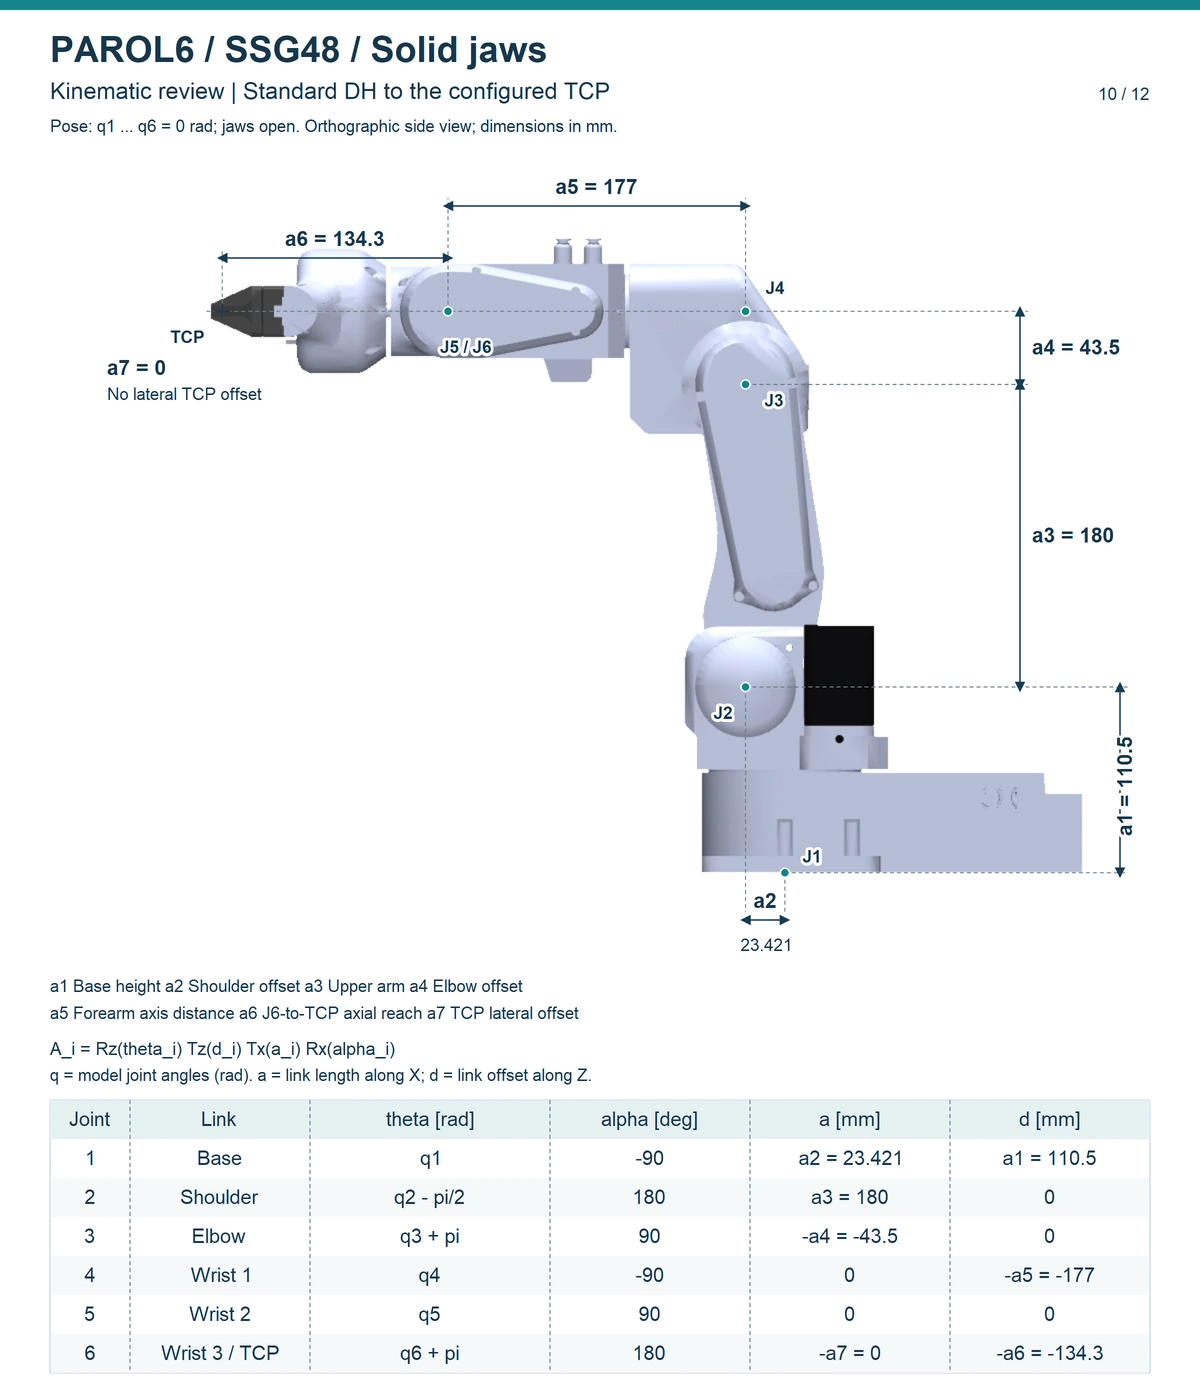
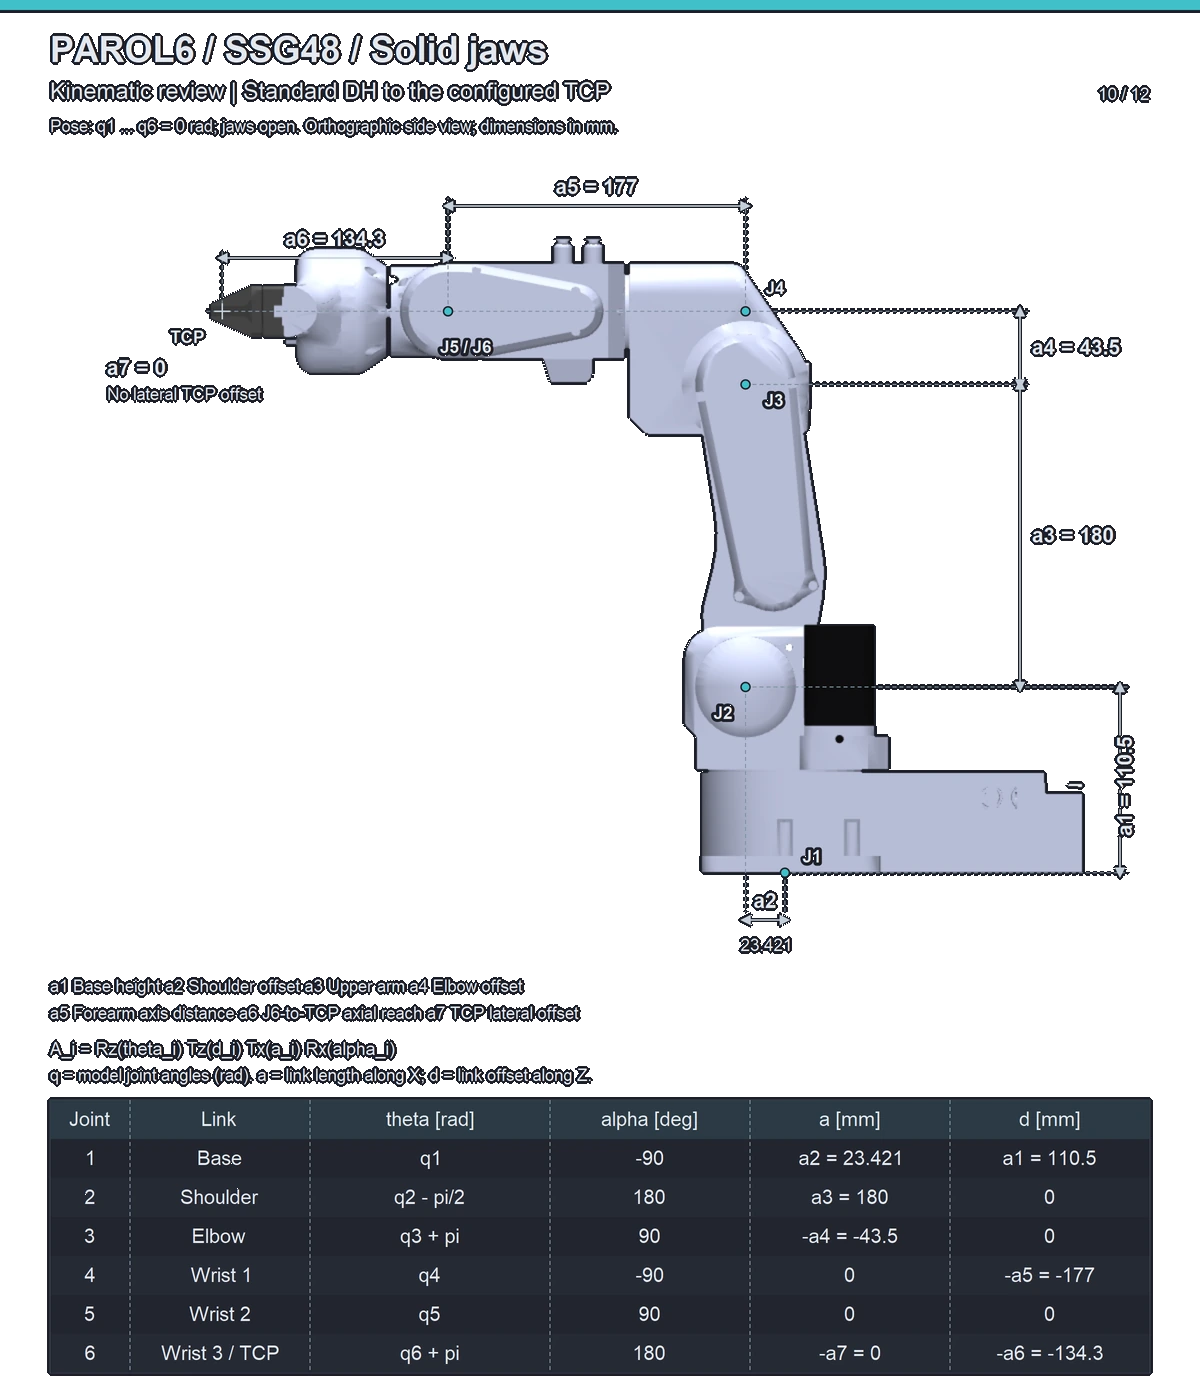
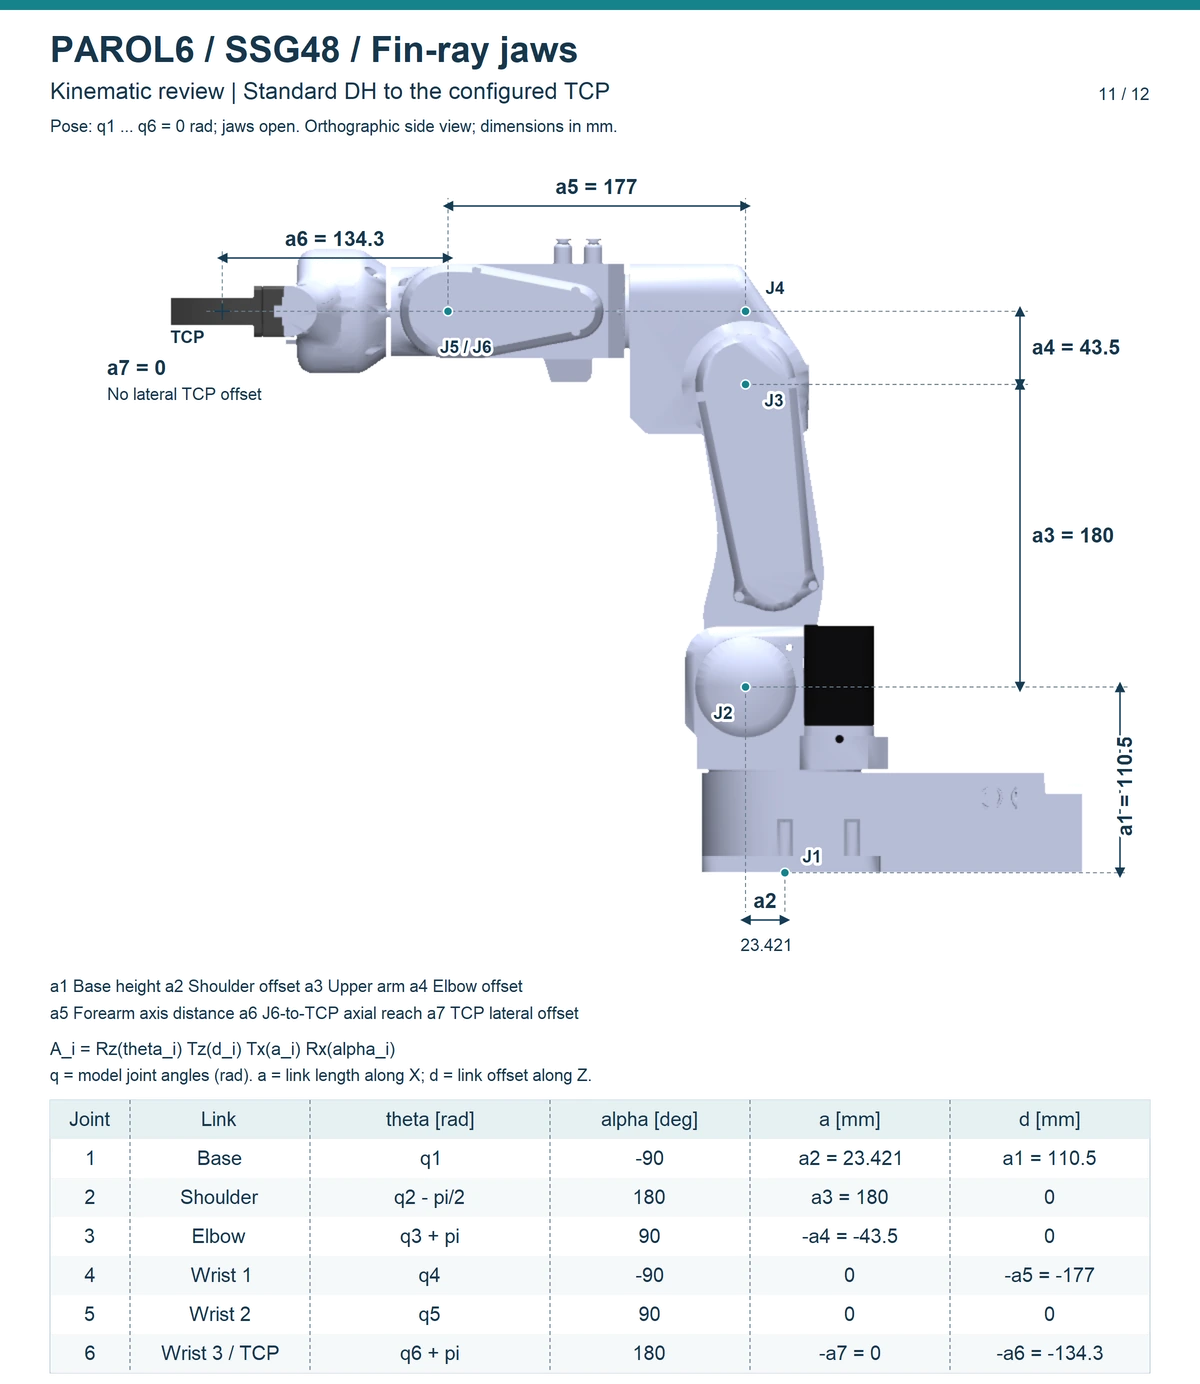
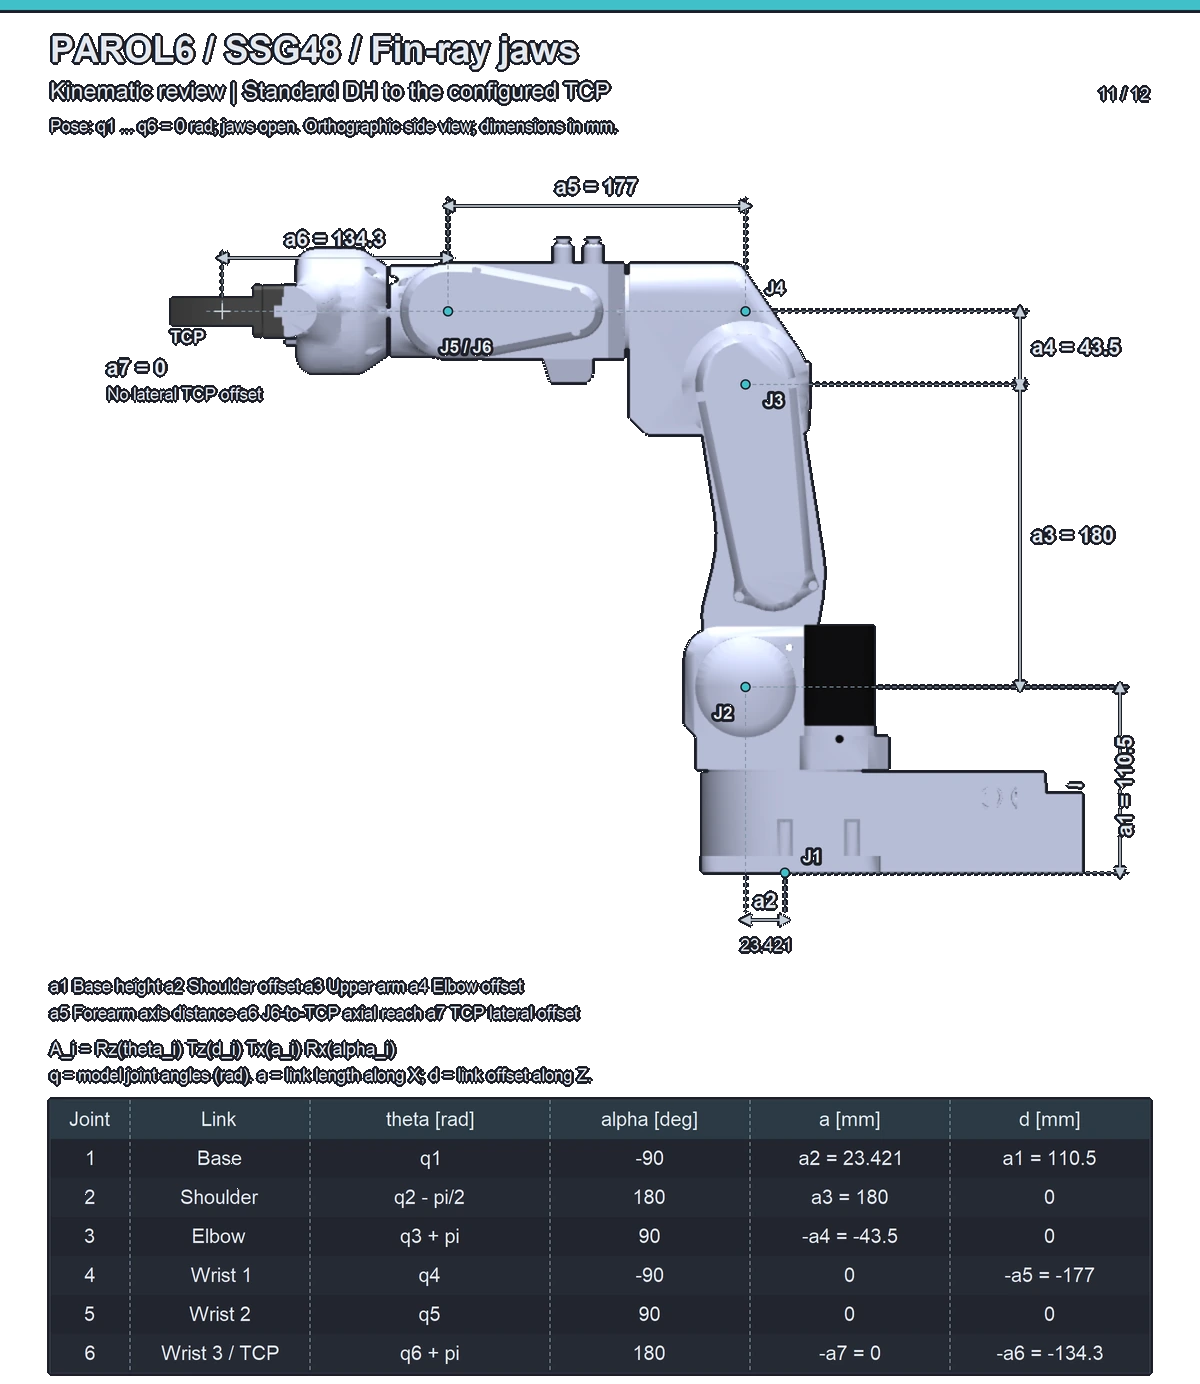
The sheets below come from PAROL6's models in robot_descriptions (version 2.15.1). Each shows the robot's own meshes in the standby pose (every joint of the model at 0), in one orthographic side view at one scale, with the dimensions taken from the URDF, not measured from the picture, and the standard DH table to the tool centre point (TCP) of that configuration. Click a sheet to enlarge it.
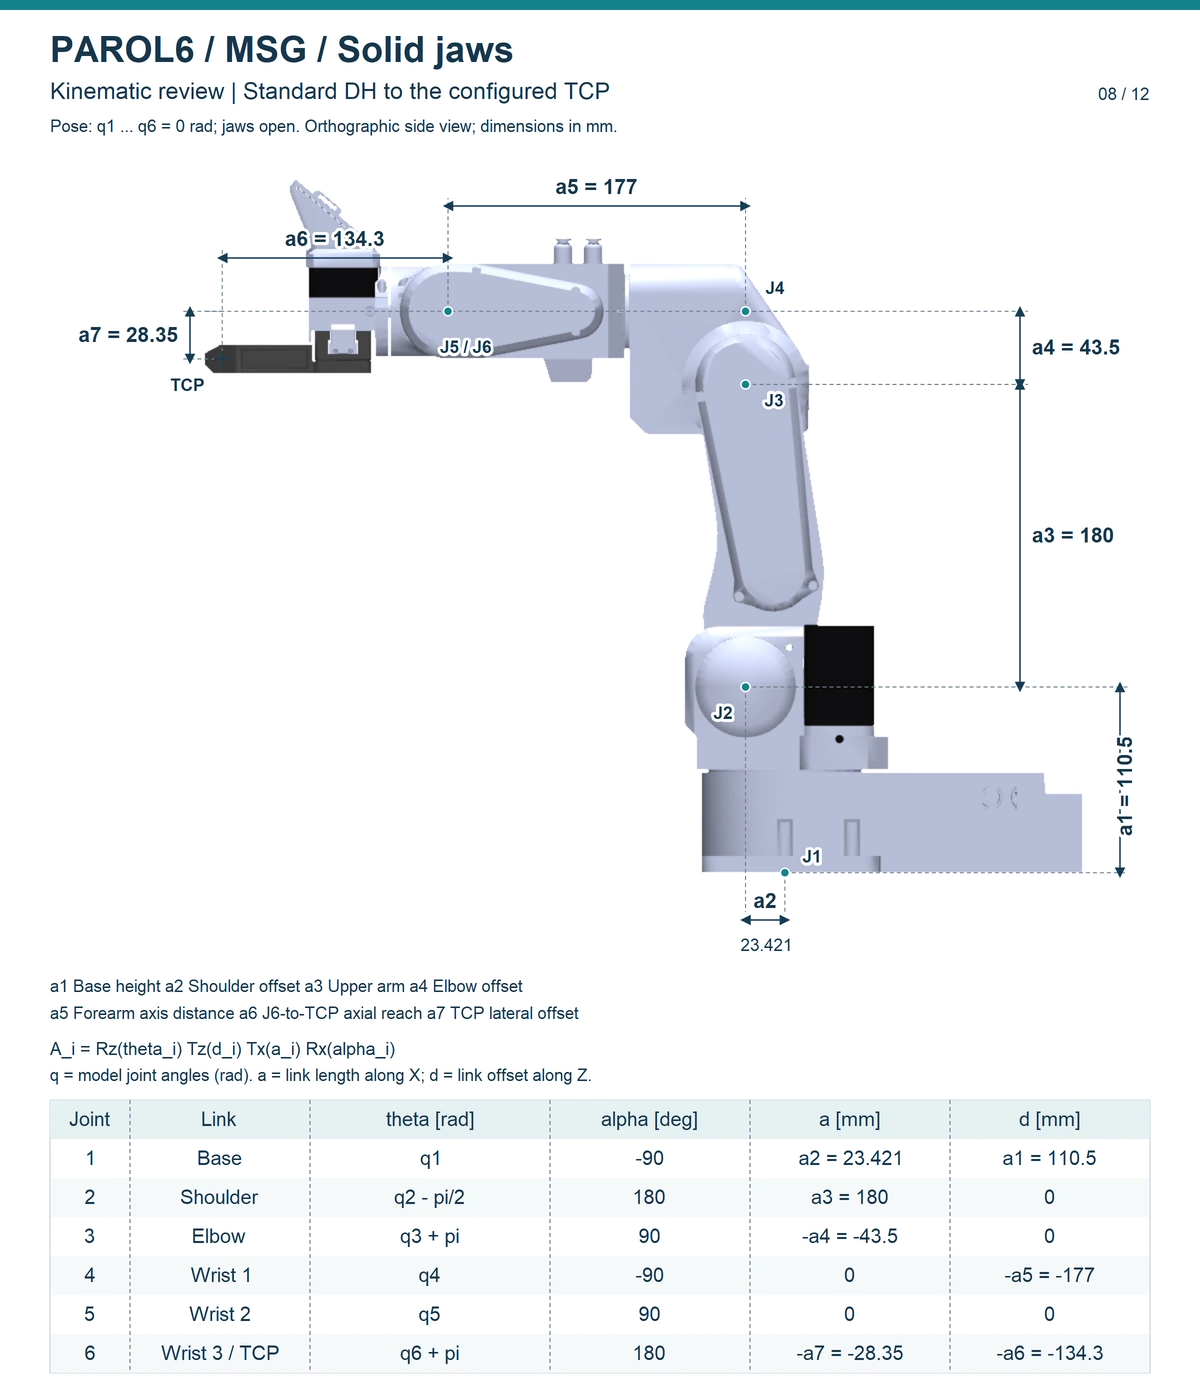
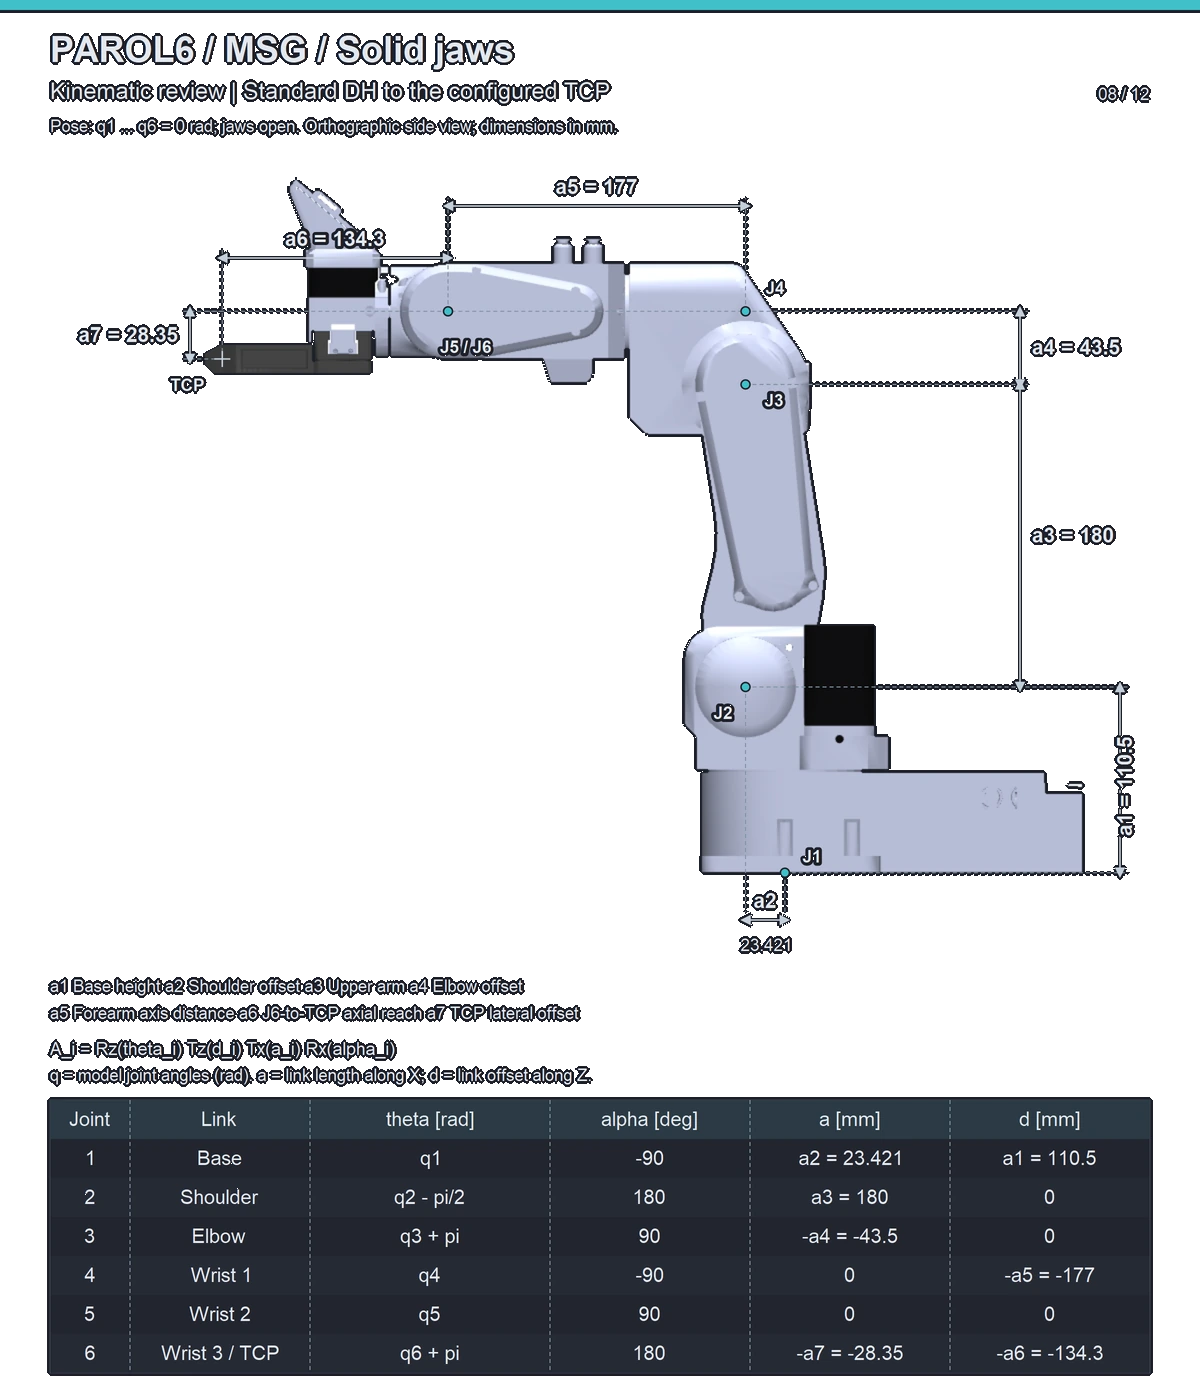
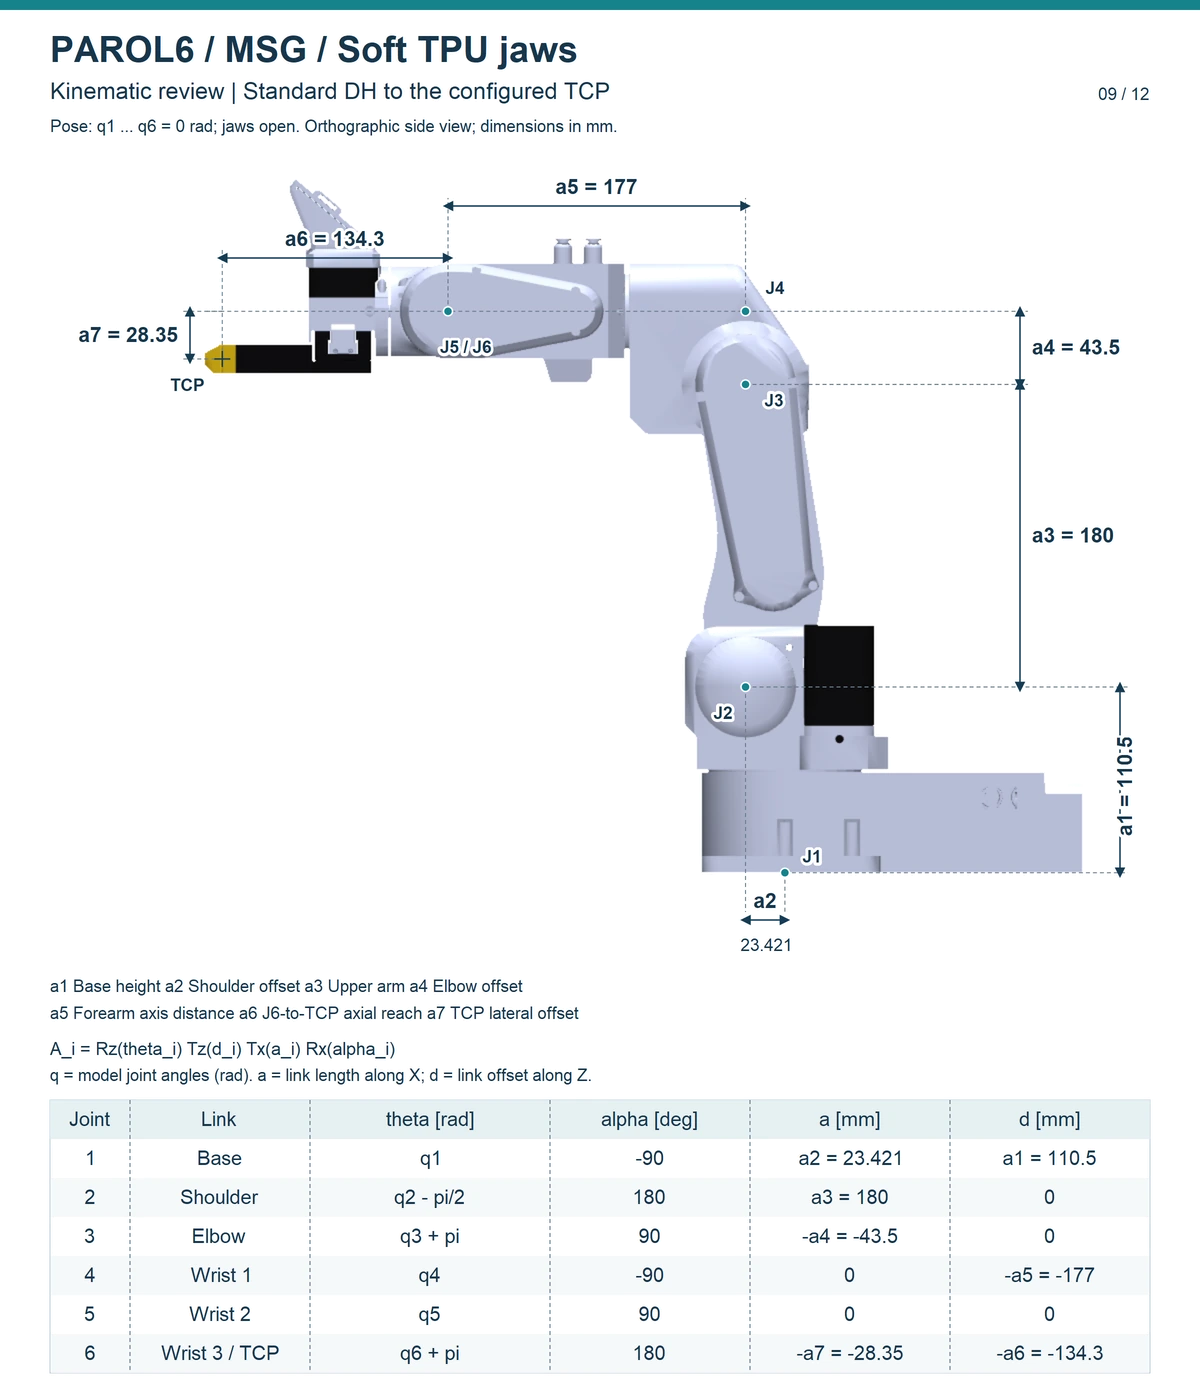
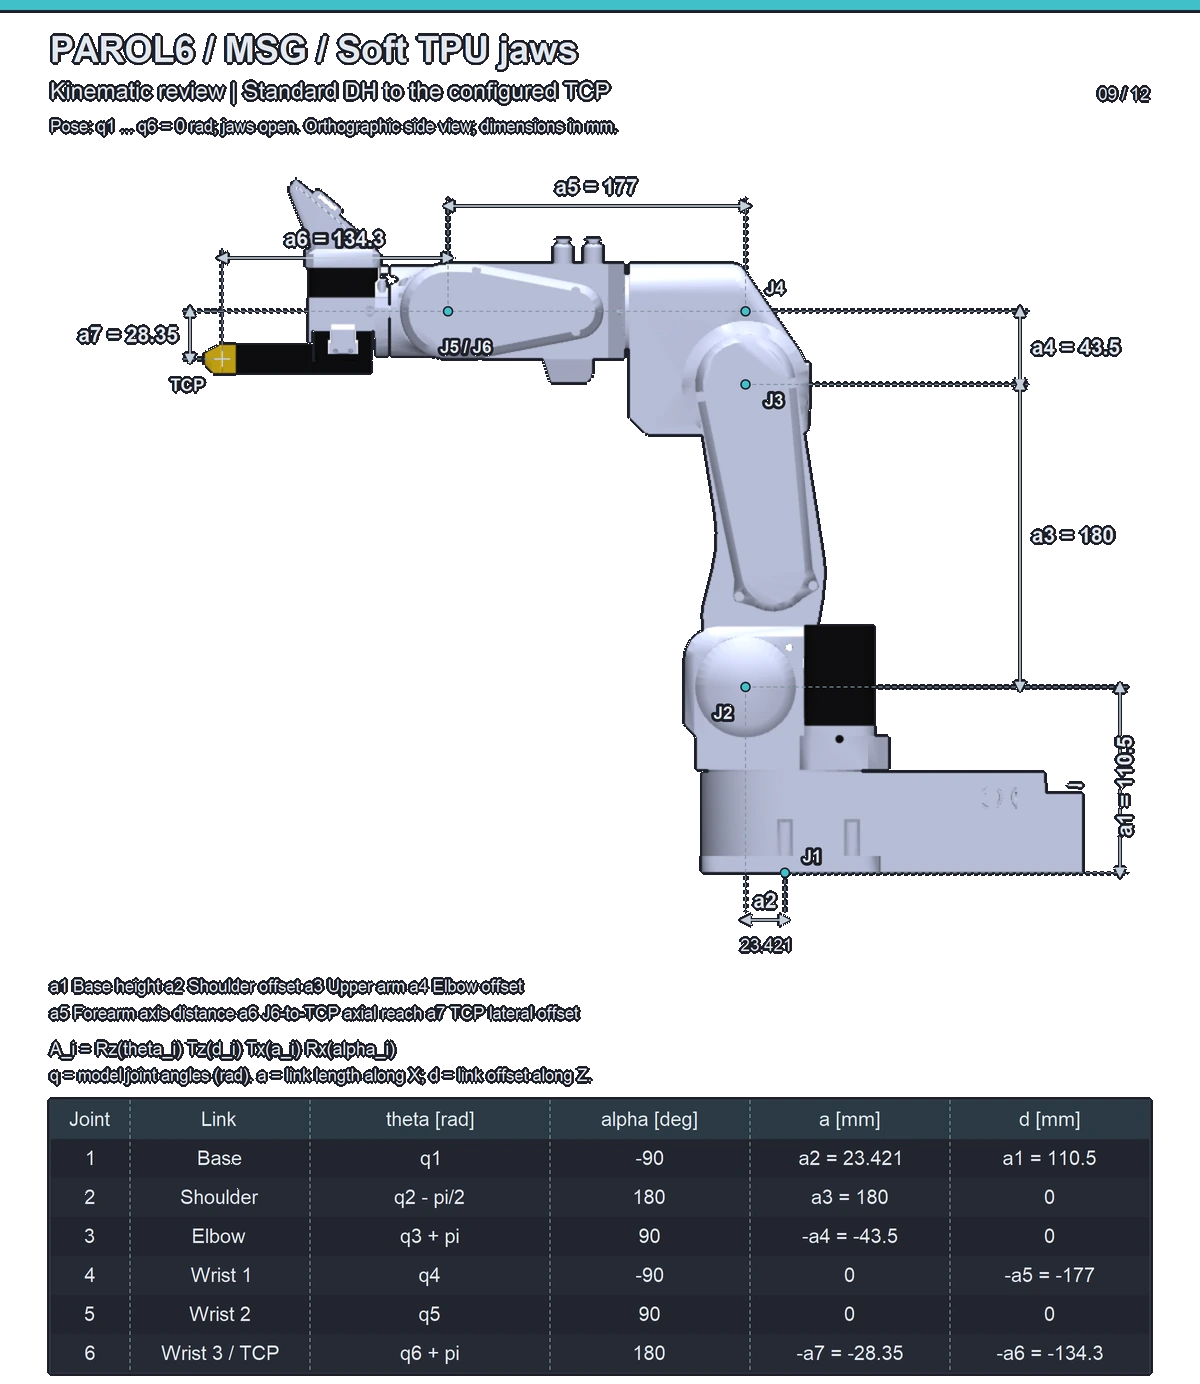
| Dimension | What it is | Value |
|---|---|---|
| a1 | Base height: the floor to the joint 2 axis | 110.5 mm |
| a2 | Shoulder offset: the joint 1 axis to the joint 2 axis | 23.42 mm |
| a3 | Upper arm: joint 2 to joint 3 | 180 mm |
| a4 | Elbow offset | 43.5 mm |
| a5 | Forearm: the joint 3 axis to the wrist centre | 177 mm |
| a6 | The joint 6 centre to the TCP, along the tool axis | depends on the tool, below |
| a7 | Sideways offset of the TCP | depends on the tool, below |
| Tool | a6 | a7 |
|---|---|---|
| Flange only (the TCP is the flange face) | 50.5 mm | 0 |
| Pneumatic gripper | 62.3 mm | 45.25 mm |
| SSG-48, solid or fin-ray jaws | 134.3 mm | 0 |
| MSG, solid or soft jaws | 134.3 mm | 28.35 mm |
A riser under the base changes a1, and a tool of your own changes a6 and a7: tell the software about the tool (Tools and the TCP), or the poses it reports will be wrong.
The software still computes with the earlier model
These pages give the model's dimensions. Until the software is updated, the Python API (its built-in URDF) and the commander software compute with a5 = 176.35 mm, and the commander with a6 = 62.8 mm for the pneumatic gripper, so a pose they report can differ from these sheets by up to about 0.65 mm.
Kinematic structure
The first three joints place the wrist centre; the axes of joints 4, 5 and 6 intersect in one point, a spherical wrist, which is what makes the inverse kinematics tractable. The Theory corner explains forward and inverse kinematics, and Configurations and singularities the eight ways the arm can reach one pose.
Denavit-Hartenberg parameters
Standard DH, each joint's transform being A_i = Rz(theta_i) Tz(d_i) Tx(a_i) Rx(alpha_i), from the base to the
TCP. q1 to q6 are the model's joint angles (the URDF's), all 0 in the standby pose; the theta column already
contains the joint offsets, so do not add them twice. Theta is the angle the software shows: joint 2's software
angle is q2 − 90°, joint 3's is q3 + 180° and joint 6's is q6 + 180°, the others are equal. The sheets above give
the same table for each tool.
| Joint | Link | theta | alpha | a | d |
|---|---|---|---|---|---|
| 1 | Base | q1 | -90° | a2 = 23.42 mm | a1 = 110.5 mm |
| 2 | Shoulder | q2 - 90° | 180° | a3 = 180 mm | 0 |
| 3 | Elbow | q3 + 180° | 90° | -a4 = -43.5 mm | 0 |
| 4 | Wrist 1 | q4 | -90° | 0 | -a5 = -177 mm |
| 5 | Wrist 2 | q5 | 90° | 0 | 0 |
| 6 | Wrist 3, to the TCP | q6 + 180° | 180° | -a7 | -a6 |
The models were checked at 128 poses including the joint limits: the DH table, the URDF and the MuJoCo model agree to within 0.006 mm and 0.002°. The Python API does not use the table directly: it loads its URDF and computes the kinematics numerically. The commander software uses a Robotics Toolbox DH model.
Mounting holes
Six holes in the base, on a pattern made for 30×30 mm aluminium profiles. The mounting plates folder of the repository has STEP drawings of a small and a big base plate: Mounting the robot.
Comments
Found a mistake on this page? Edit it on GitHub · Report it · Get help · This page as Markdown · llms.txt · The whole manual as PDF